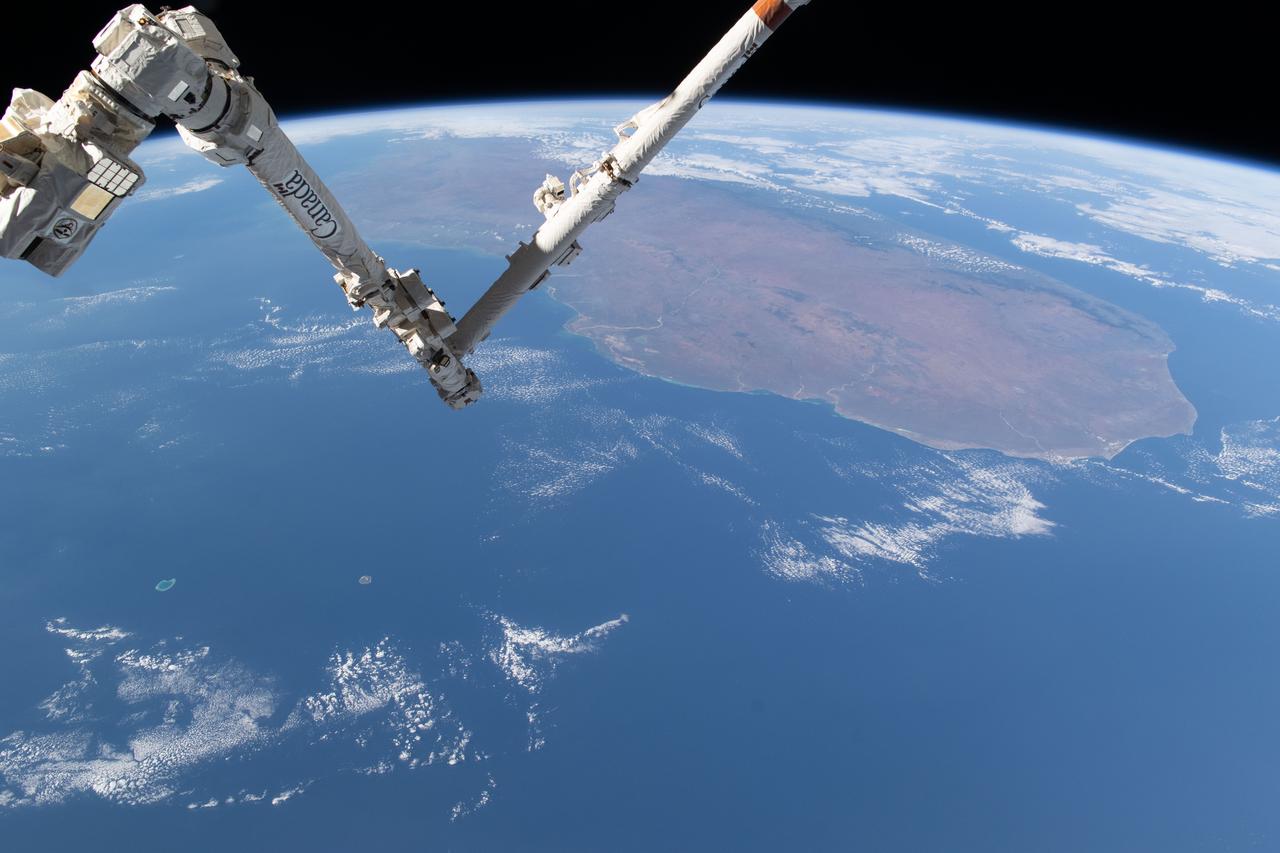
iss071e361950 (July 15, 2024) --- The International Space Station's 57.7-foot-long Canadarm2 robotic arm crosses the foreground as the orbital outpost soared 265 miles above the Mozambique Channel south of the African island nation of Madagascar.
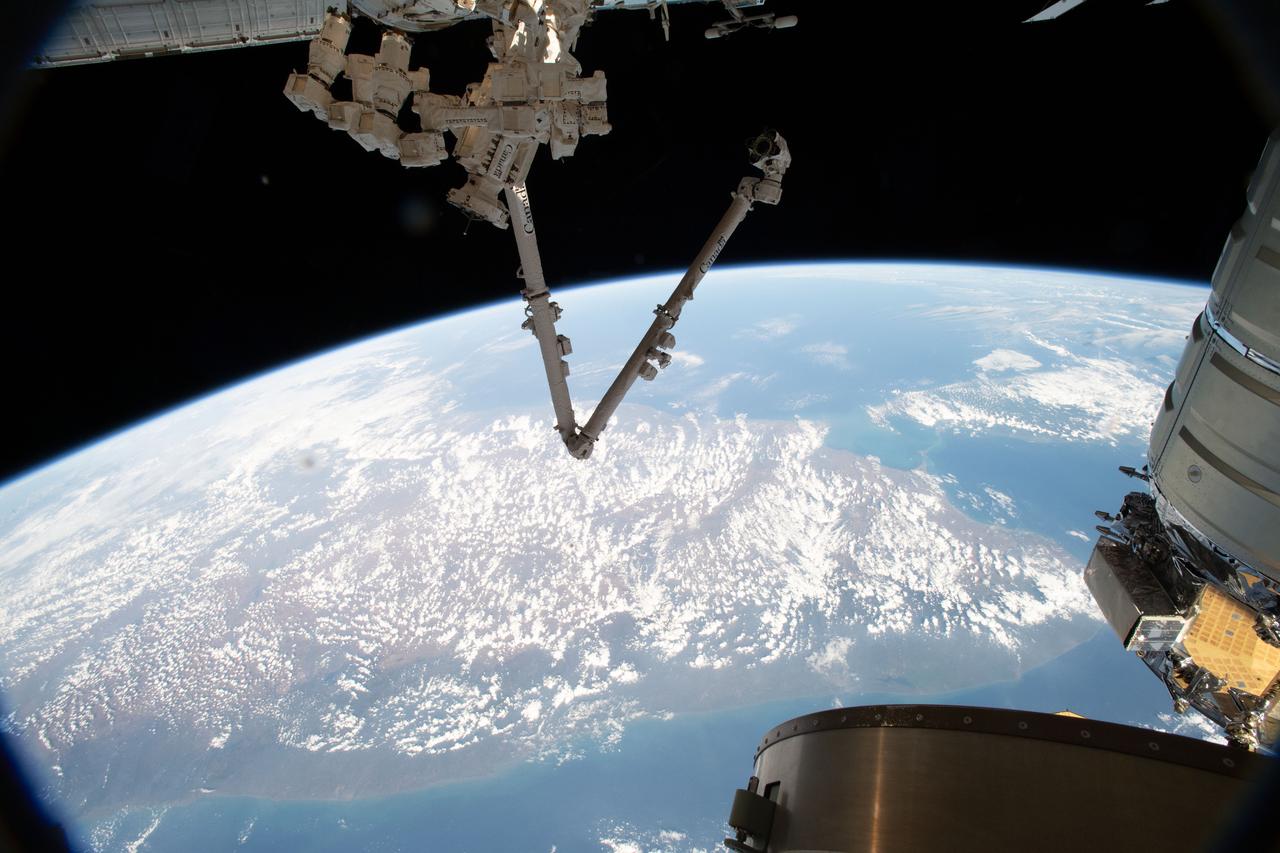
iss058e005961 (Jan. 26, 2019) --- The International Space Station's Canadarm2 robotic arm and its Dextre robotic hand are seen as the orbital complex flew 252 miles above the Arabian Sea off the coast of India.
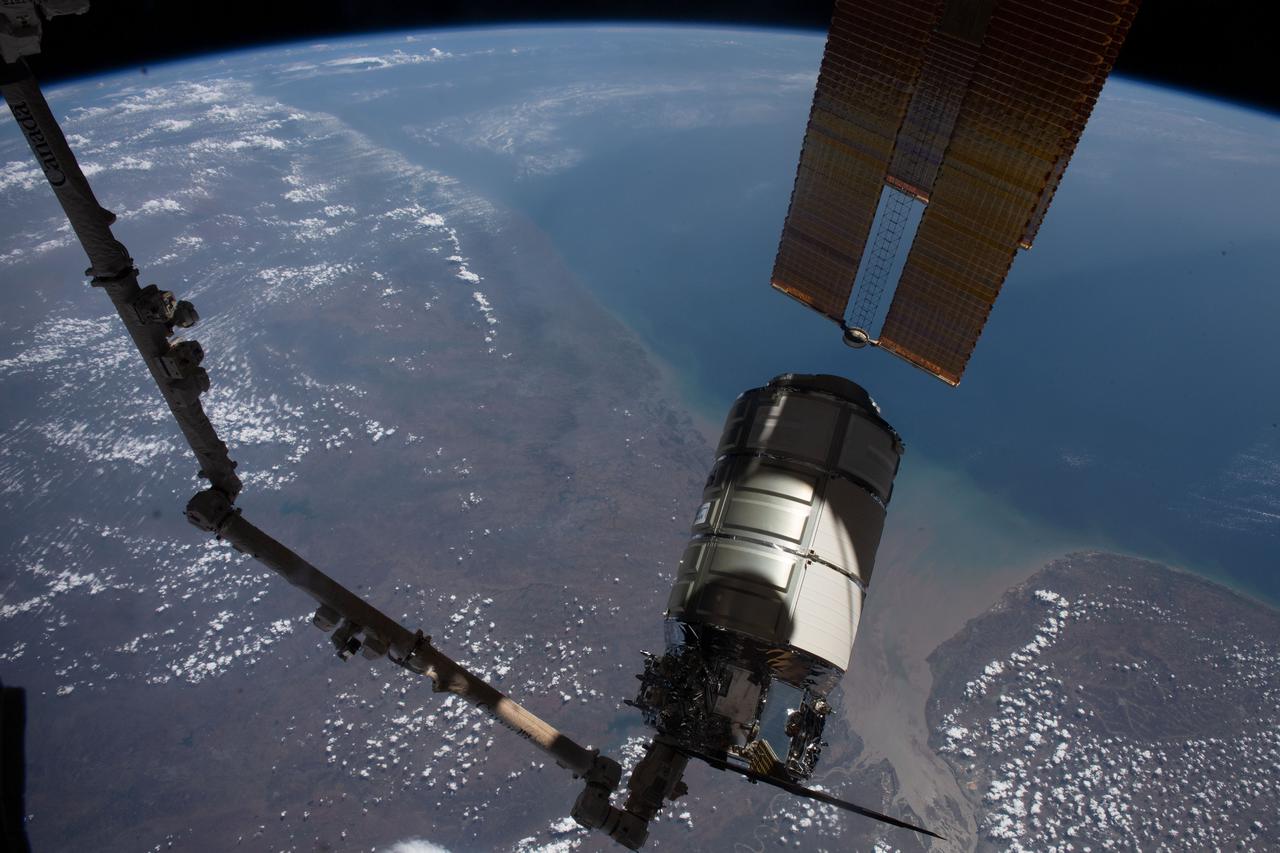
iss069e004909 (April 21, 2023) --- The Cygnus space freighter from Northrop Grumman is pictured in the grips of the Canadarm2 robotic arm as the International Space Station orbited 258 miles above the Arabian Sea coast of India.

iss069e004825 (April 21, 2023) --- The Cygnus space freighter from Northrop Grumman is poised for release from the Canadarm2 robotic arm as the International Space Station orbited 263 miles above the Atlantic Ocean off the coast of Ireland.
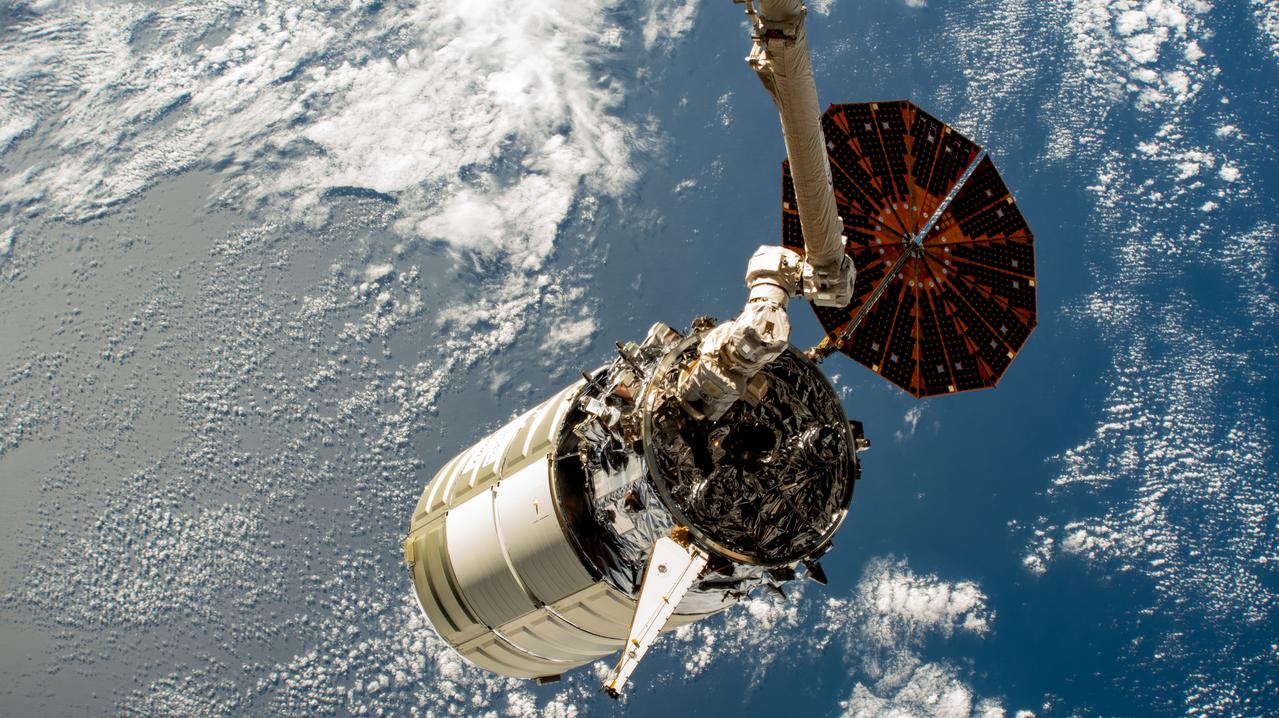
iss069e004821 (April 21, 2023) --- The Cygnus space freighter from Northrop Grumman is poised for release from the Canadarm2 robotic arm as the International Space Station orbited 262 miles above the north Atlantic Ocean.
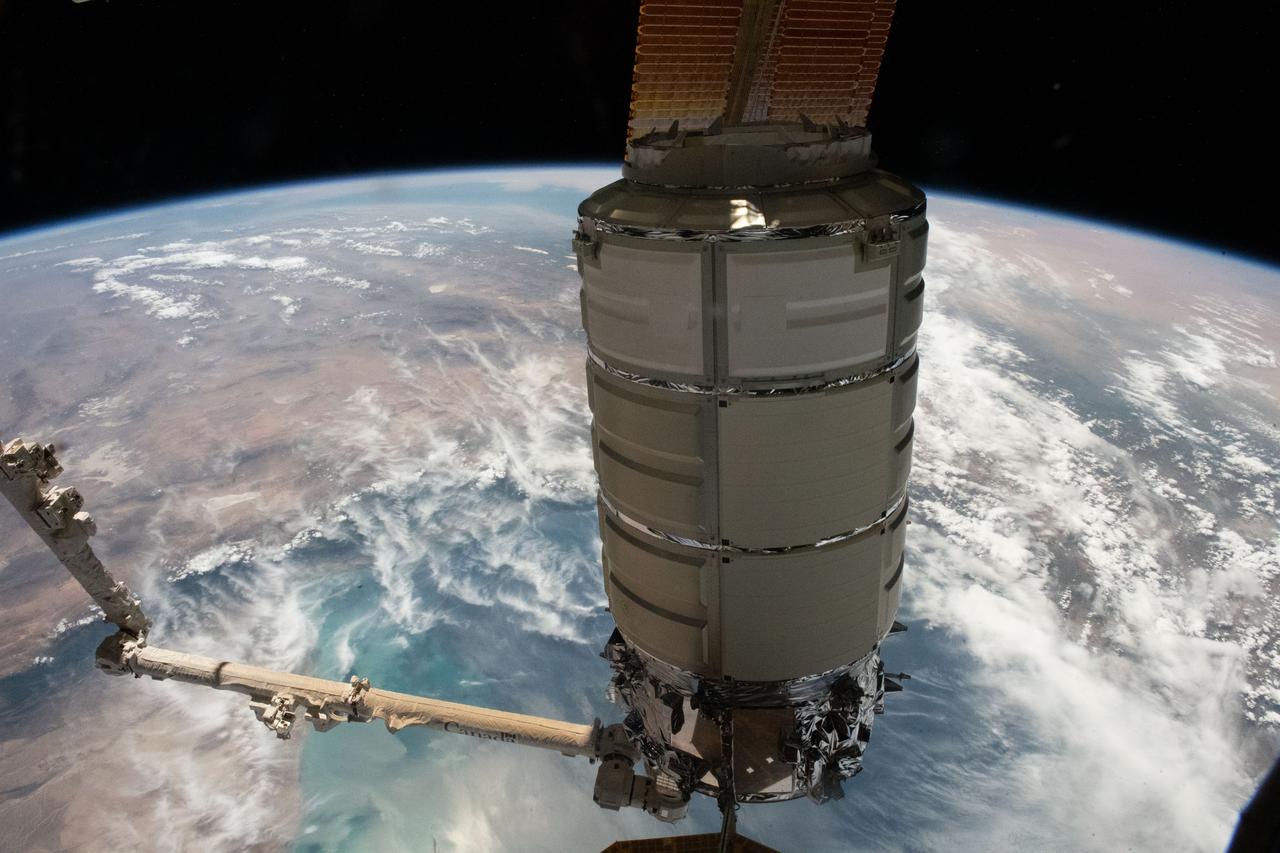
iss069e004895 (April 21, 2023) --- The Cygnus space freighter from Northrop Grumman is pictured in the grips of the Canadarm2 robotic arm as the International Space Station orbited 261 miles above the Caspian Sea off the coast of Turkmenistan.
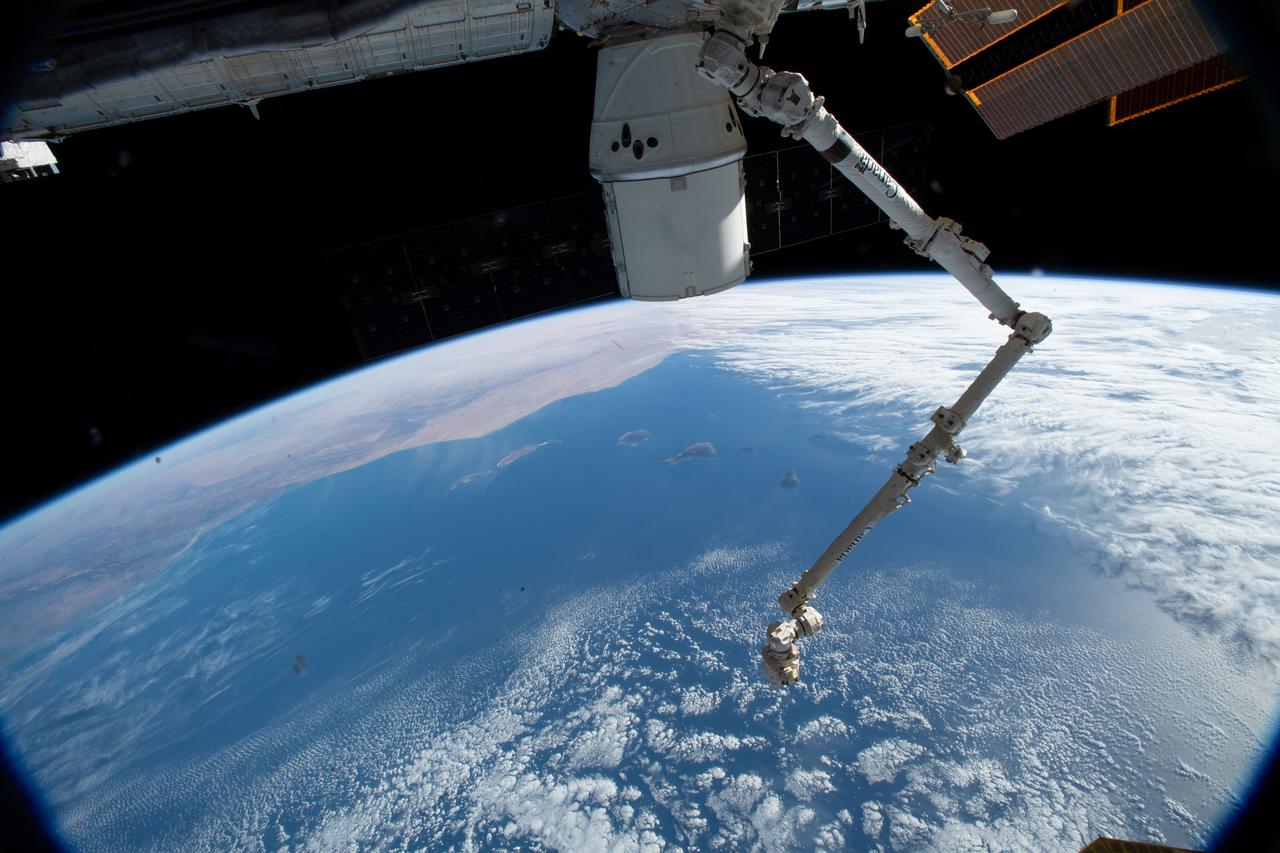
iss058e000081 (Dec. 22, 2018) --- The SpaceX Dragon cargo craft and the Canadarm2 robotic arm are pictured attached to the International Space Station as the orbital complex was 251 miles above the Atlantic Ocean about to fly over Morocco.
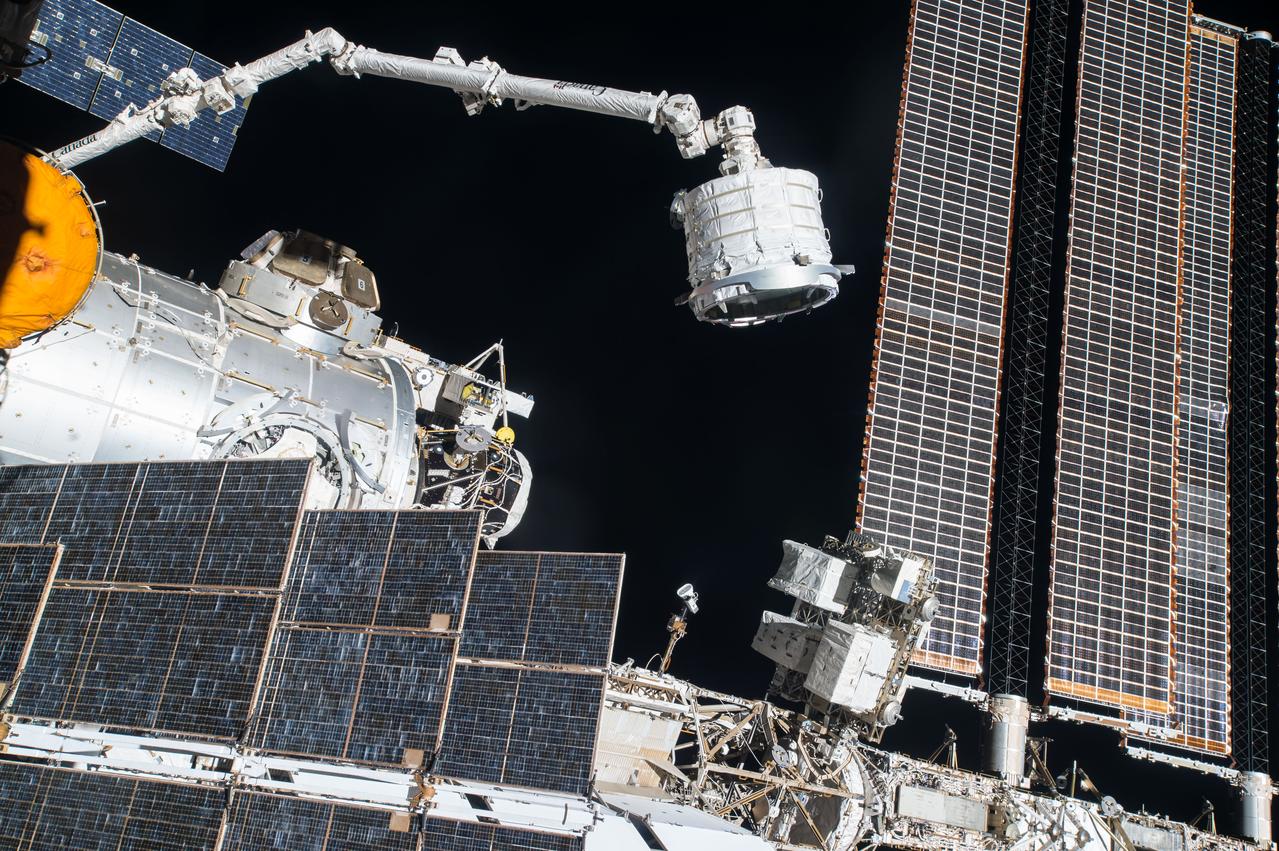
iss047e061107 (4/16/2016) --- View of Bigelow Expandable Activity Module (BEAM) attached to Canadarm2 Robotic Arm. The Bigelow Expandable Activity Module (BEAM) is an experimental expandable capsule that docks with the International Space Station (ISS). After docking, BEAM inflates to roughly 13 feet long and 10.5 feet in diameter to provide a habitable volume where a crew member can enter.
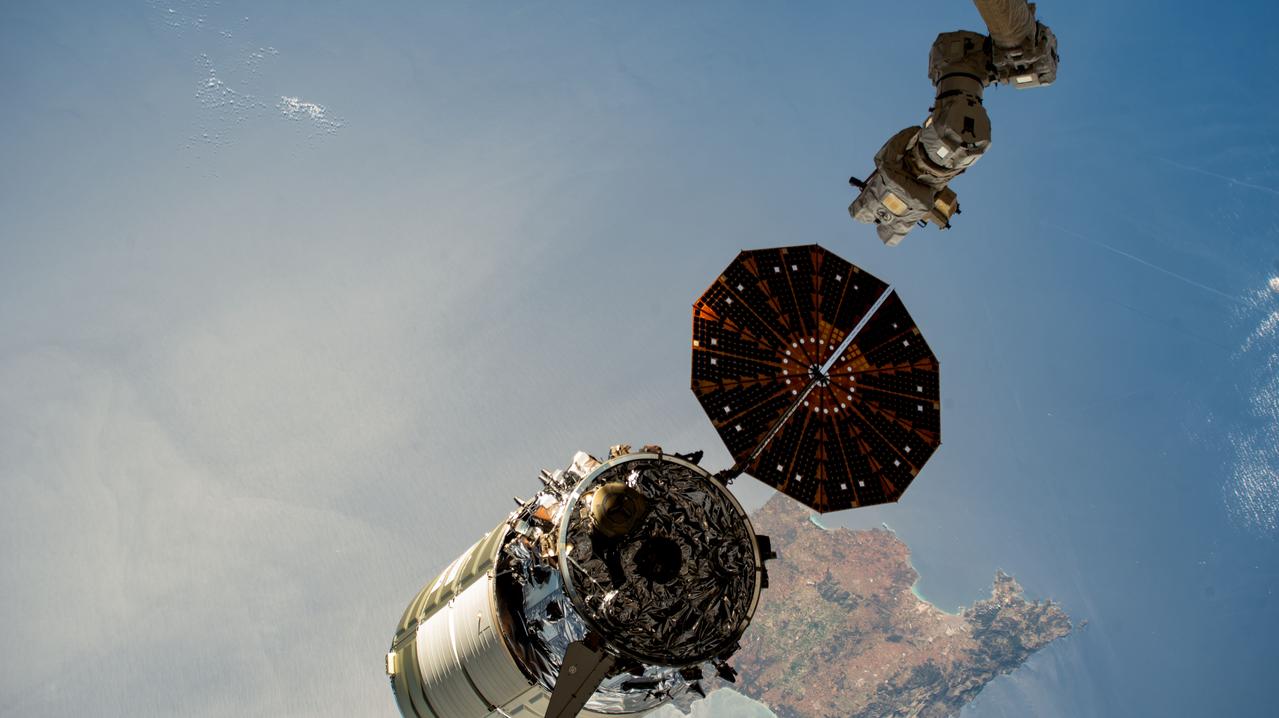
iss069e004822 (April 21, 2023) --- The Cygnus space freighter from Northrop Grumman is pictured moments after its release from the Canadarm2 robotic arm as the International Space Station orbited 262 miles above the Mediterranean Sea near the Spanish island of Mallorca.
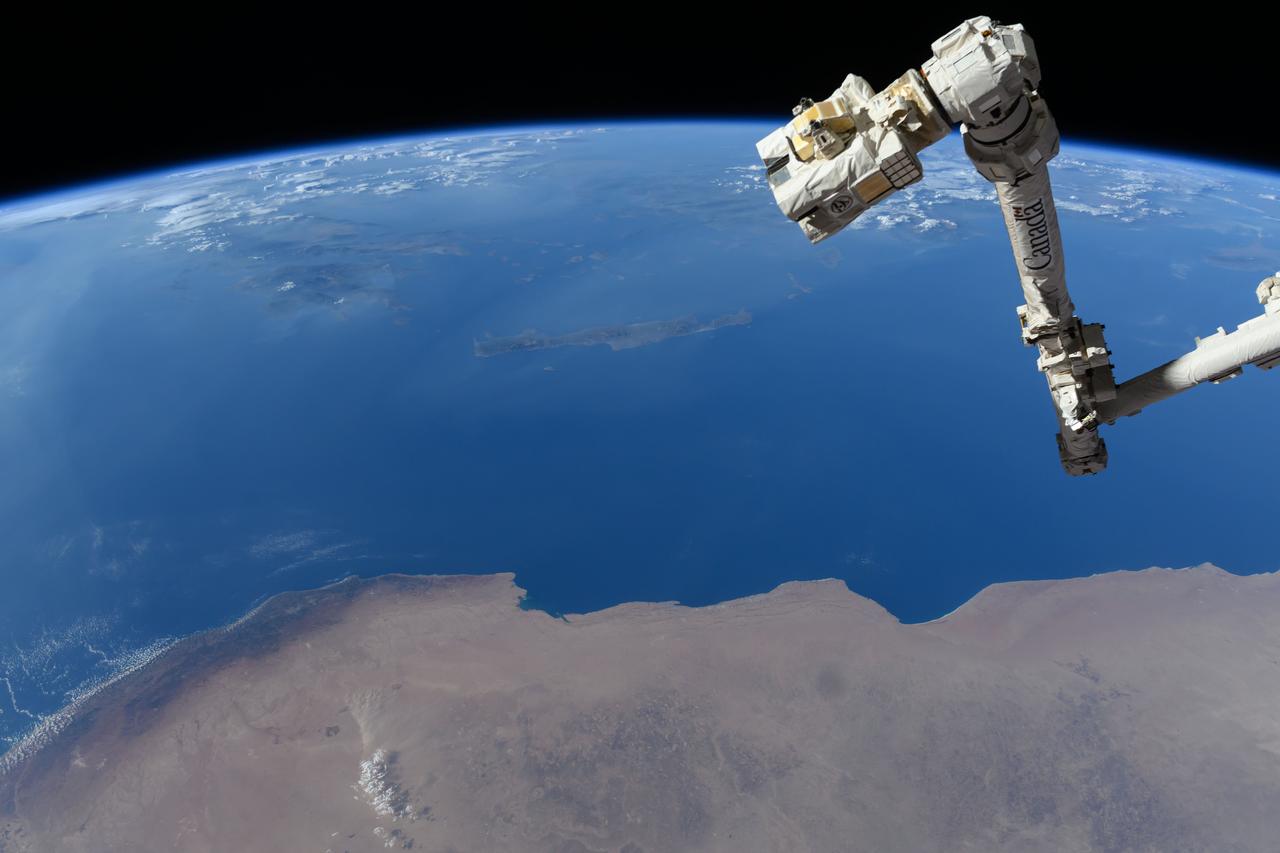
iss071e384199 (July 17, 2024) --- The Canadarm2 robotic arm's latching end effector, or LEE, is used to grapple fixtures on the International Space Station, as well as capture the approaching Cygnus cargo craft from Northrop Grumman and attach it to the Unity module for cargo transfer operations. 256 miles below the outpost is the Mediterranean coast of Libya and Egypt and the Greek island of Crete.
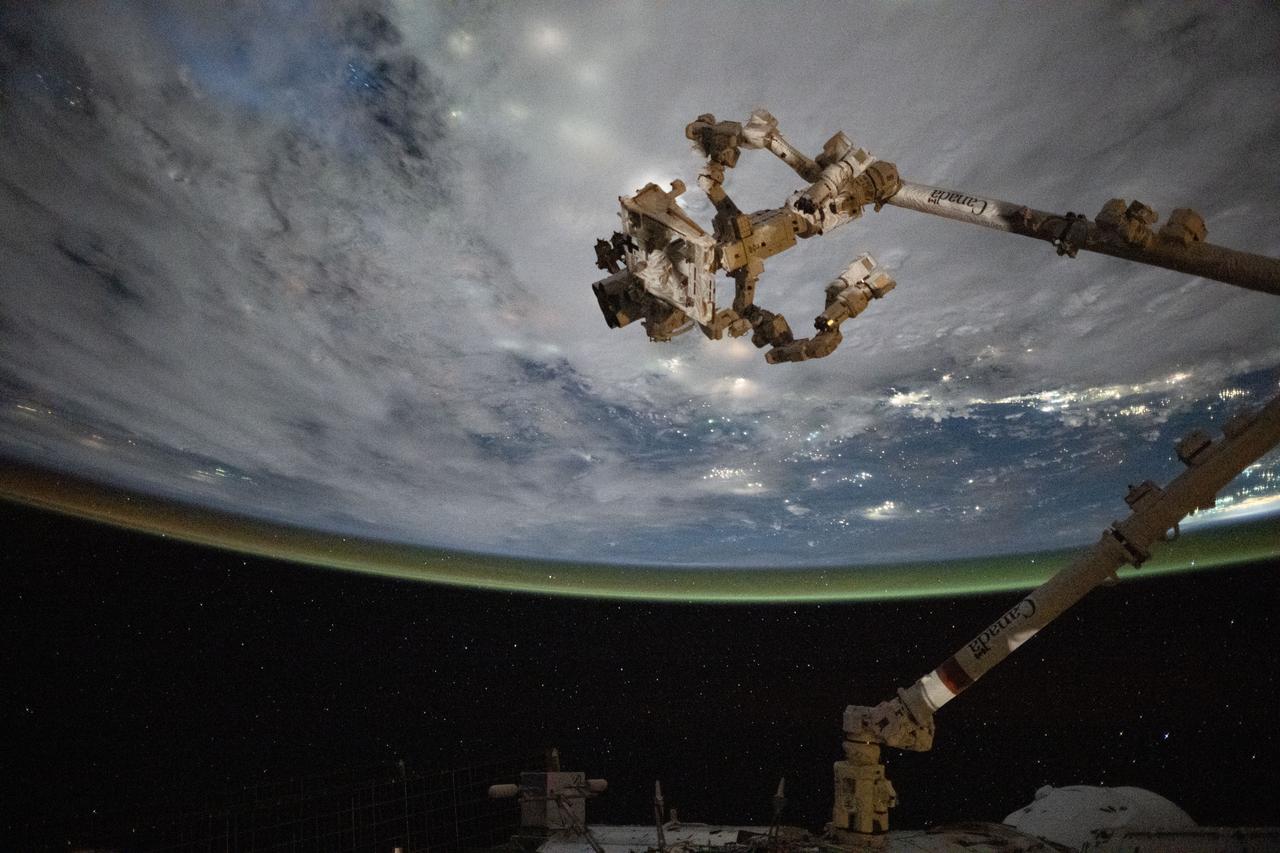
iss073e0695937 (Sept. 1, 2025) --- The Canadarm2 robotic arm with Dextre, its fine-tuned robotic hand attached, is pictured extending from the International Space Station as it orbited 258 miles above the coast of Cambodia on a cloudy Gulf of Thailand.
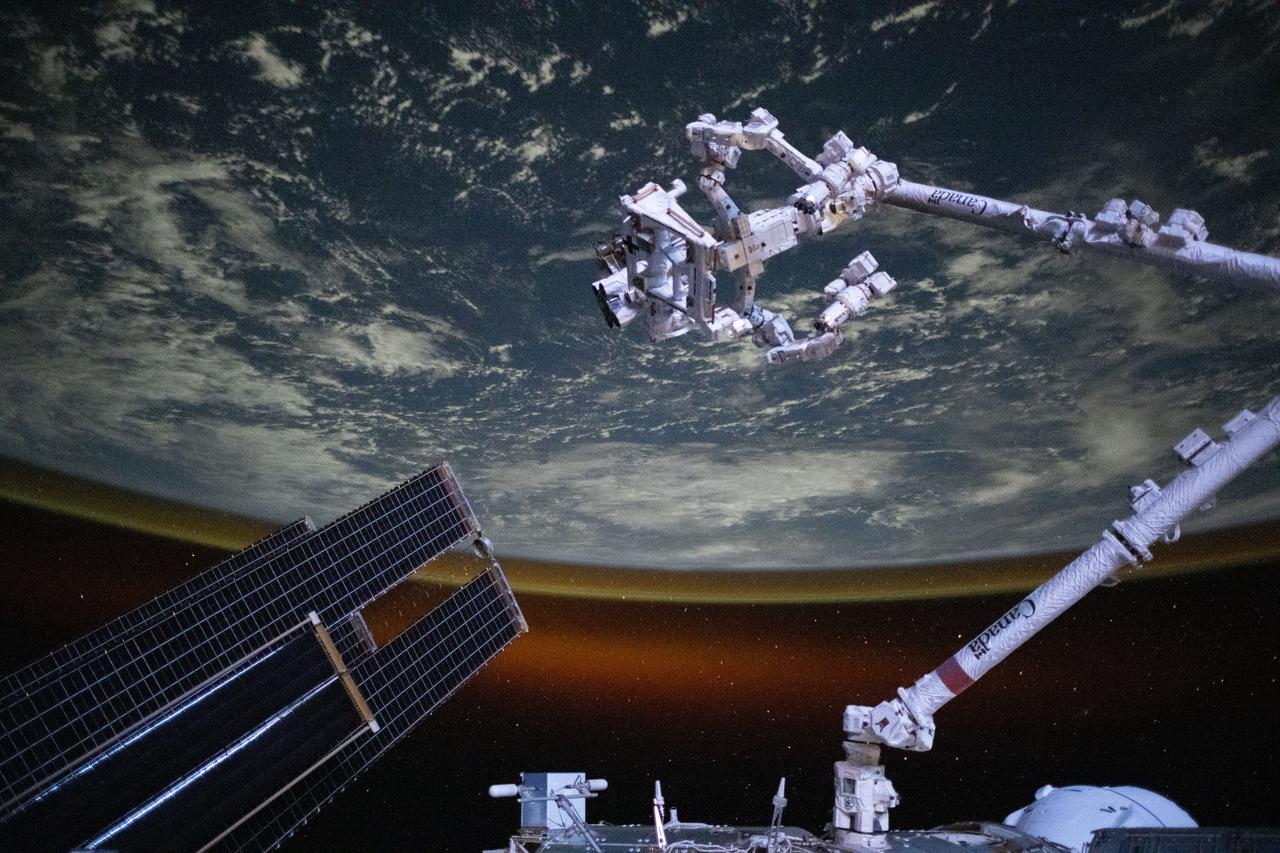
iss073e0695491 (Sept. 1, 2025) --- The Canadarm2 robotic arm with Dextre, its fine-tuned robotic hand attached, is pictured extending from the International Space Station as it orbited 258 miles above the Indian Ocean southwest of the Indonesian island of Sumatra. The Earth's horizon is highlighted by the atmospheric glow with a set of the orbital outpost's main solar arrays and a partially obscured SpaceX Dragon cargo spacecraft in the foreground.

iss072e157843 (Nov. 11, 2024) --- The Canadarm2 robotic arm with its fine-tuned robotic hand Dextre, or the Special Purpose Dexterous Manipulator, attached is pictured after maneuvering and installing scientific hardware on the International Space Station. Dextre is remotely operated by robotics controllers on the ground providing precise handling capabilities reducing the need for spacewalks giving astronauts more time to conduct science.
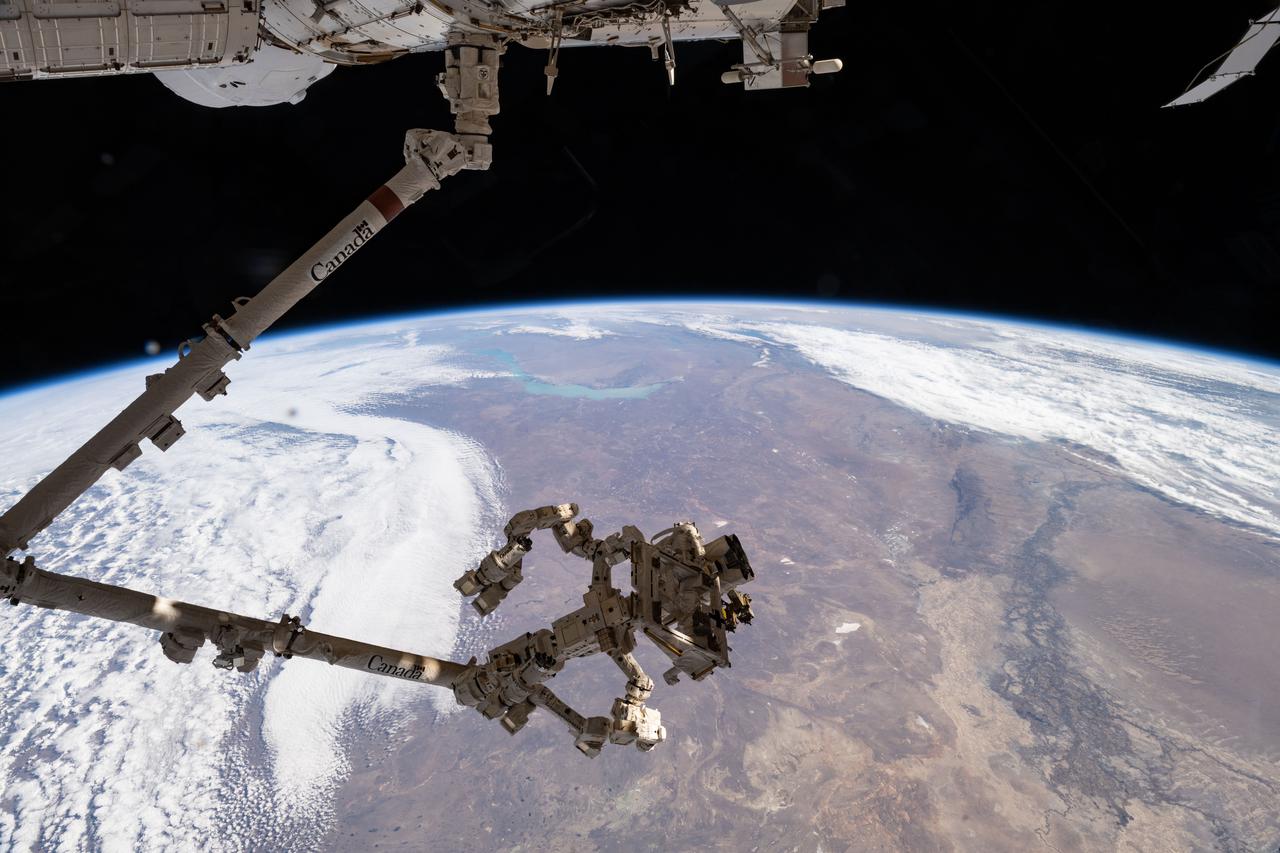
iss073e0819948 (Oct. 2, 2025) --- The Canadarm2 robotic arm, with Dextre—its fine-tuned robotic hand—attached, extends from the International Space Station’s Harmony module as the orbital outpost soars 263 miles above Kazakhstan. At upper center is Lake Balkhash, notable for its two distinct segments: the western portion contains freshwater, while the eastern portion holds saltwater due to a combination of geography, hydrology, and limited water circulation.
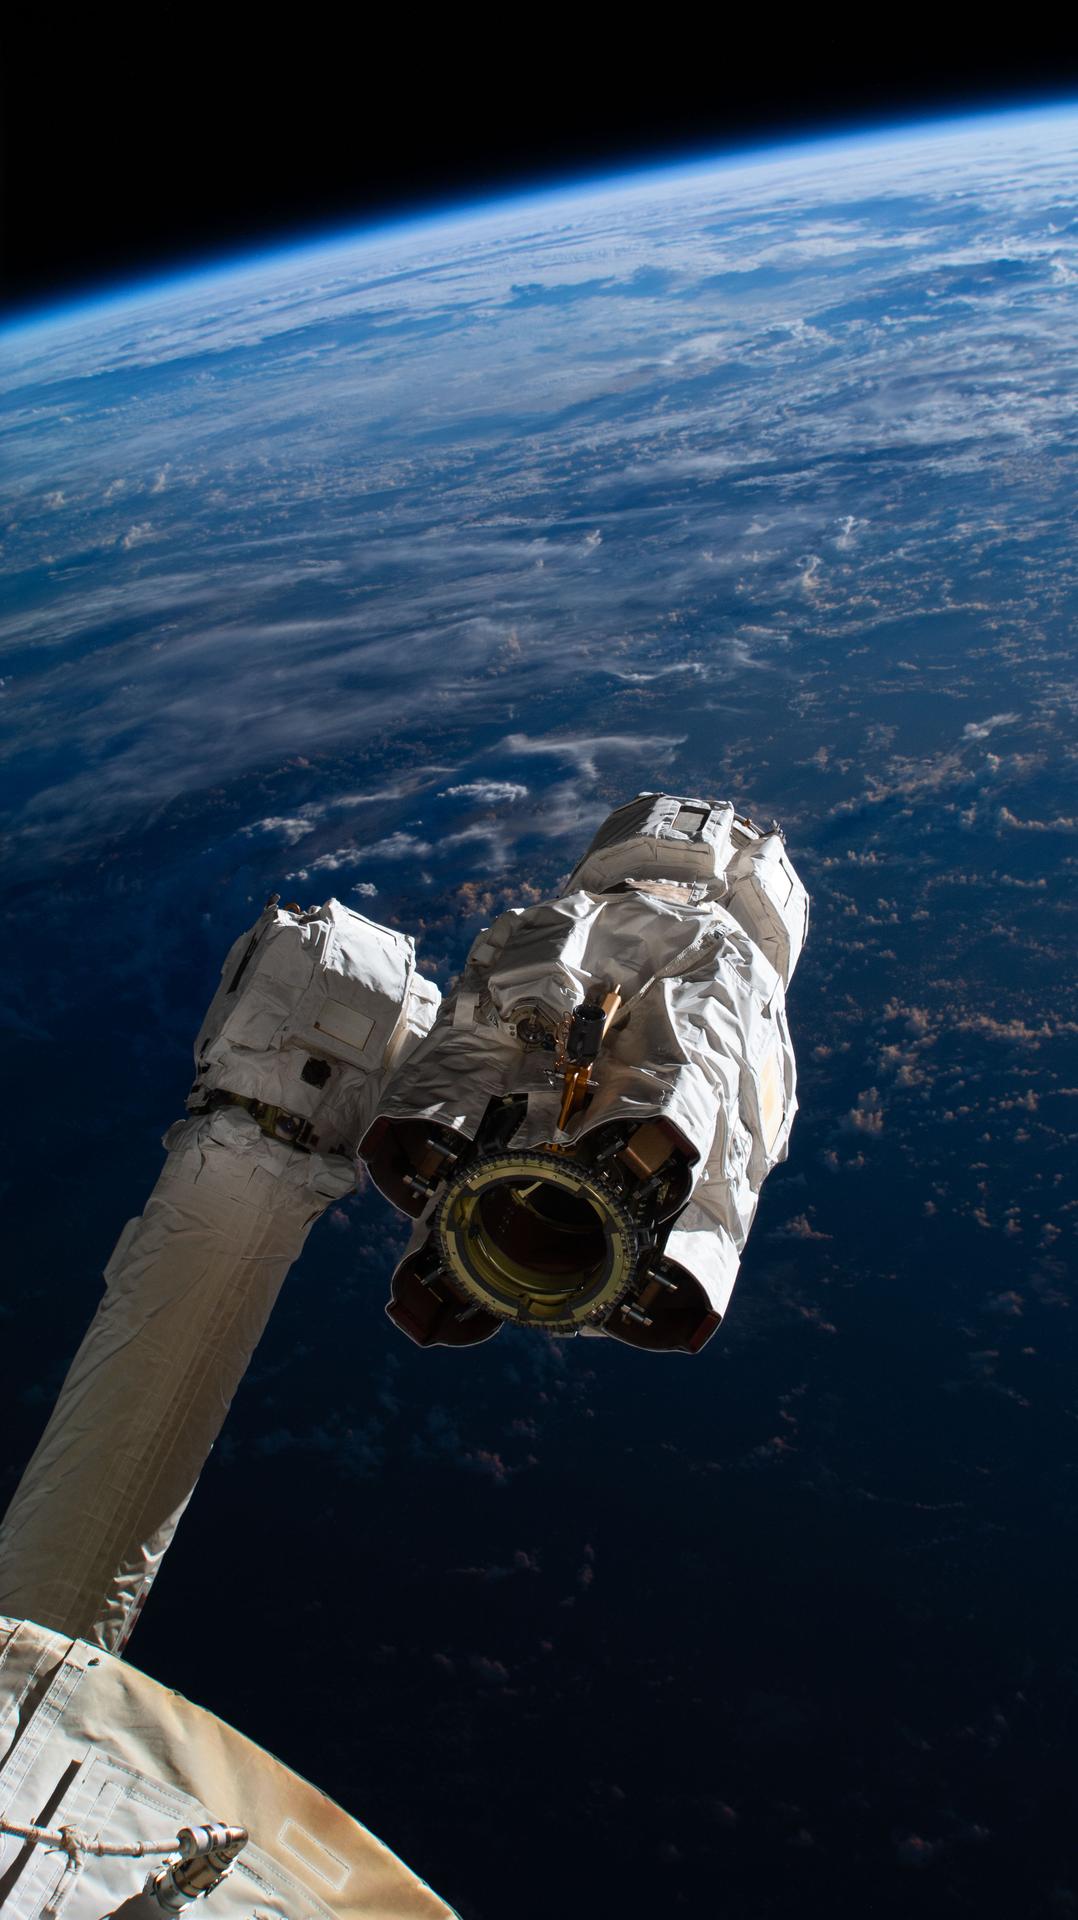
iss075e0014476 (Aug. 12, 2026) --- The Canadarm2 robotic arm’s latching end effector grapples visiting spacecraft, such as Northrop Grumman’s Cygnus XL cargo vehicle, to capture or release them from the International Space Station. It also attaches to power and data grapple fixtures on the orbital outpost for stability and maneuvers astronauts during spacewalks. Credit: NASA
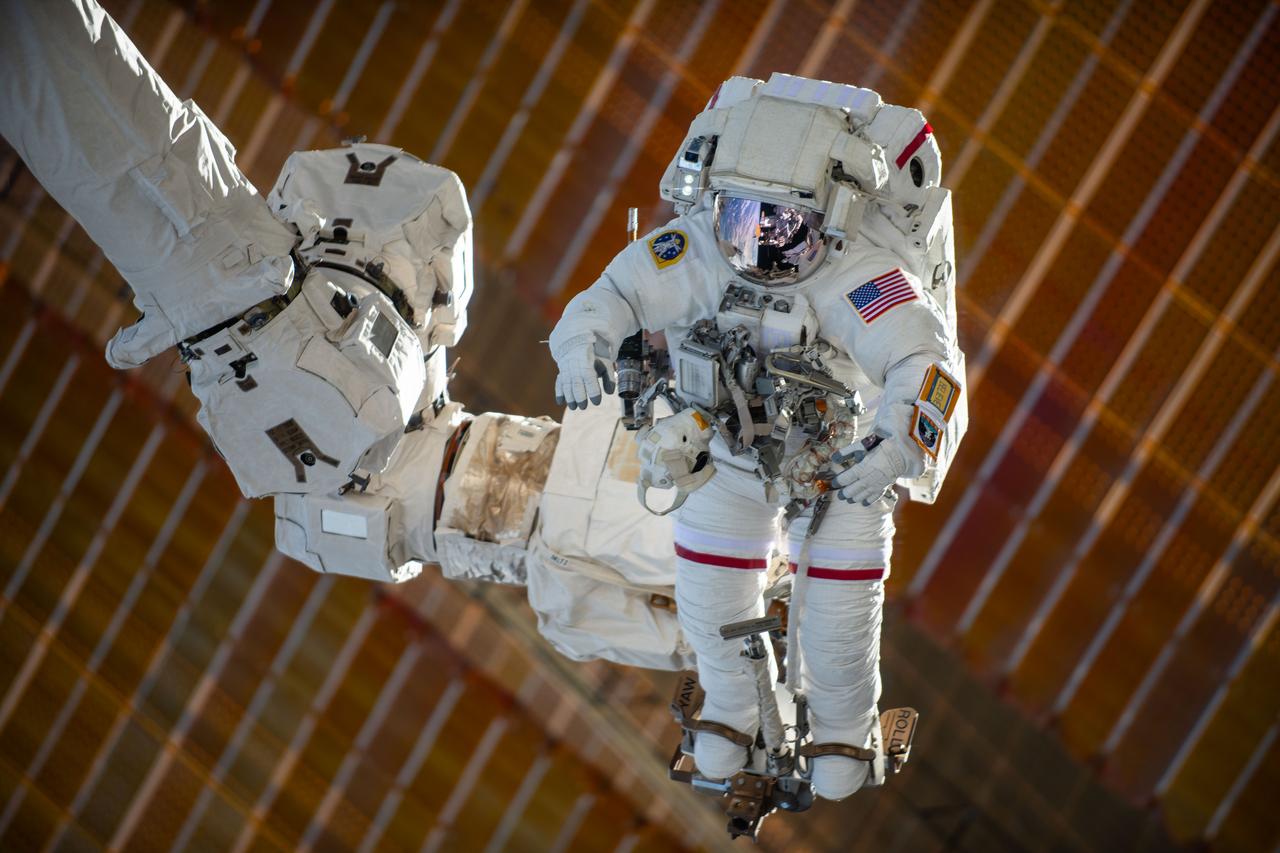
iss072e595426 (Jan. 30, 2025) --- NASA astronaut and Expedition 72 Commander Suni Williams is attached to the Canadarm2 robotic arm's latching end effector while being maneuvered to her worksite 264 miles above the South Pacific Ocean. Williams removed and stowed a radio frequency group antenna assembly during the five-hour and 26-minute spacewalk outside the International Space Station.
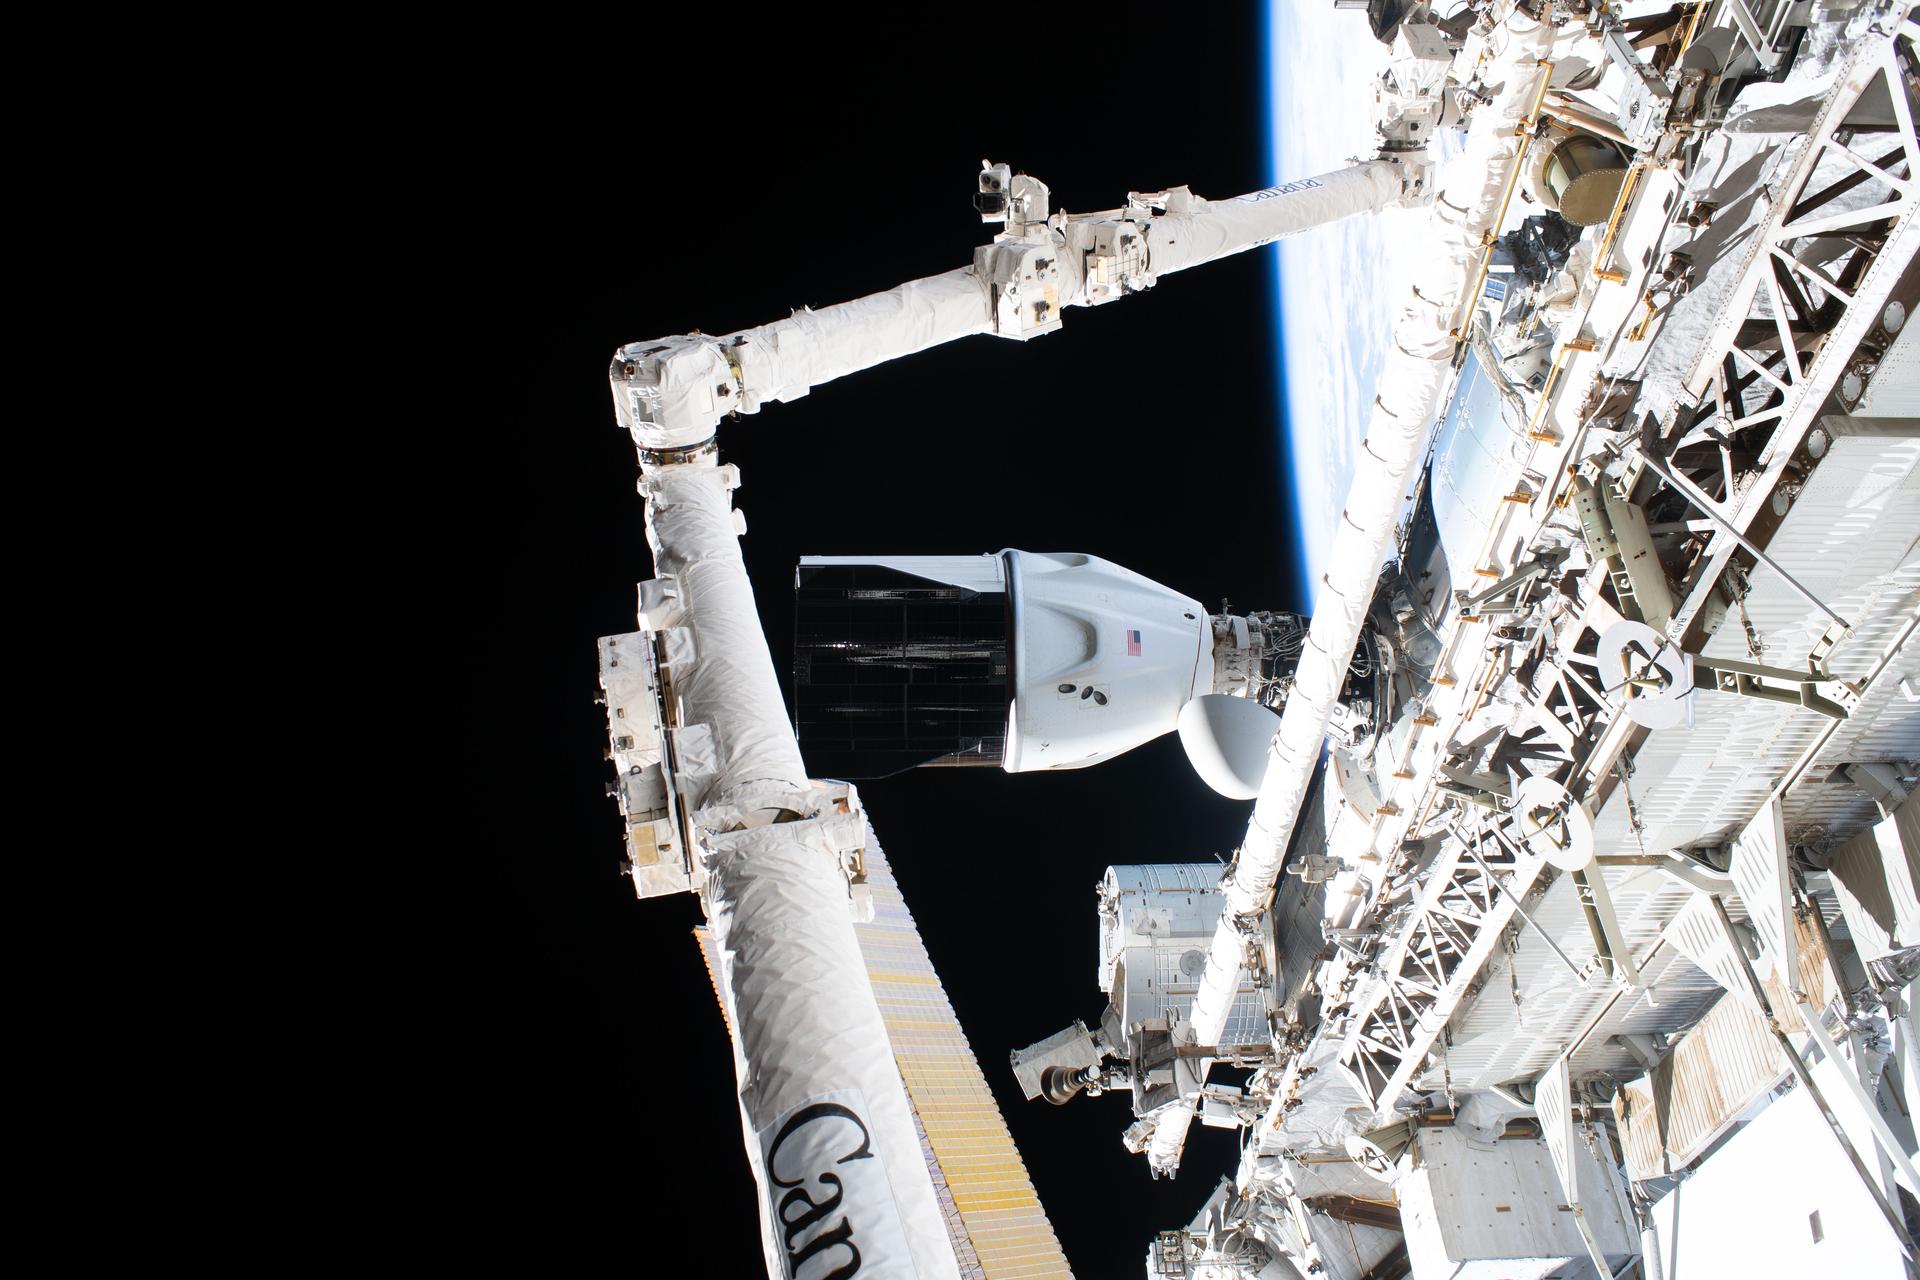
iss075e0086300 (Sept. 1, 2026) --- The SpaceX Dragon spacecraft, which launched four SpaceX Crew‑12 members to the International Space Station and will return them to Earth, is pictured docked to the orbital outpost’s space‑facing port on the Harmony module. In the foreground, the Canadarm2 robotic arm extends across the frame during a spacewalk conducted by astronauts Jessica Meir of NASA and Sophie Adenot of ESA (European Space Agency) for external maintenance. Credit: NASA/Jessica Meir

iss072e595424 (Jan. 30, 2025) --- NASA astronaut and Expedition 72 Commander Suni Williams is attached to the Canadarm2 robotic arm's latching end effector while being maneuvered to her worksite 264 miles above the South Pacific Ocean. Williams removed and stowed a radio frequency group antenna assembly during the five-hour and 26-minute spacewalk outside the International Space Station.
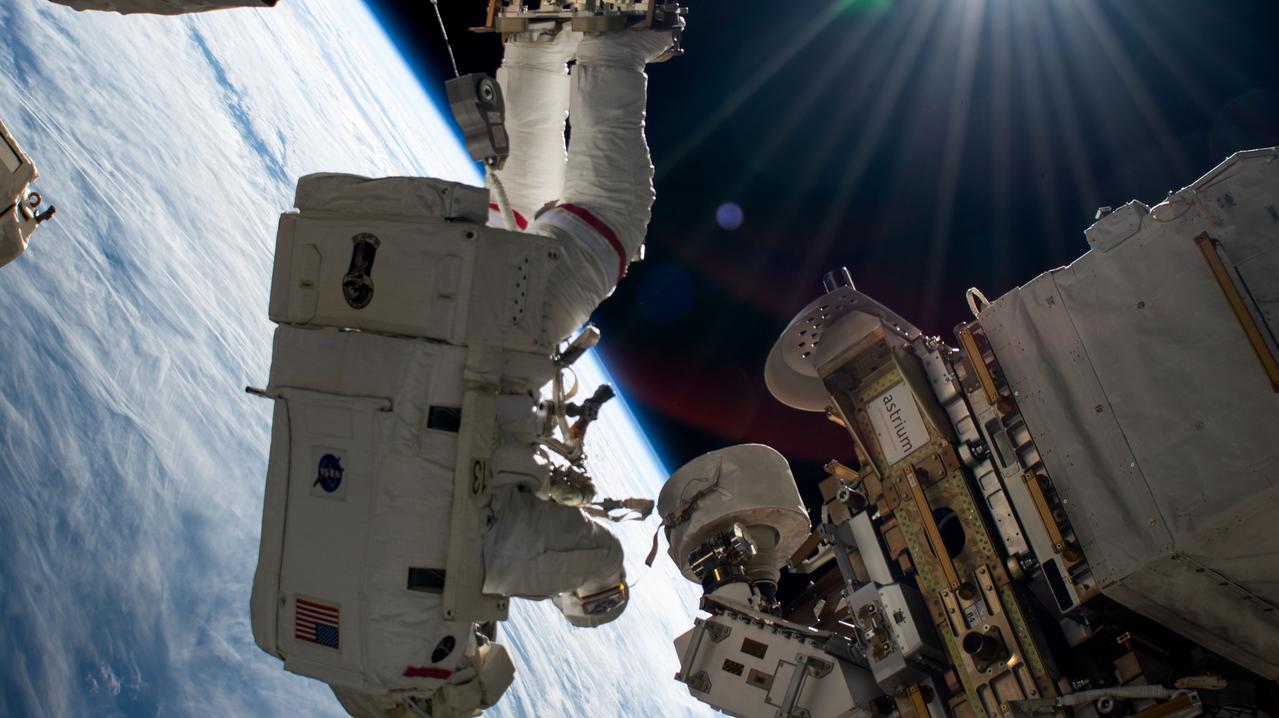
iss072e574908 (Jan. 30, 2025) --- NASA astronaut and Expedition 72 Commander Suni Williams seemingly hangs upside down while attached to the Canadarm2 robotic arm's latching end effector during a five-hour and 26 minute spacewalk to remove and stow a radio frequency group antenna assembly. The orbital outpost was soaring 260 miles above Russia near the Sea of Azov at the time of this photograph.
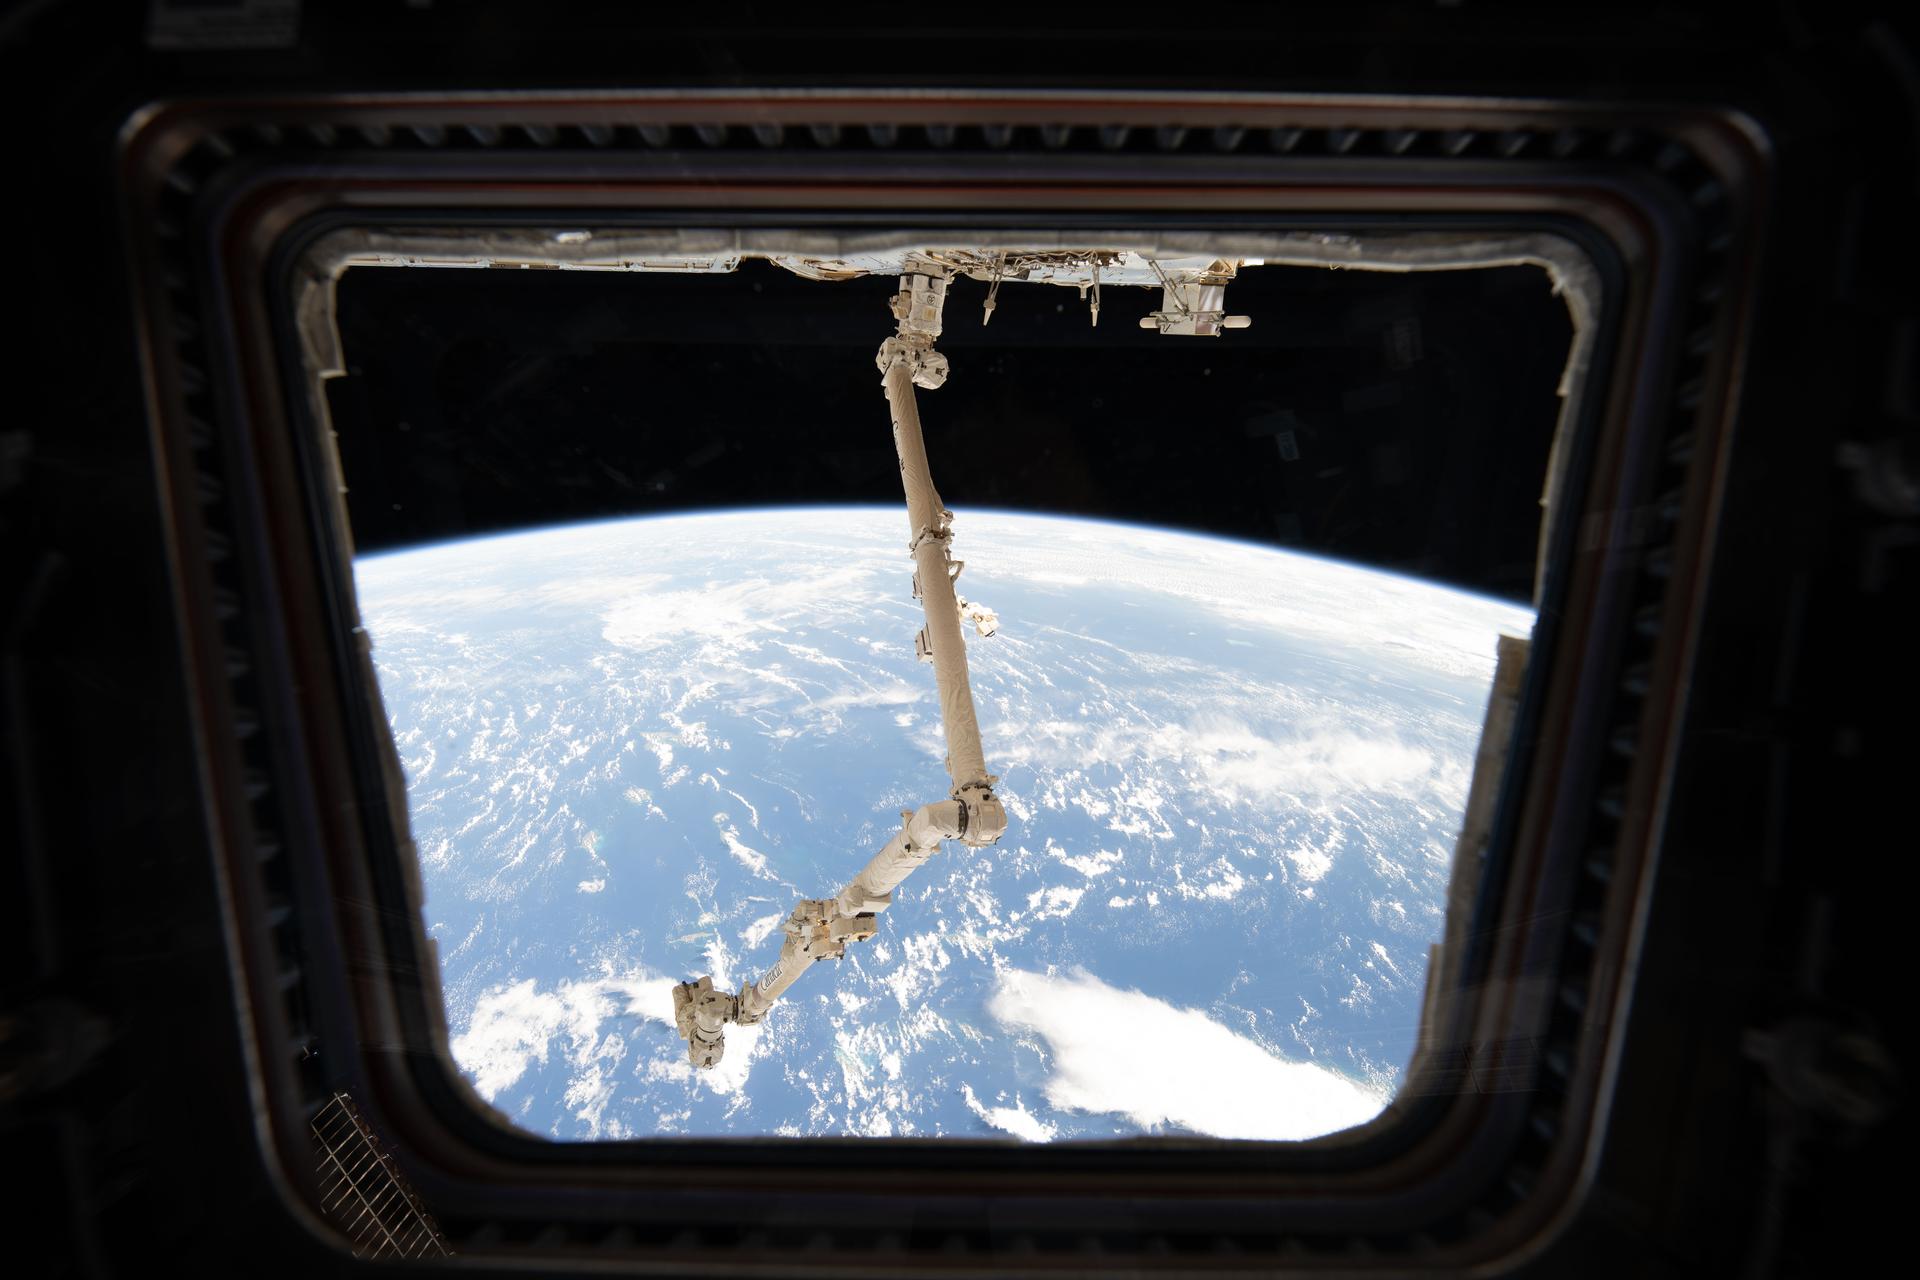
iss074e0503977 (April 12, 2026) --- This view from a window in the International Space Station’s cupola highlights the 57.7‑foot‑long Canadarm2 robotic arm attached to a power‑and‑data grapple fixture on the Harmony module. The orbital outpost was soaring 264 miles above the Atlantic Ocean northwest of Puerto Rico at the time of this photograph. Credit: NASA/Chris Williams
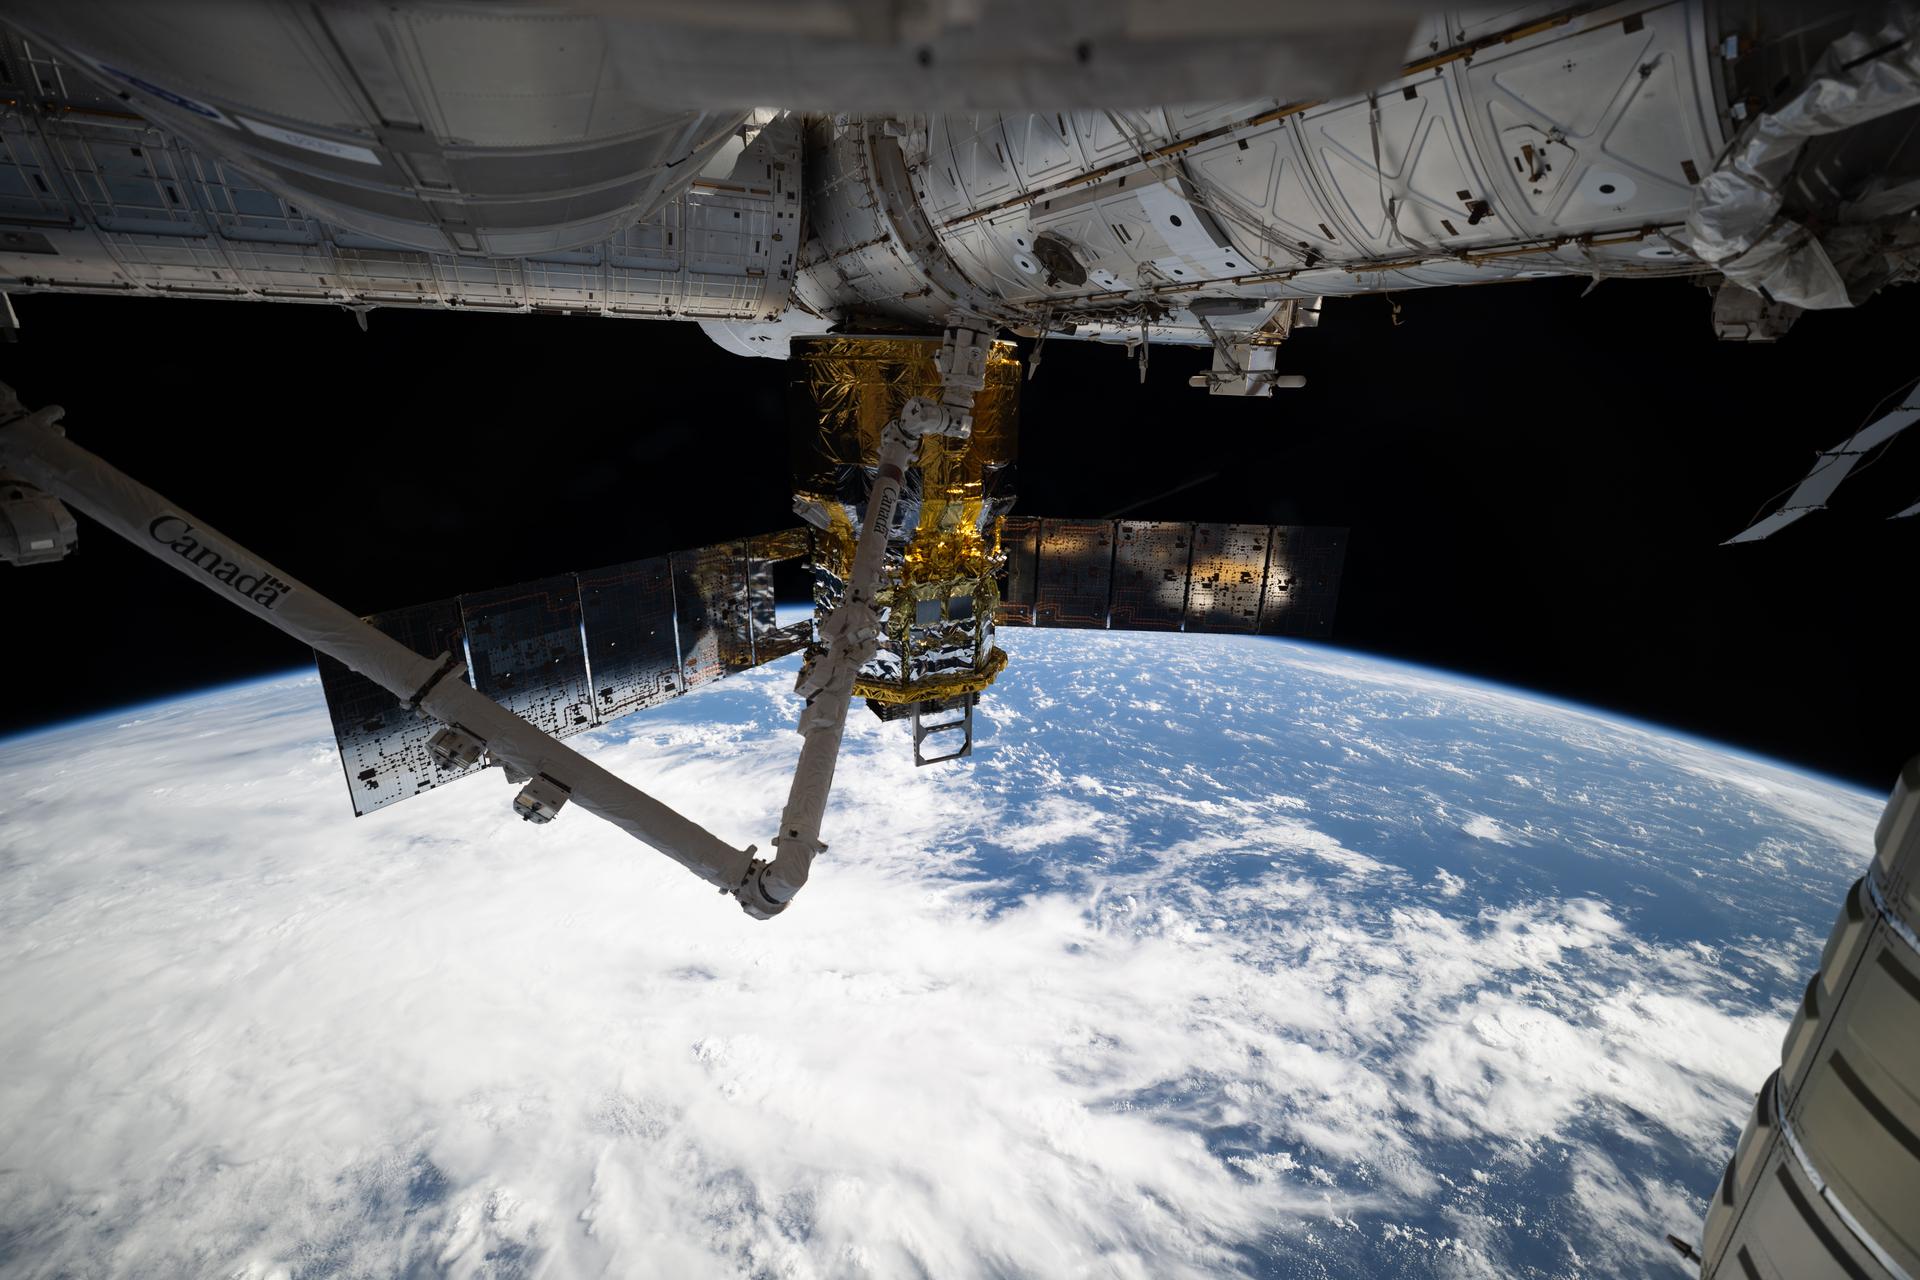
iss074e0319321 (Feb. 19, 2026) --- JAXA’s (Japan Aerospace Exploration Agency) HTV-X1 cargo craft, with the Canadarm2 robotic arm perched on a portable data grapple fixture in front, is pictured berthed to the Earth-facing port of the International Space Station’s Harmony module. At the time of this photograph, the orbital outpost was soaring 263 miles above a cloudy Indian Ocean northeast of Madagascar. Credit: NASA/Chris Williams
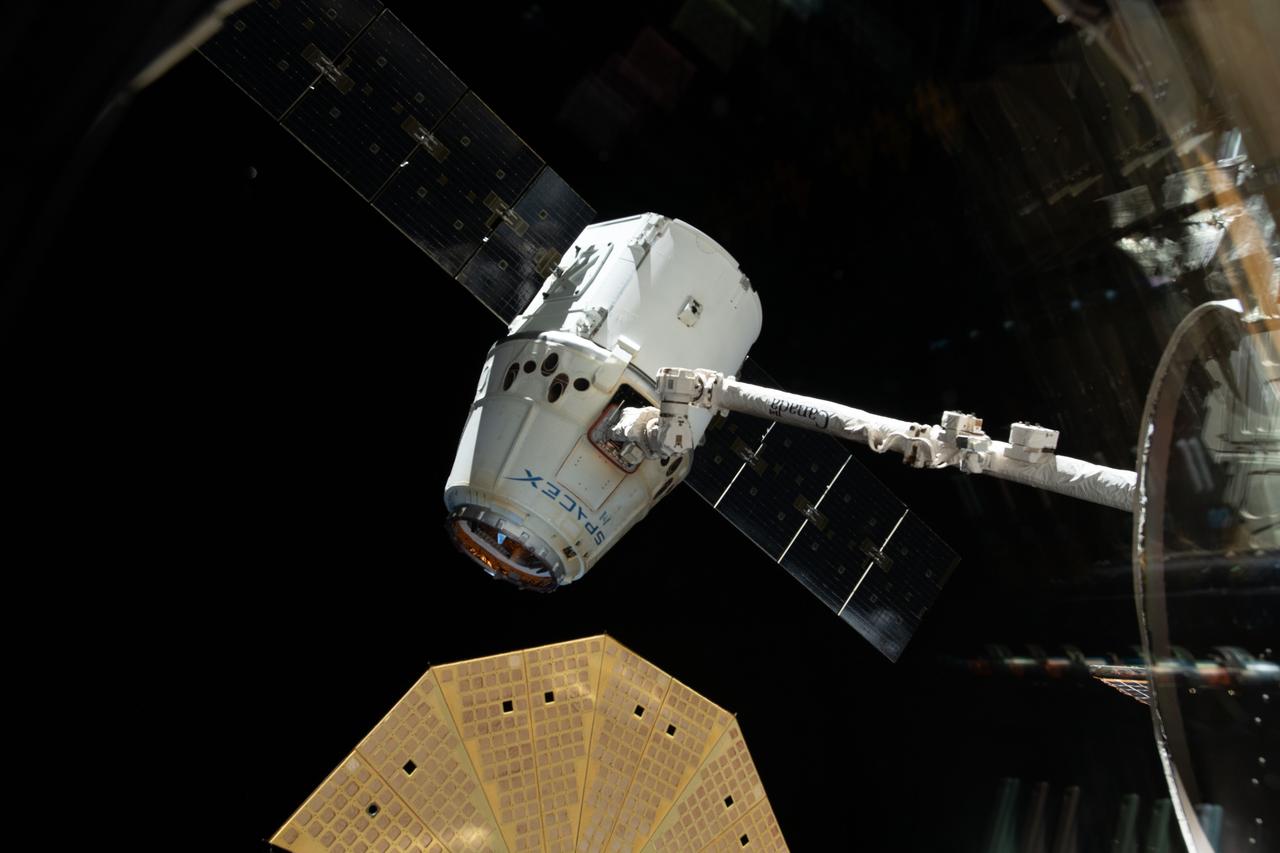
iss058e002666 (Jan. 13, 2019) --- The SpaceX Dragon cargo craft is pictured in the grips of the Canadarm2 robotic arm before its release and departure from the International Space Station. Featured prominently in the lower foreground is one of two cymbal-shaped UltraFlex solar arrays attached to the Northrop Grumman Cygnus resupply ship. The orbital complex was orbiting 254 miles above East Asia at the time this photograph was taken.

iss071e403651 (July 21, 2024) --- The 57.7-foot-long Canadarm2 robotic arm extends from the International Space Station's Harmony module as the orbital outpost soared 261 miles above the coast of Peru. Partially obscured in the top background, is the Boeing Starliner spacecraft docked to Harmony's forward port.
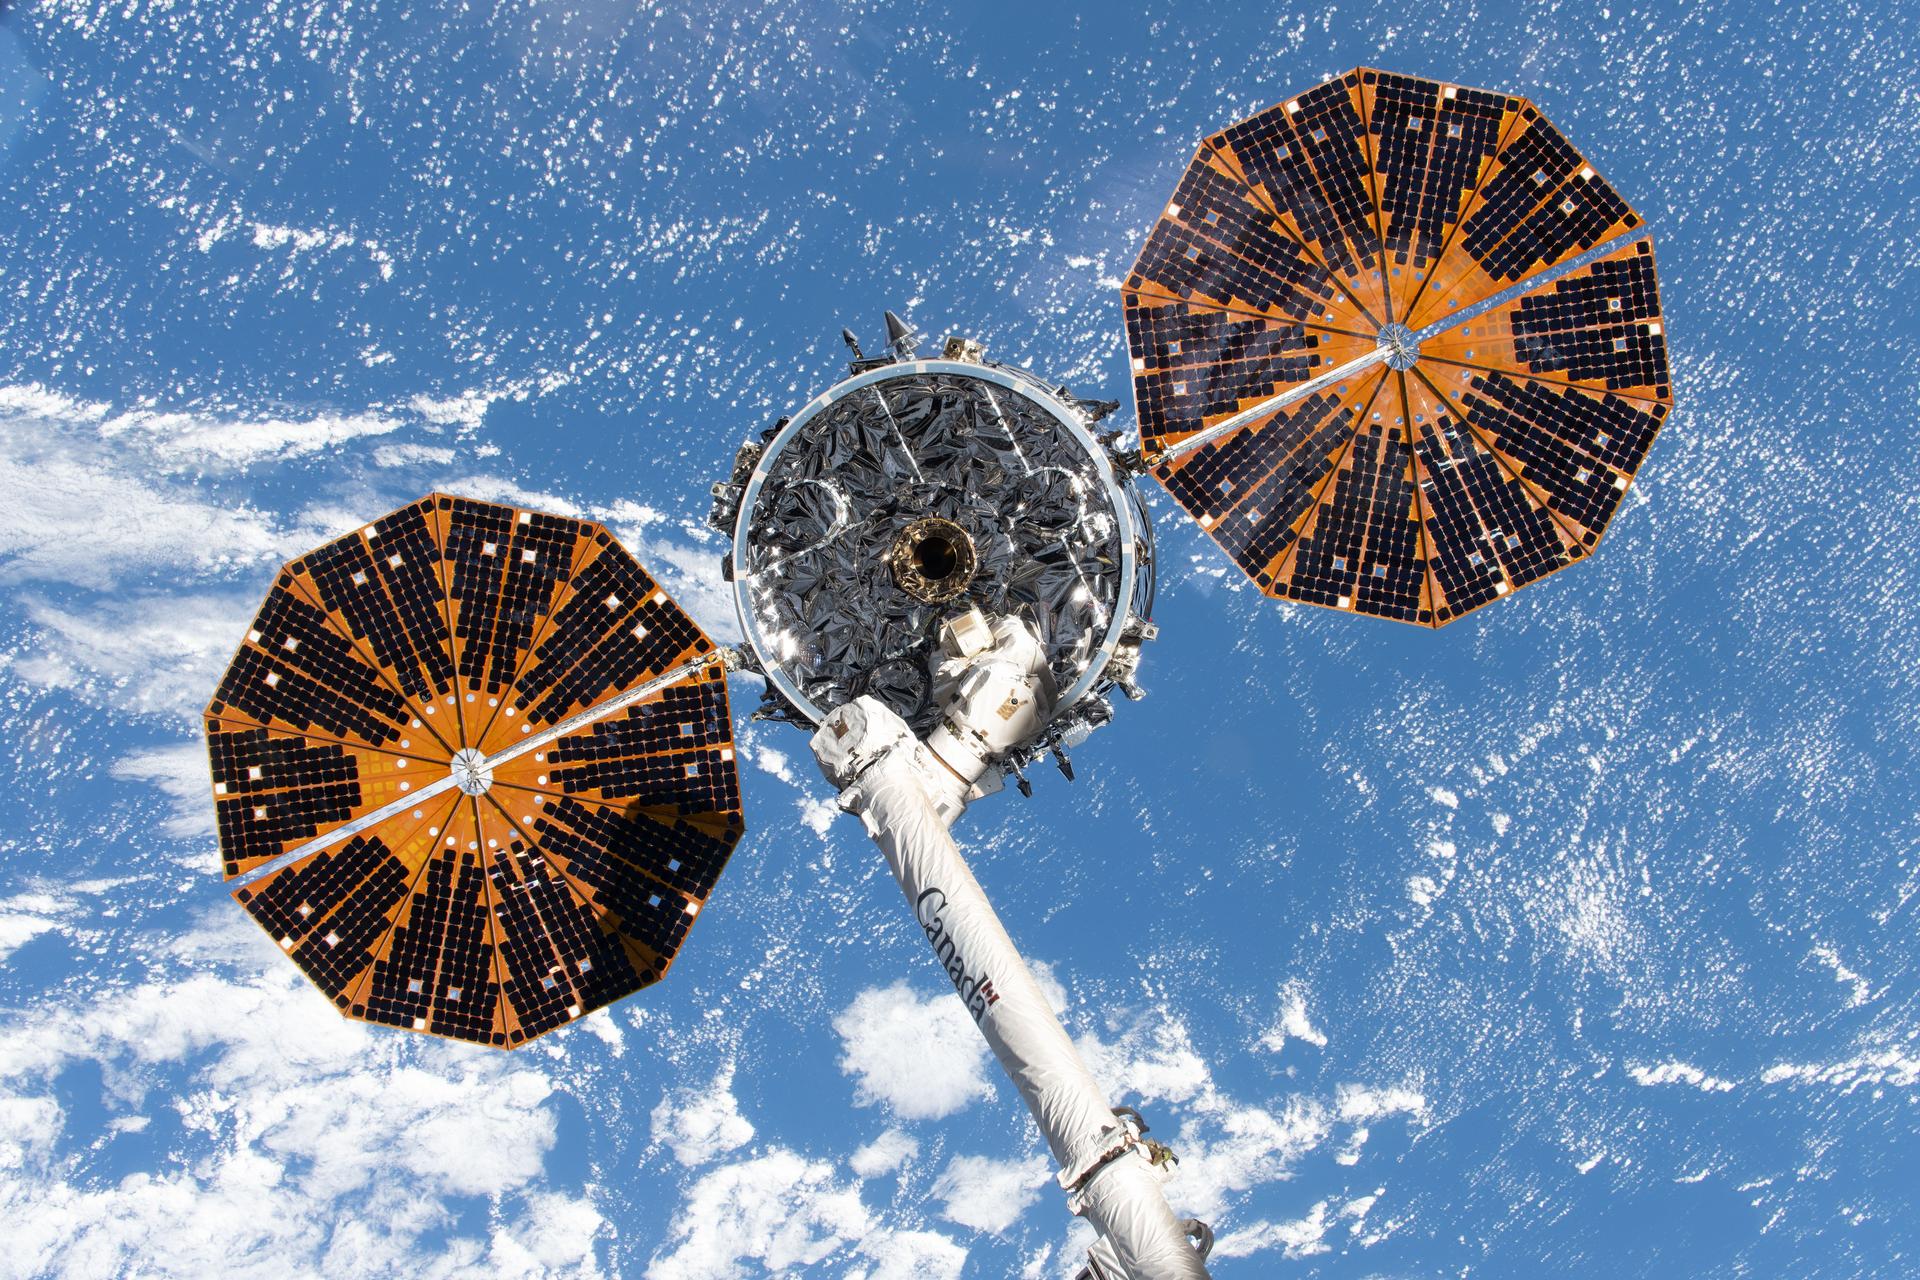
iss074e0378294 (March 12, 2026) --- Northrop Grumman's Cygnus XL cargo spacecraft, with its two prominent cymbal-shaped UltraFlex solar arrays, is in the grasp of the Canadarm2 robotic arm before being released and departing the International Space Station to complete its resupply mission. Credit: NASA/Jessica Meir
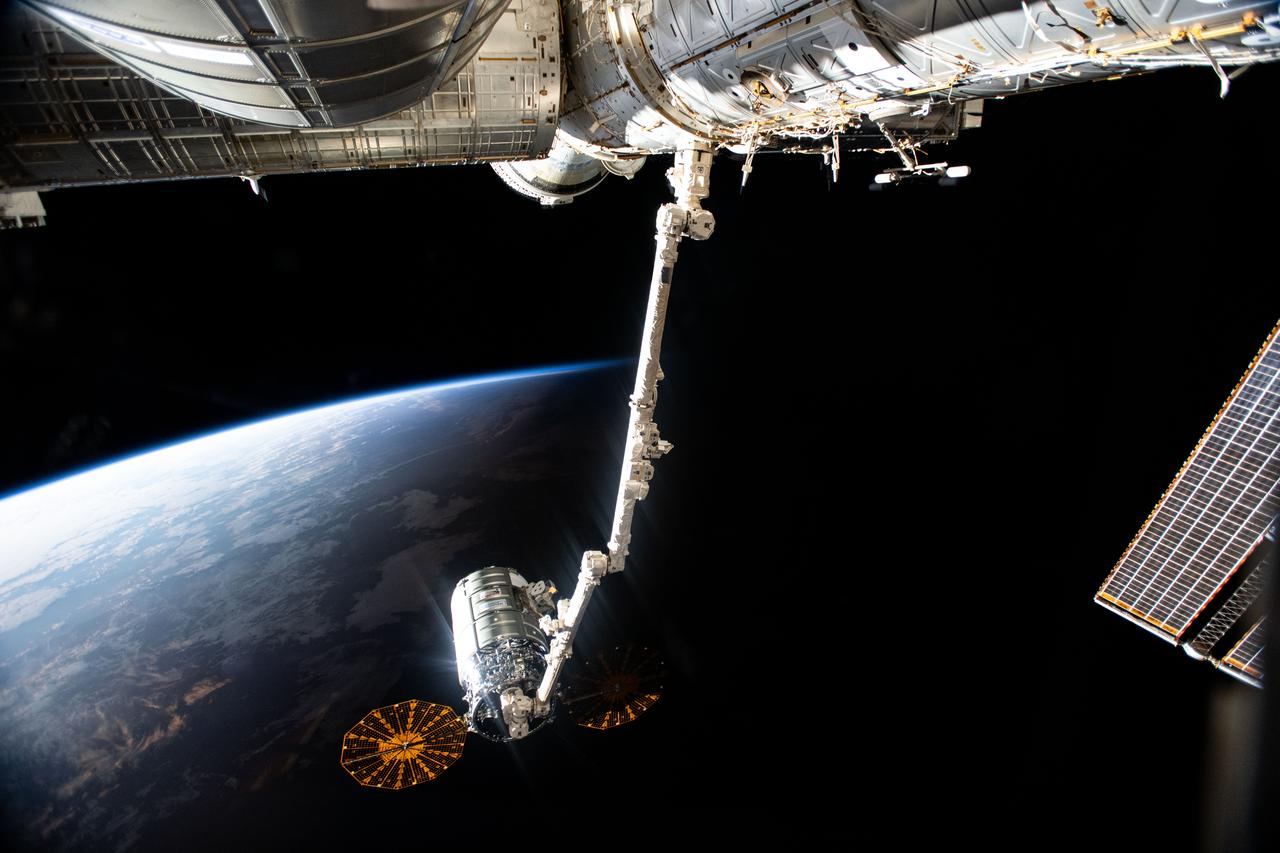
iss071e329922 (July 12, 2024) -- Northrop Grumman's Cygnus space freighter is pictured attached to the Canadarm2 robotic arm ahead of its release from the International Space Station's Unity module. The orbiting lab and Cygnus were soaring into orbital daytime as this photo was taken.
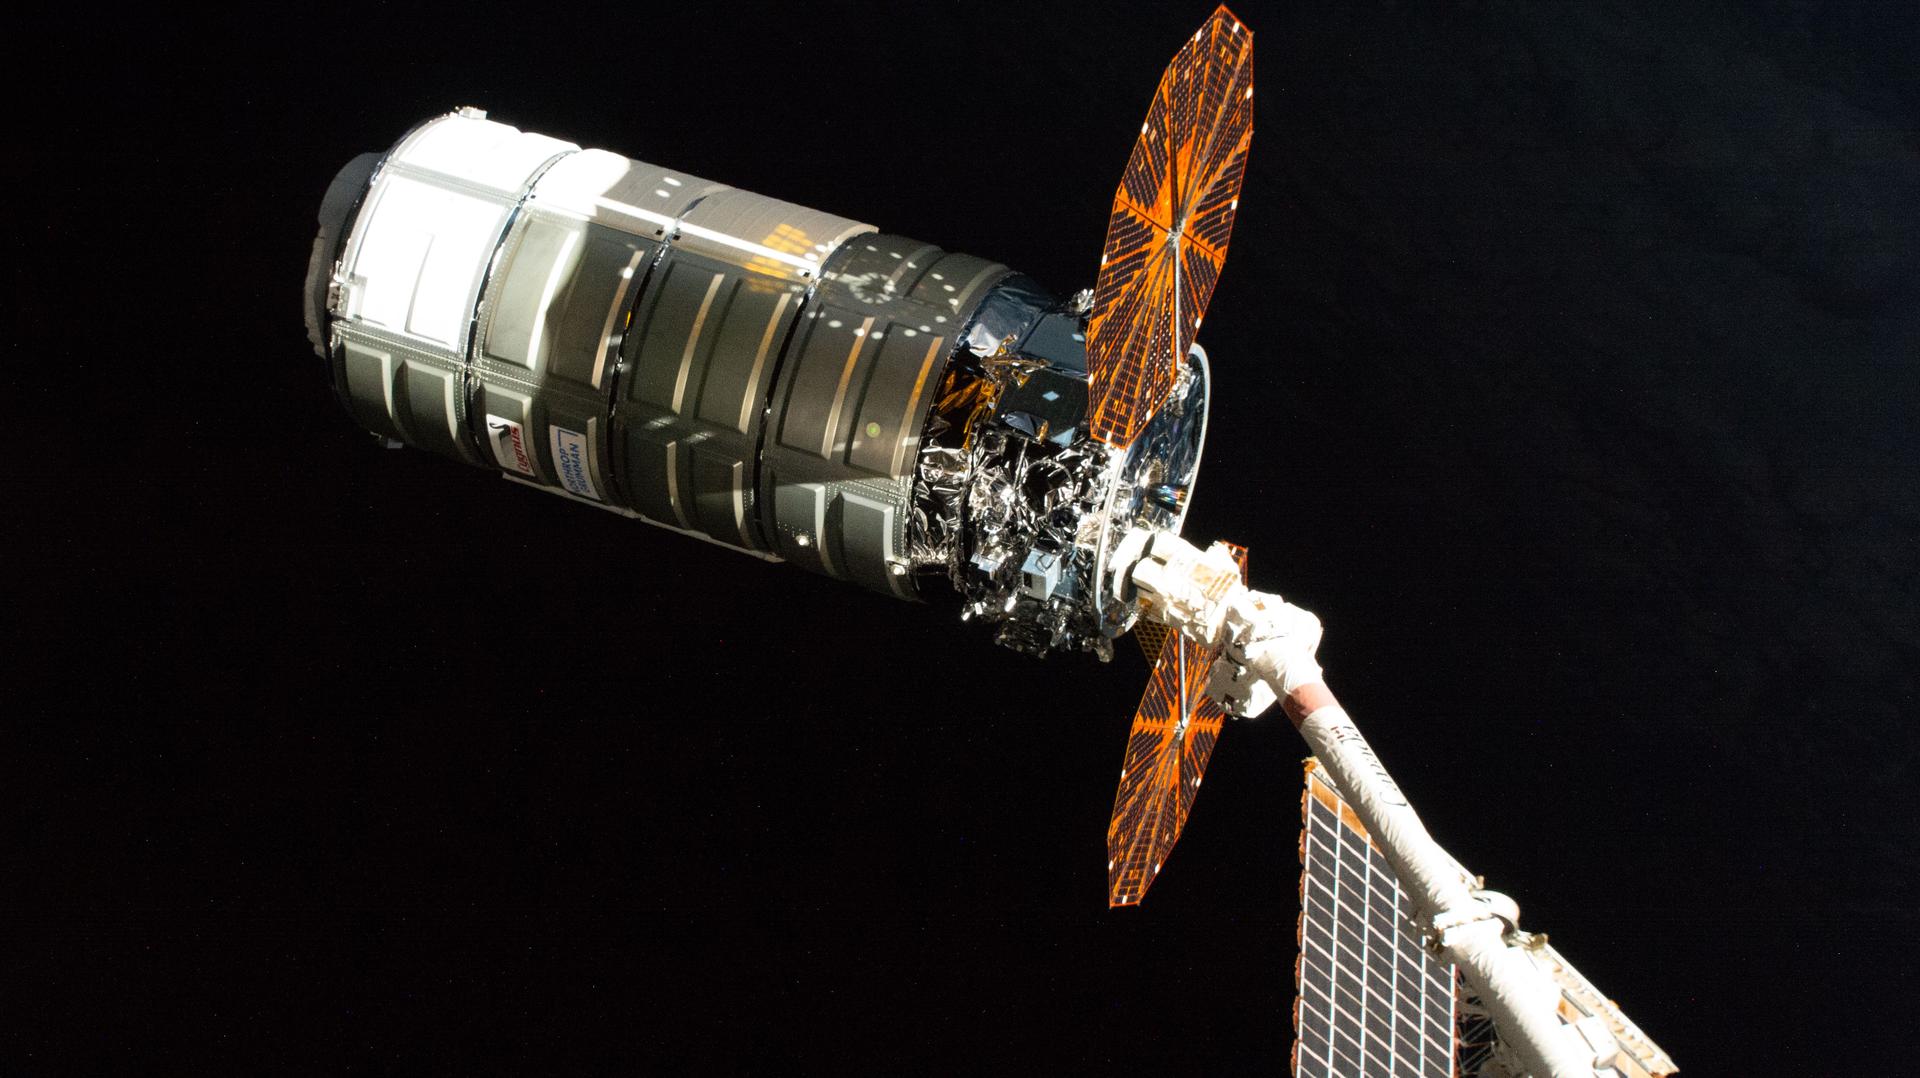
iss074e0458279 (April 13, 2026) --- Northrop Grumman's Cygnus XL cargo spacecraft, carrying over 11,000 pounds of new science experiments, lab hardware, and crew supplies, is pictured in the grips of the Canadarm2 robotic arm following its capture at the International Space Station. Credit: NASA
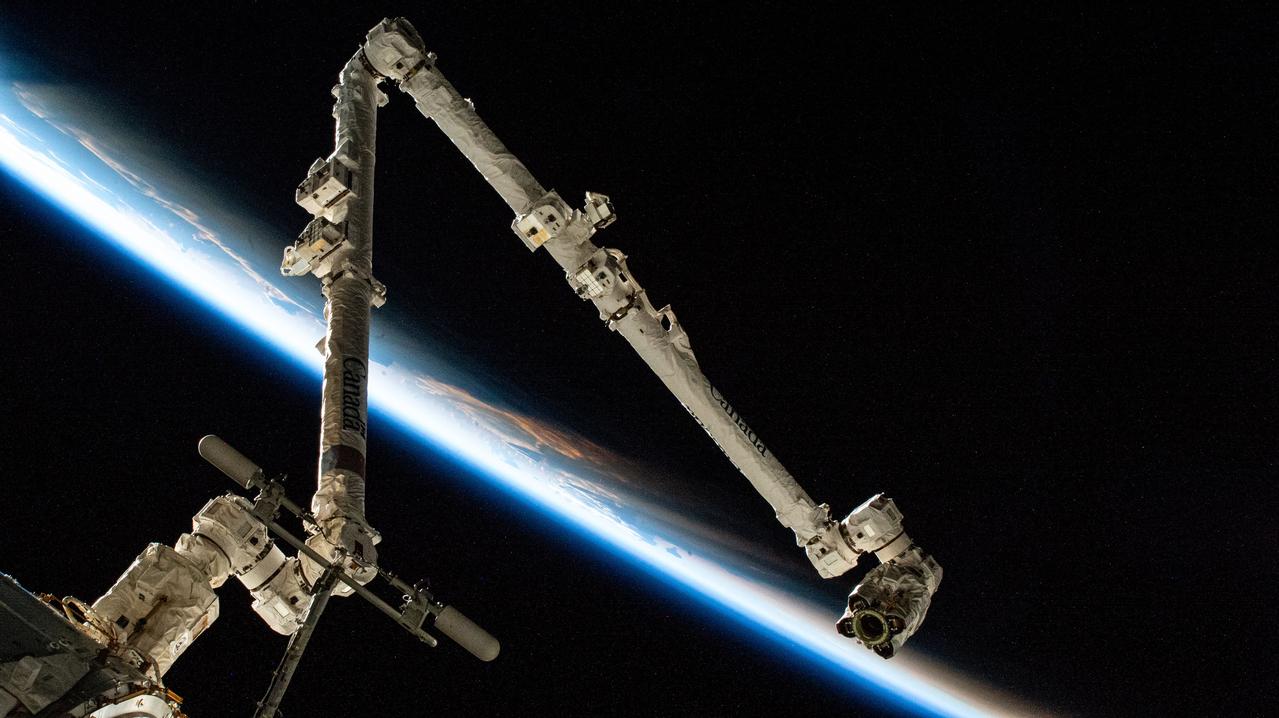
iss073e0657546 (Sept. 8, 2025) --- The 57.7-foot-long Canadarm2 robotic arm extends from a grapple fixture on the International Space Station as it soared into an orbital sunrise 260 miles above the Philippine Sea at approximately 4:04 a.m. local time.

iss073e0920711 (Oct. 21, 2025) --- The Canadarm2 robotic arm releases Northrop Grumman’s Cygnus XL cargo craft after it was installed on the Earth-facing port of the Unity module. The International Space Station was soaring into an orbital sunrise 269 miles above the Atlantic Ocean southwest of Cape Town, South Africa, at the time of this photgraph.
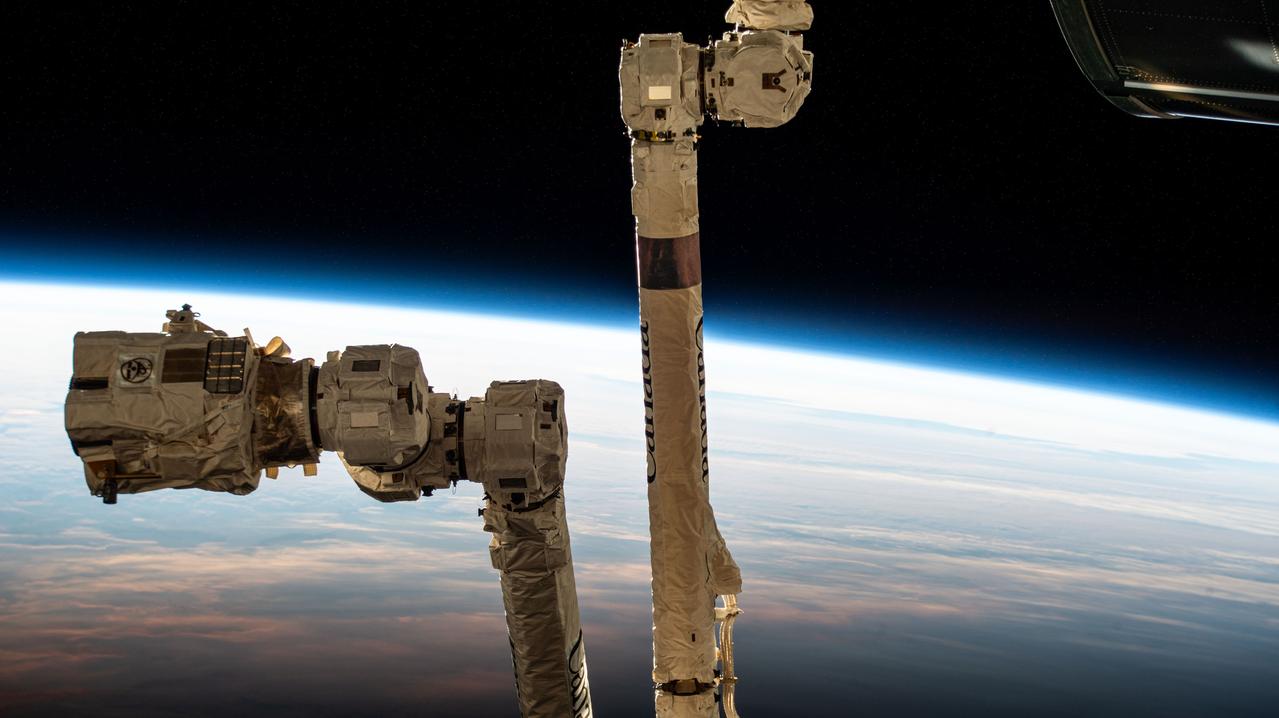
iss072e576480 (Jan. 31, 2025) --- The 57.7-foot-long Canadarm2 robotic arm with its latching end effector that can grapple spacecraft or maneuver spacewalkers is pictured as the International Space Station orbited into daylight 267 miles above the South Pacific Ocean just south of New Zealand's Auckland Islands.
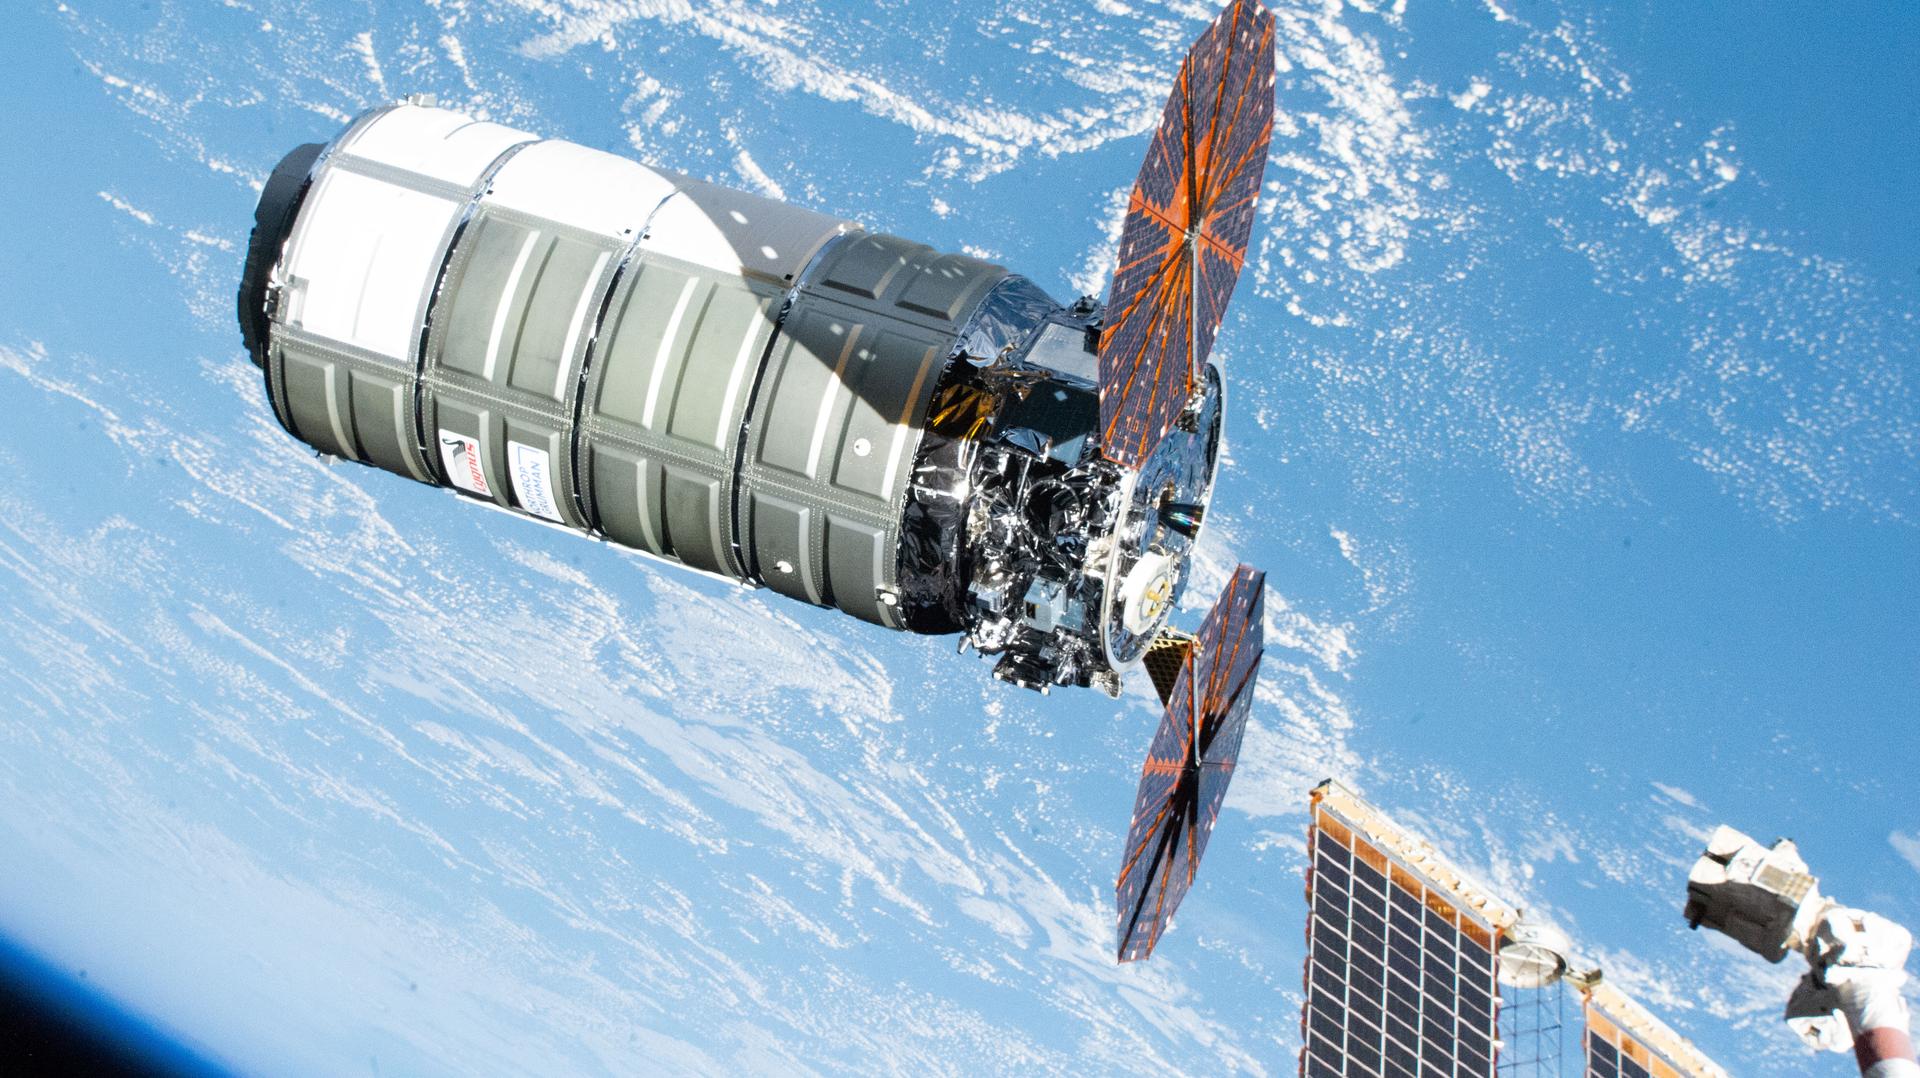
iss074e0458270 (April 13, 2026) --- Northrop Grumman's Cygnus XL cargo spacecraft, carrying over 11,000 pounds of new science experiments, lab hardware, and crew supplies, is pictured moments before its capture with the Canadarm2 robotic arm following its approach and rendezvous with the International Space Station. Credit: NASA
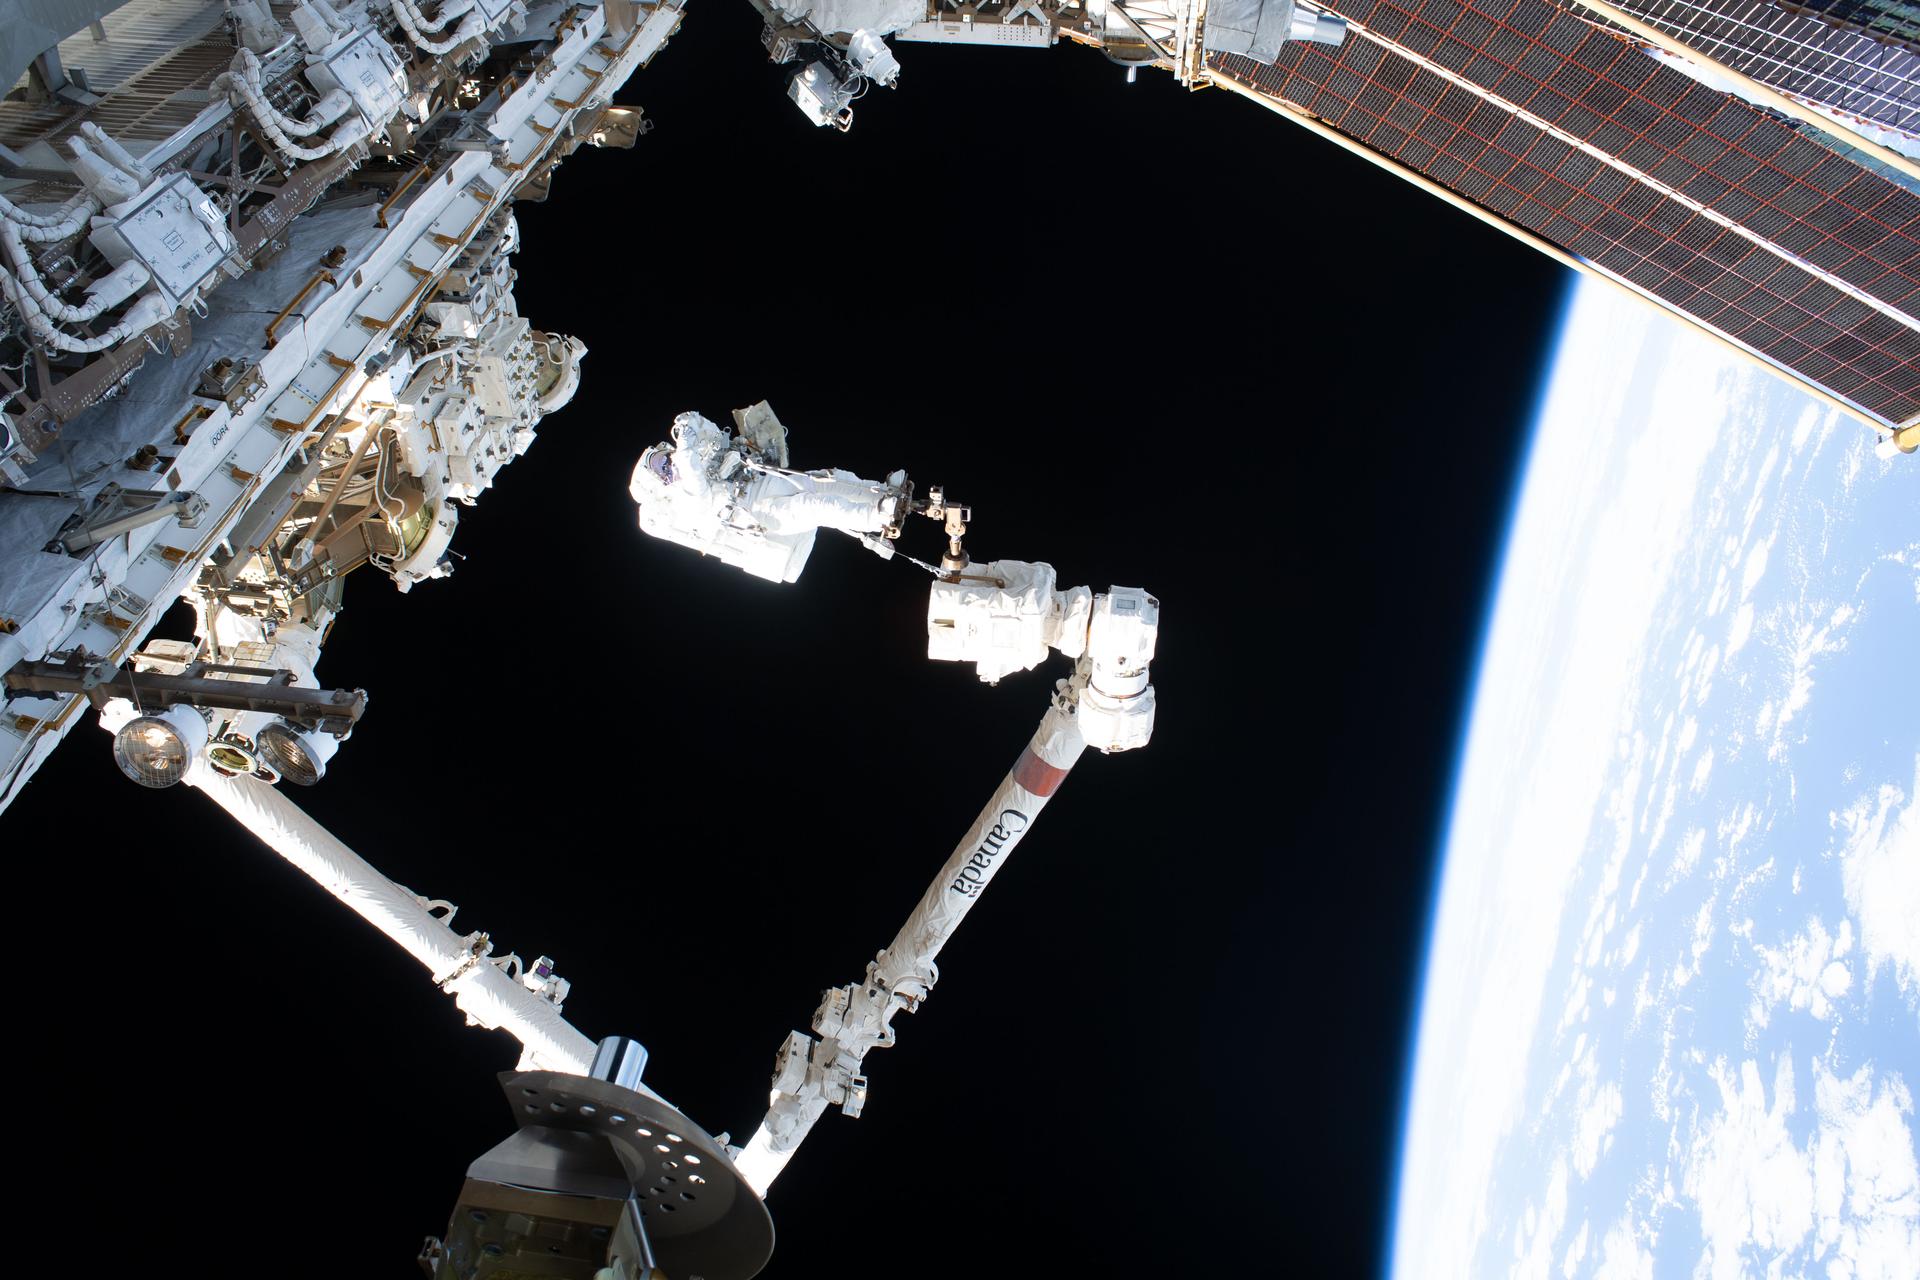
iss075e0086496 (Sept. 1, 2026) --- Expedition 75 commander Jessica Meir of NASA rides the Canadarm2 robotic arm during a spacewalk for navigation and science maintenance outside the International Space Station. Meir was attached to an articulating portable foot restraint installed on Canadarm2’s latching end effector. The orbital outpost was soaring 259 miles above the Pacific Ocean southwest of Mexico when this photograph was taken. Credit: NASA
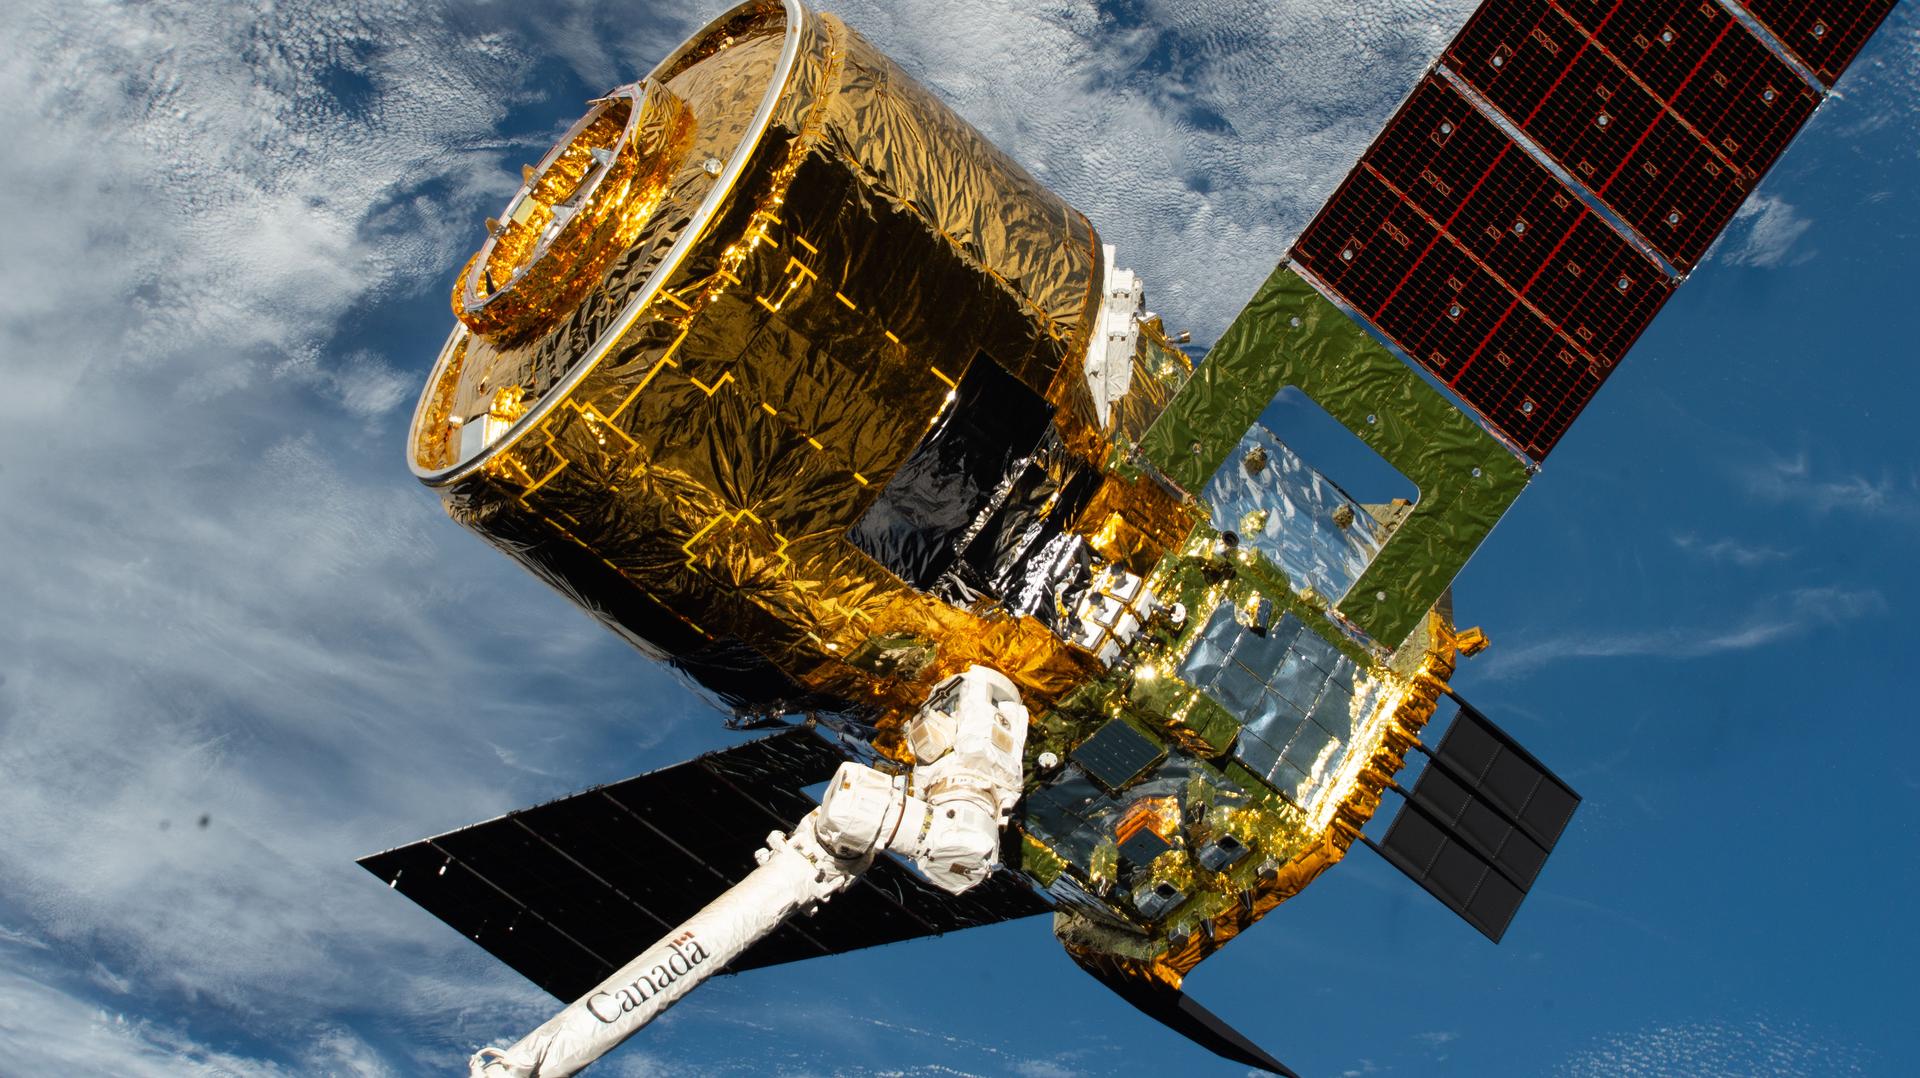
iss074e0365138 (March 6, 2026) --- The HTV‑X1 cargo spacecraft from JAXA (Japan Aerospace Exploration Agency) is grasped by the Canadarm2 robotic arm as the International Space Station orbits 271 miles above the Indian Ocean, off the coast of South Africa. Moments later, Canadarm2 would release HTV‑X1 into Earth orbit, completing the spacecraft’s four‑month stay attached to the orbital outpost’s Harmony module. Credit: NASA
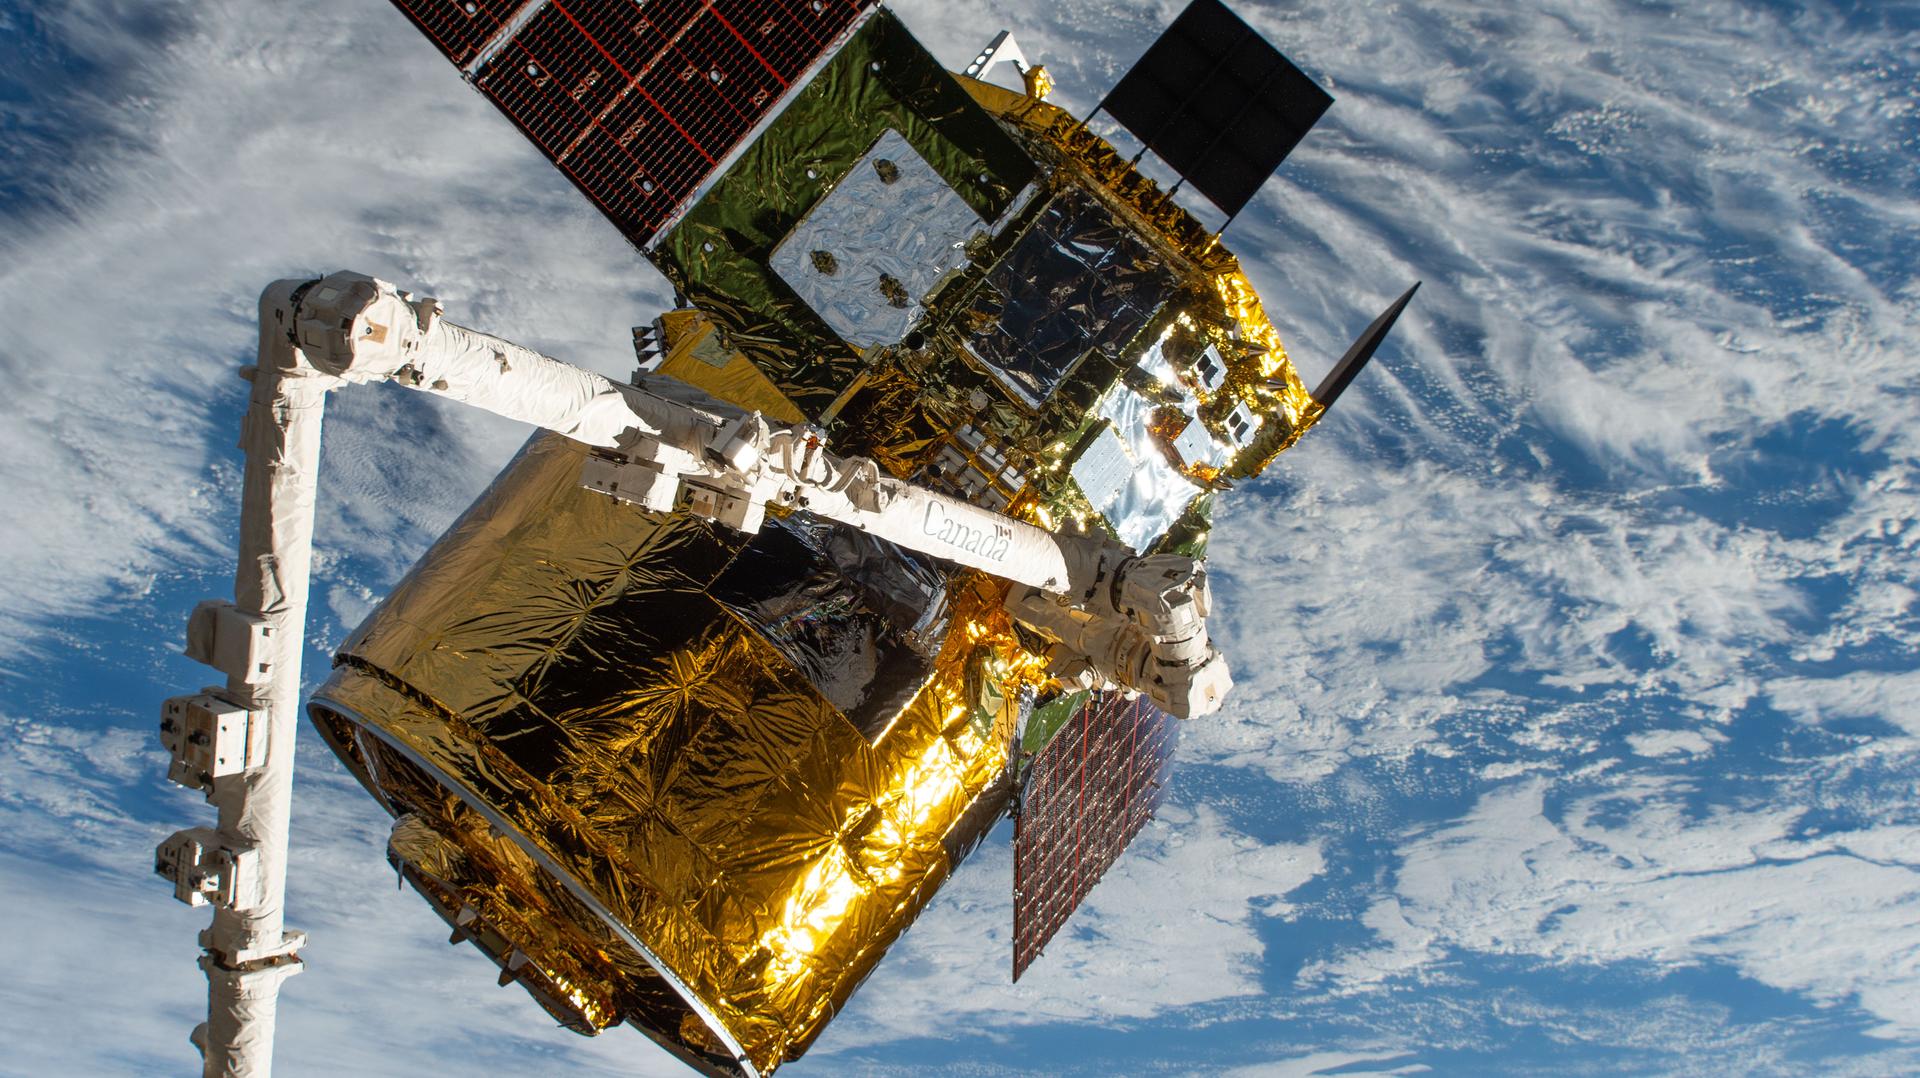
iss073e0988465 (Oct. 29, 2025) --- The new HTV-X1 cargo spacecraft from JAXA (Japan Aerospace Exploration Agency), carrying about 12,800 pounds of science, supplies, and hardware for the Expedition 73 crew, is pictured in the grip of the Canadarm2 robotic arm. JAXA astronaut and Expedition 73 Flight Engineer Kimiya Yui (not pictured) commanded Canadarm2 to gently reach out and capture HTV-X1 when the spacecraft reached a point about 10 meters away from the International Space Station.
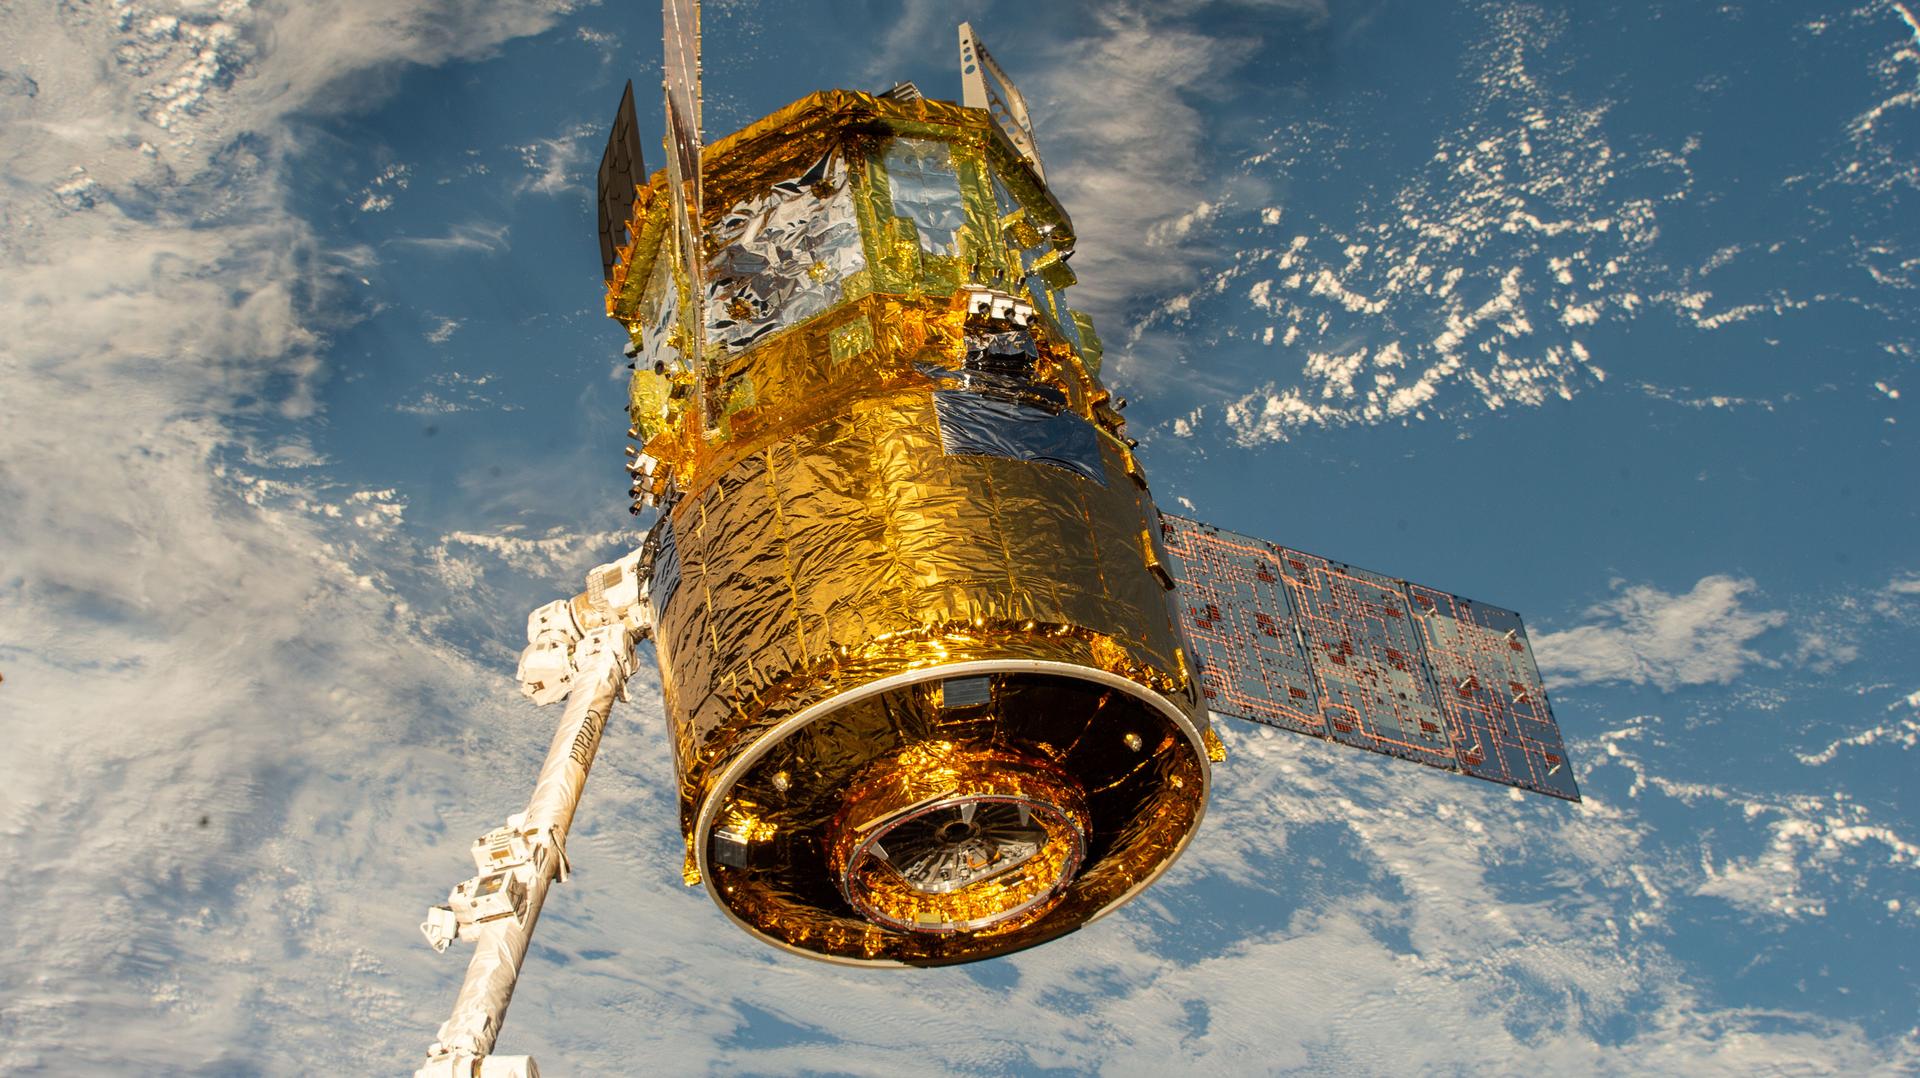
iss074e0365023 (March 6, 2026) --- The HTV‑X1 cargo spacecraft from JAXA (Japan Aerospace Exploration Agency) is grasped by the Canadarm2 robotic arm as the International Space Station orbits 271 miles above the Indian Ocean, southeast of Madagascar. Moments later, Canadarm2 would release HTV‑X1 into Earth orbit, completing the spacecraft’s four‑month stay attached to the orbital outpost’s Harmony module. Credit: NASA
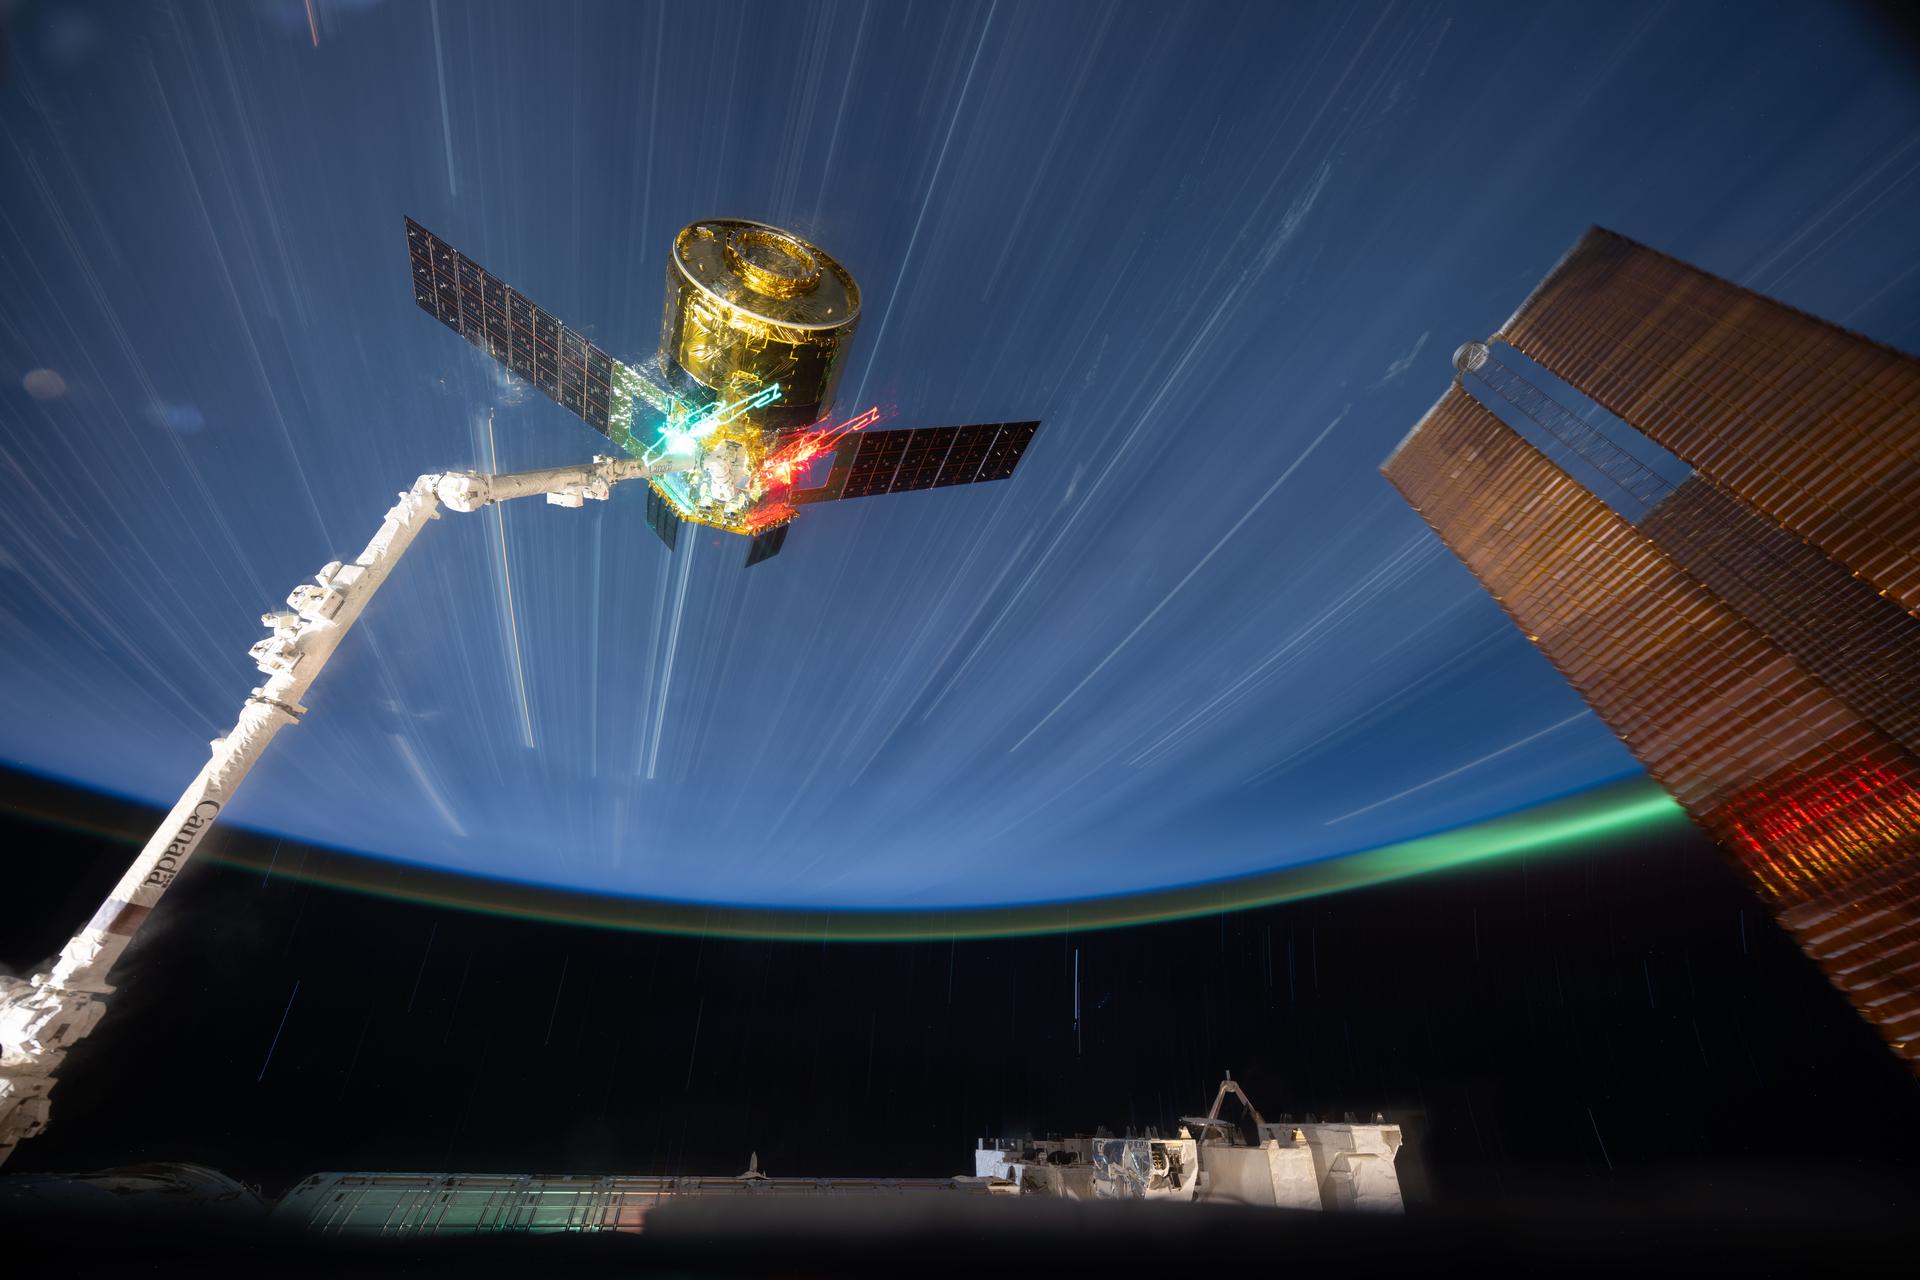
iss074e0367686 (March 26, 2026) --- The HTV‑X1 cargo spacecraft from JAXA (Japan Aerospace Exploration Agency) is grasped by the Canadarm2 robotic arm in this long-duration photograph from the International Space Station as it orbited 265 miles above northeastern China. Moments later, Canadarm2 would release HTV‑X1 into Earth orbit, completing the spacecraft’s four‑month stay attached to the orbital outpost’s Harmony module. Credit: NASA/Chris Williams
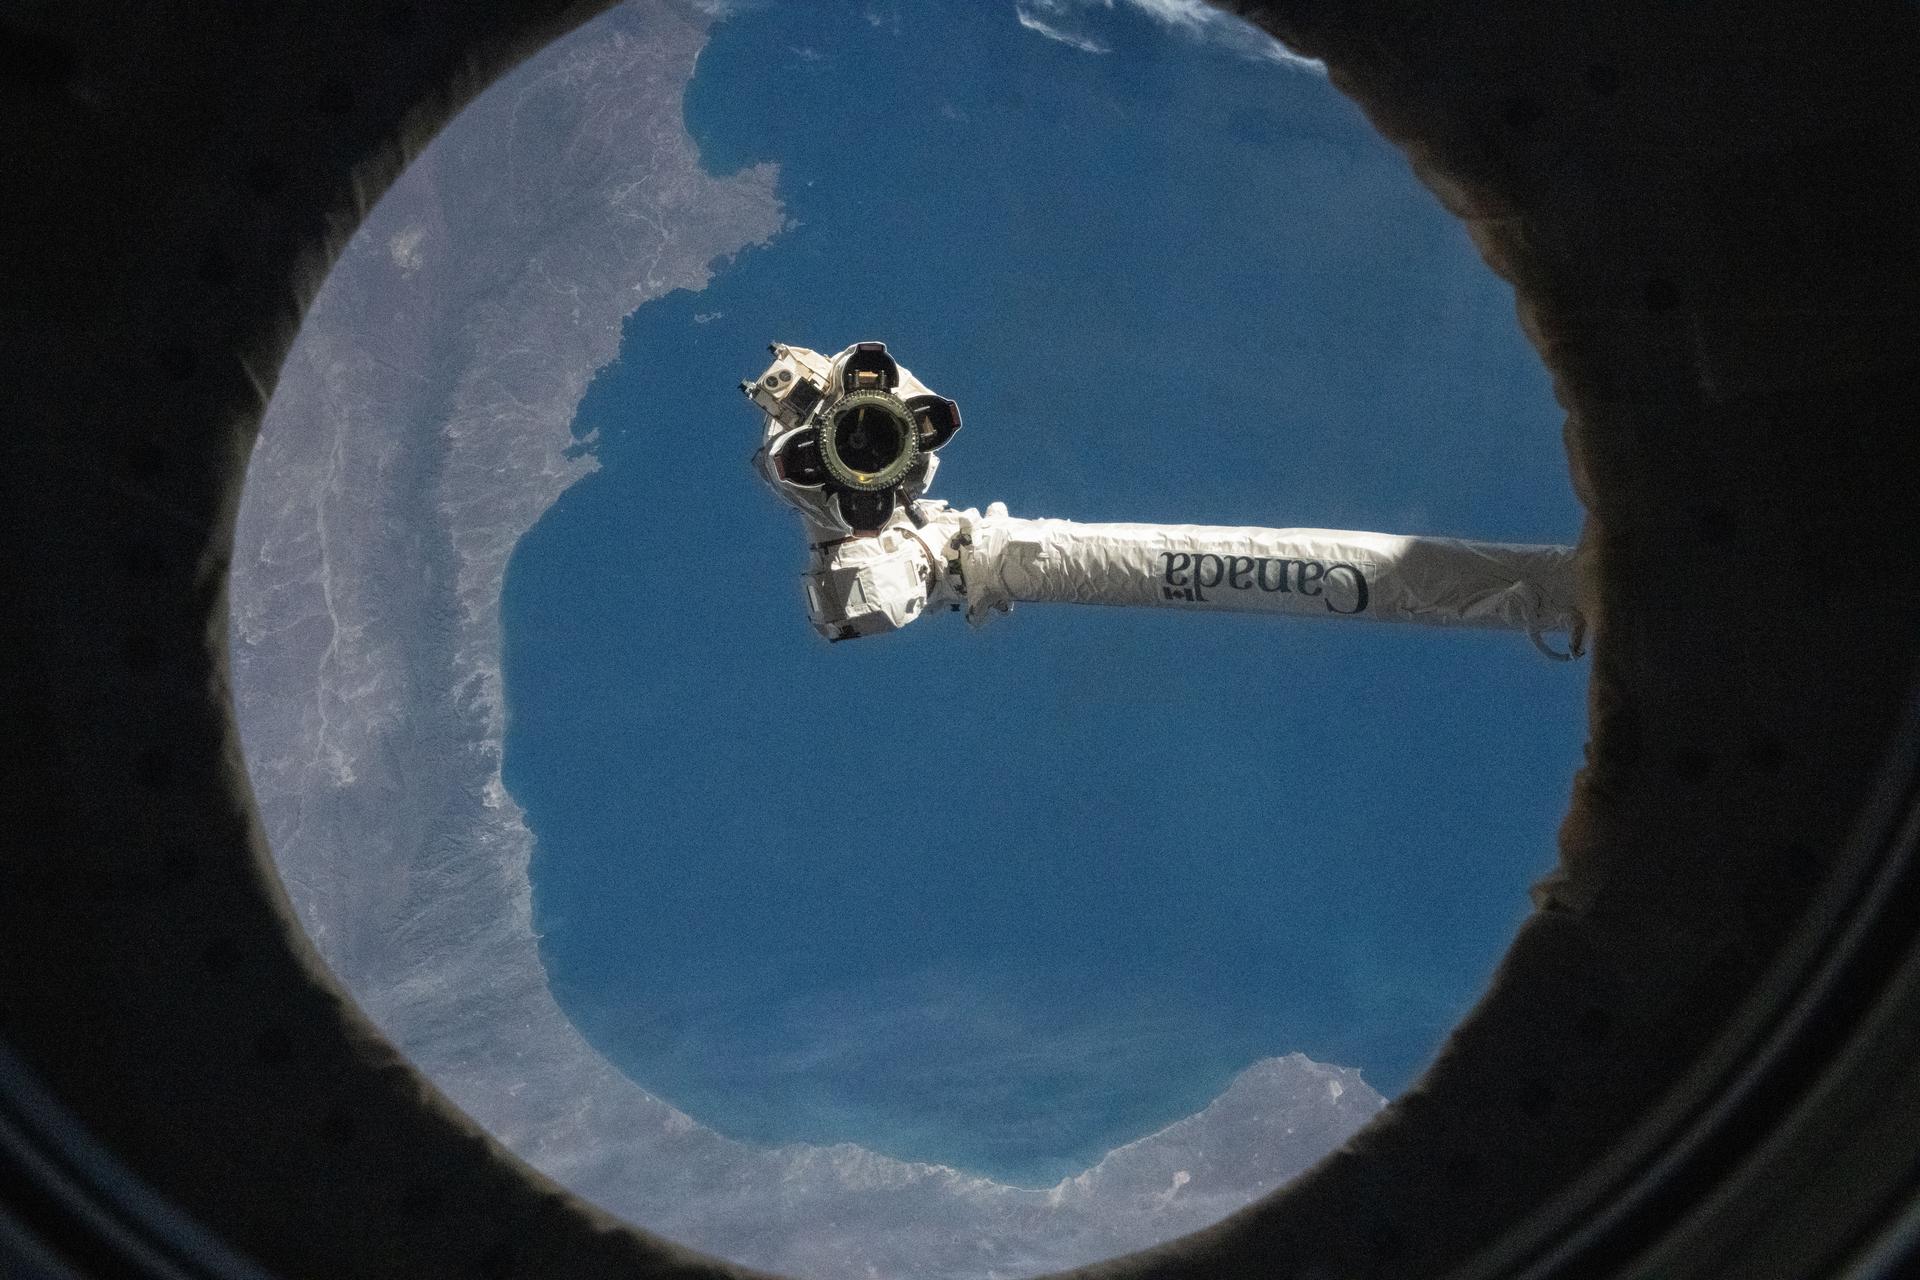
iss074e0378958 (March 12, 2026) --- The Canadarm2 robotic arm's latching end effector, or LEE, is pictured from a window on the International Space Station after it had released Norrthrop Grumman's Cygnus XL cargo spacecraft into Earth orbit ending its resupply mission. The orbitial outpost was soaring 271 miles above the Atlantic Ocean off the coast of southern Argentina when this photograph was taken. Credit: NASA/Chris Williams
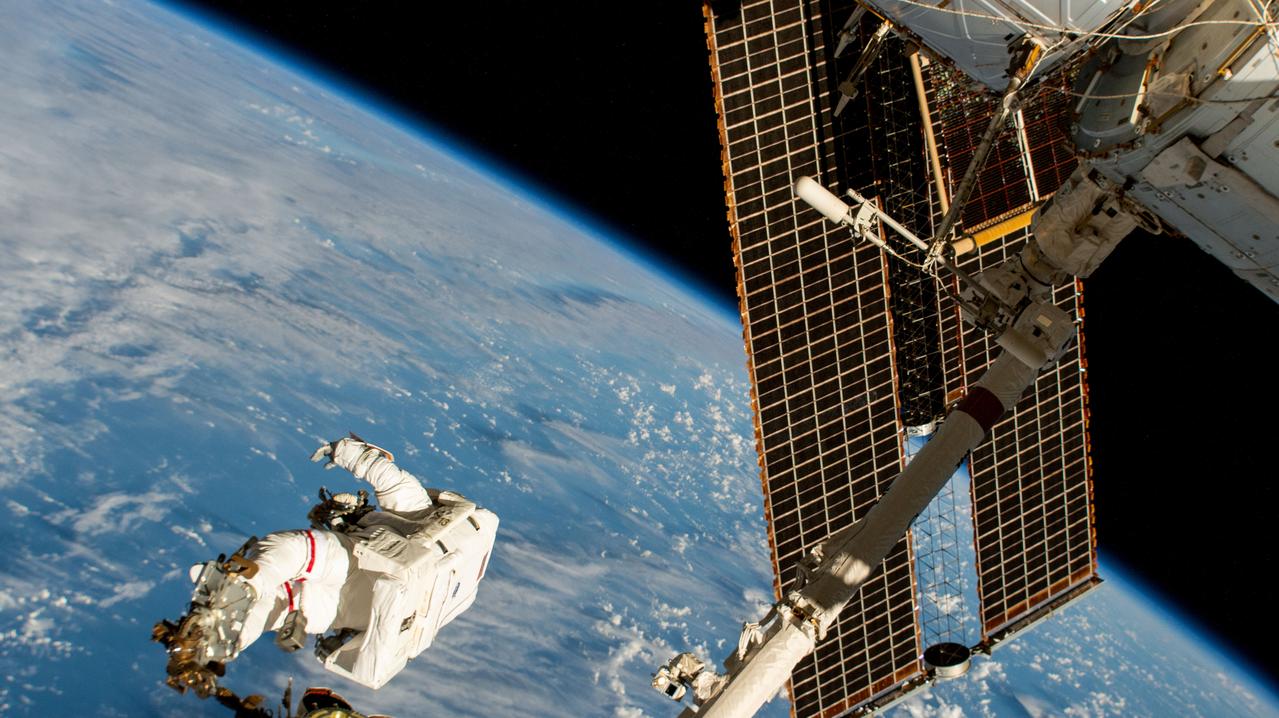
iss072e574907 (Jan. 30, 2025) --- NASA astronaut and Expedition 72 Commander Suni Williams is attached to the Canadarm2 robotic arm's latching end effector while being maneuvered to her worksite 264 miles above the South Pacific Ocean. Williams removed and stowed a radio frequency group antenna assembly during the five-hour and 26-minute spacewalk outside the International Space Station.
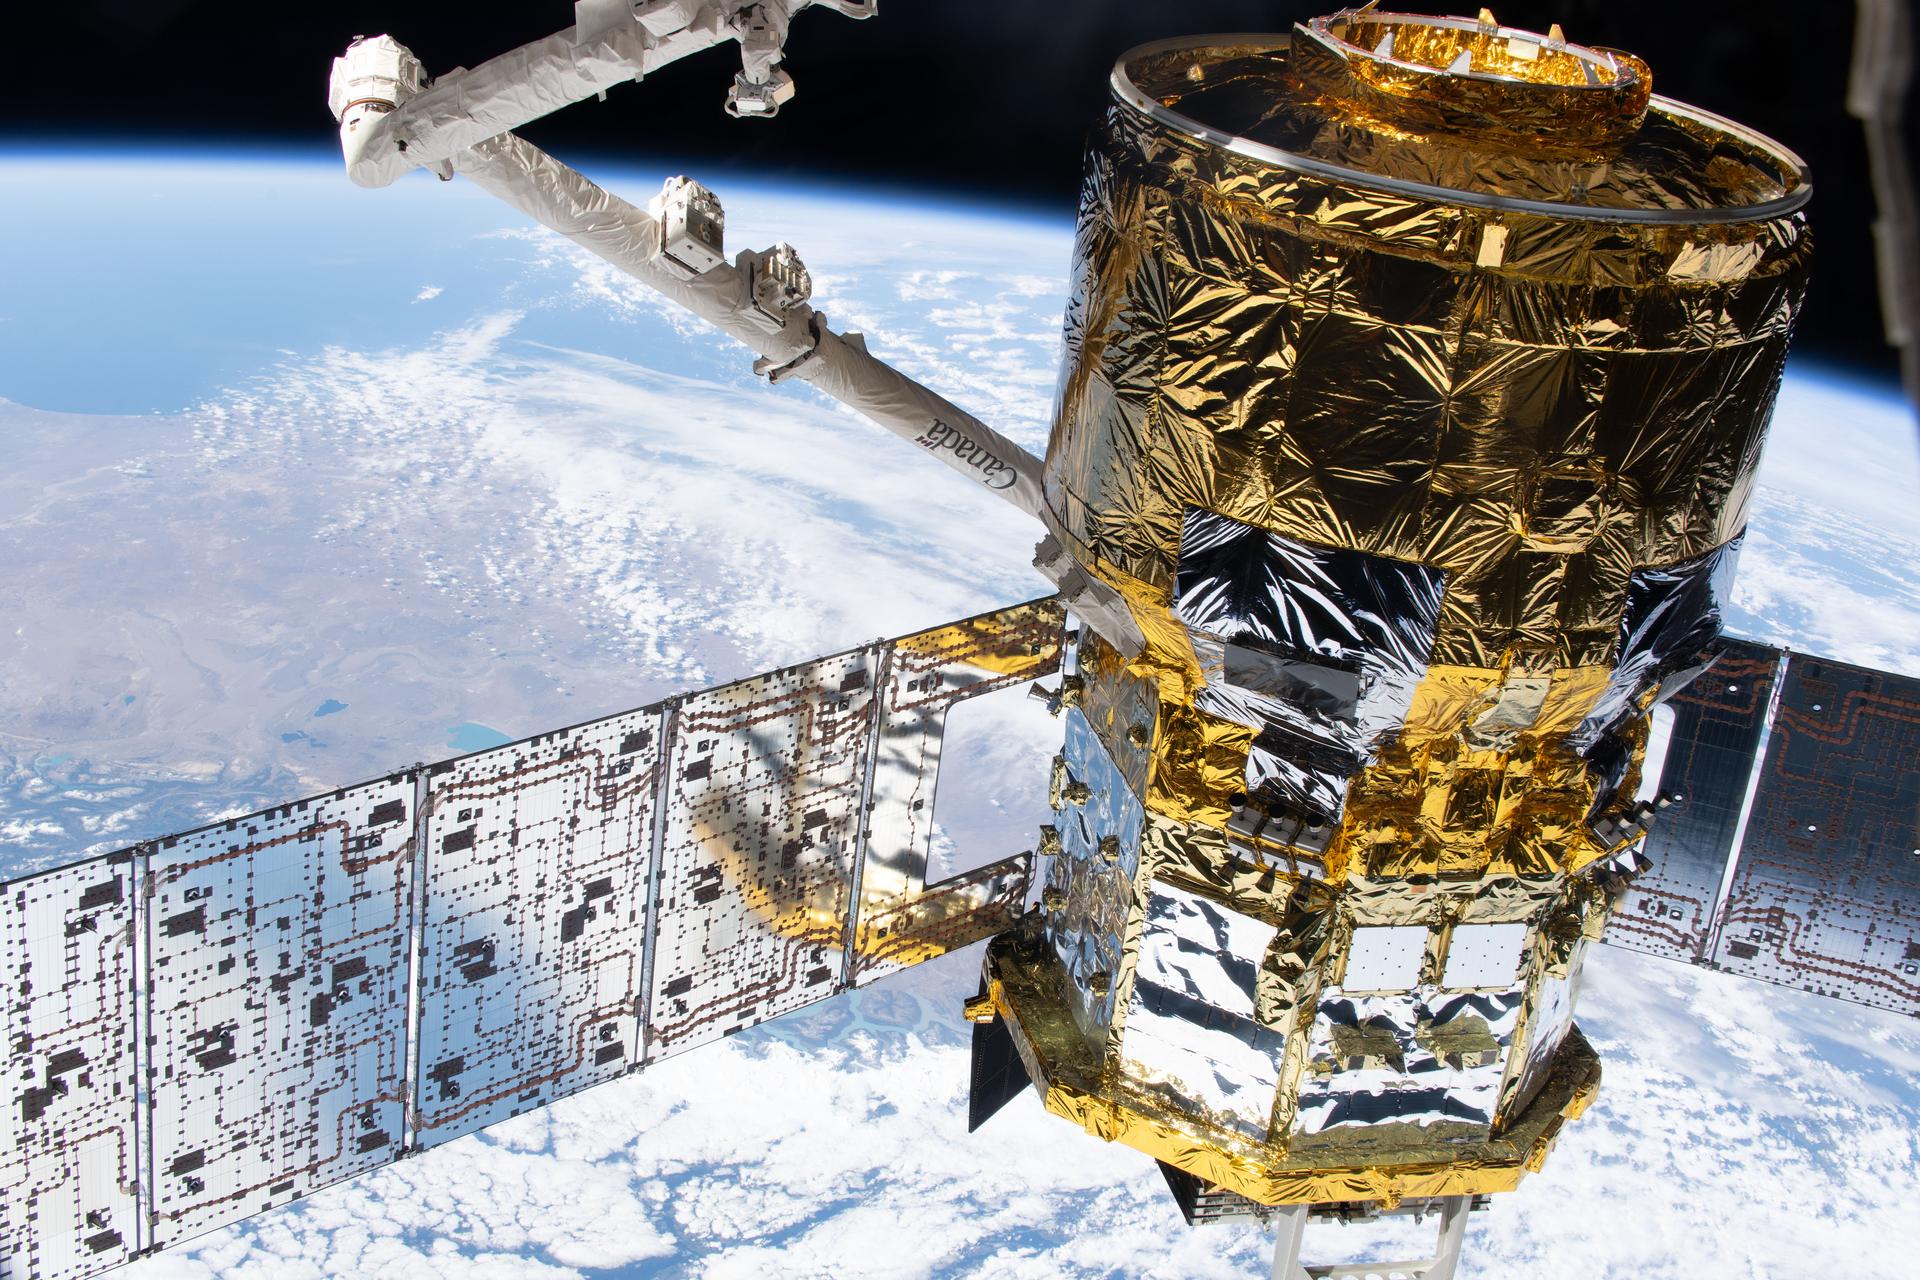
iss074e0364790 (March 5, 2026) --- The HTV‑X1 cargo spacecraft from JAXA (Japan Aerospace Exploration Agency) is in the grasp of the Canadarm2 robotic arm after being detached from the Earth‑facing port of the International Space Station’s Harmony module. The orbital outpost was soaring 274 miles above the Pacific Ocean off the coast of South America’s Patagonia region at the time of this photograph. Credit: NASA/Jessica Meir
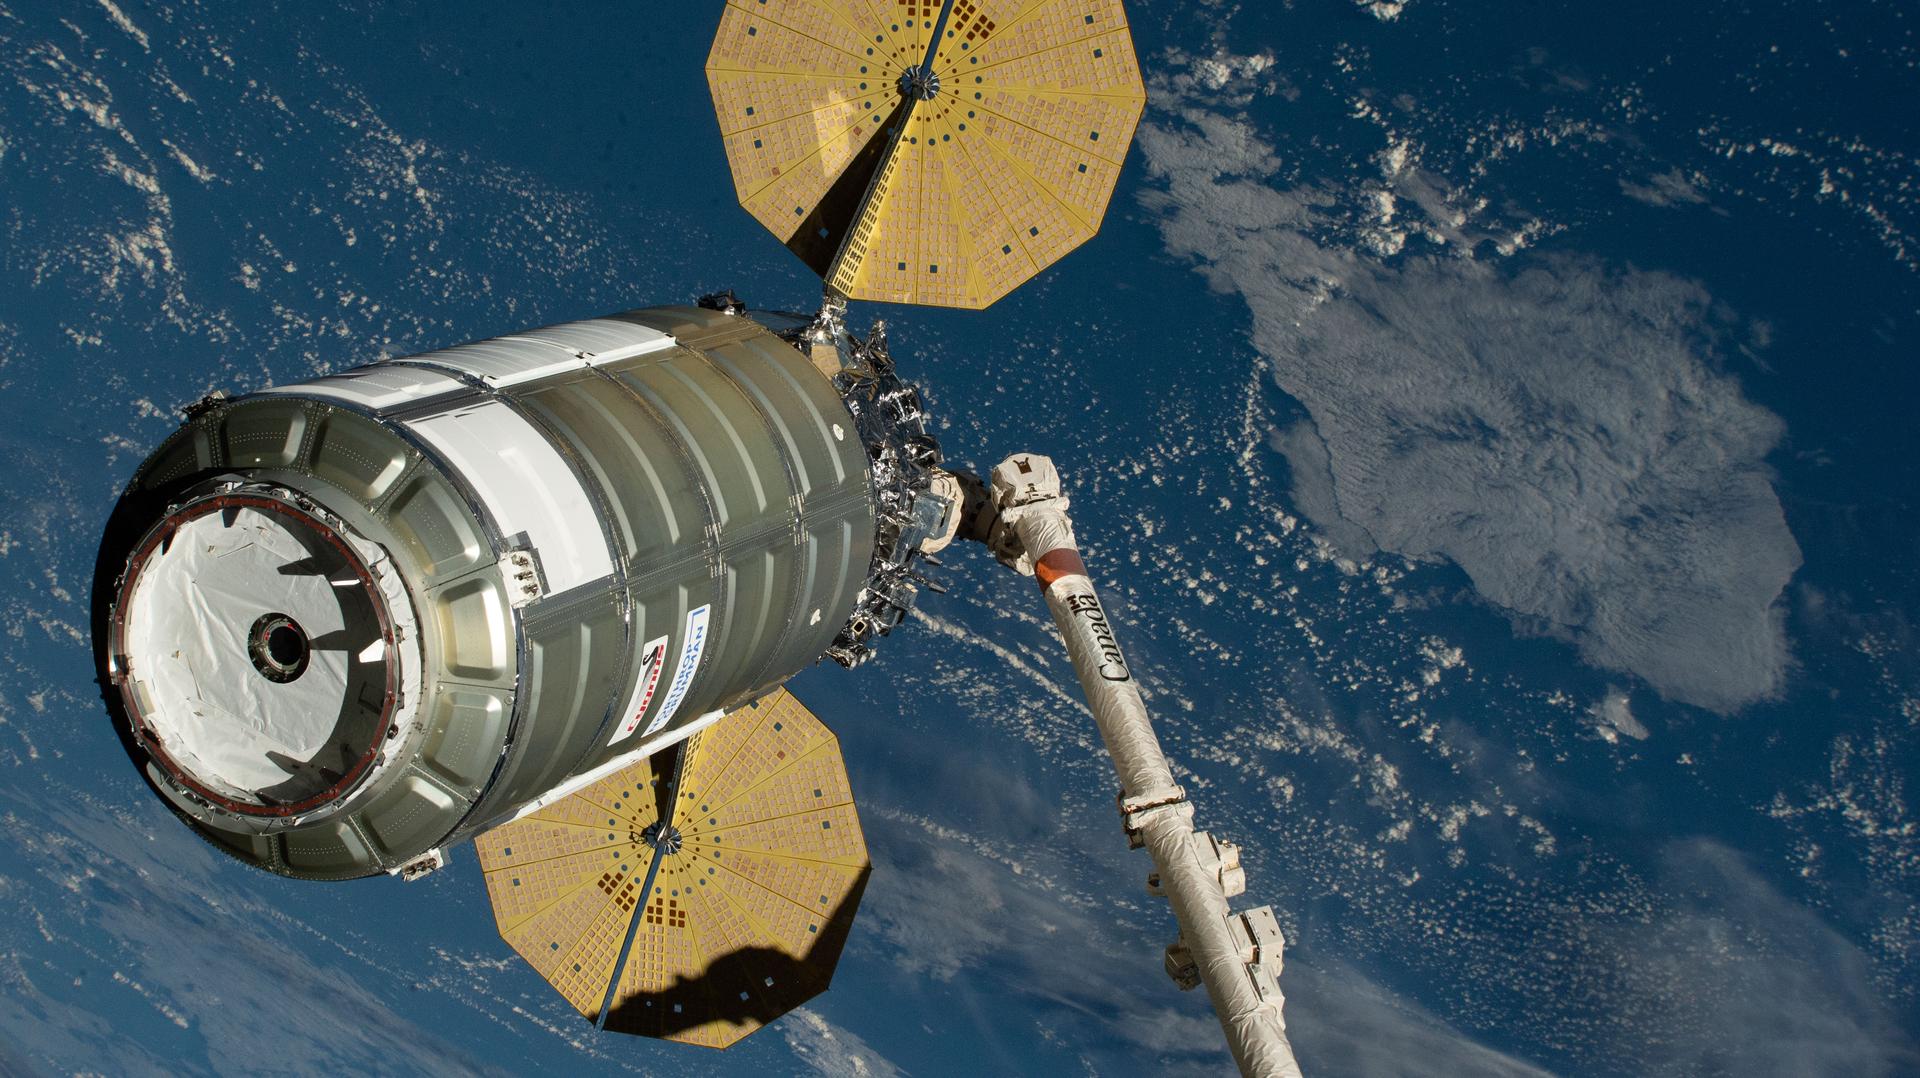
iss074e0459130 (April 13, 2026) --- Northrop Grumman's Cygnus XL cargo spacecraft is held in the grips of the Canadarm2 robotic arm as it is maneuvered toward the International Space Station’s Unity module for installation. Cygnus XL delivered more than 11,000 pounds of new science experiments, lab hardware, and crew supplies for the Expedition 74 crew. Credit: NASA
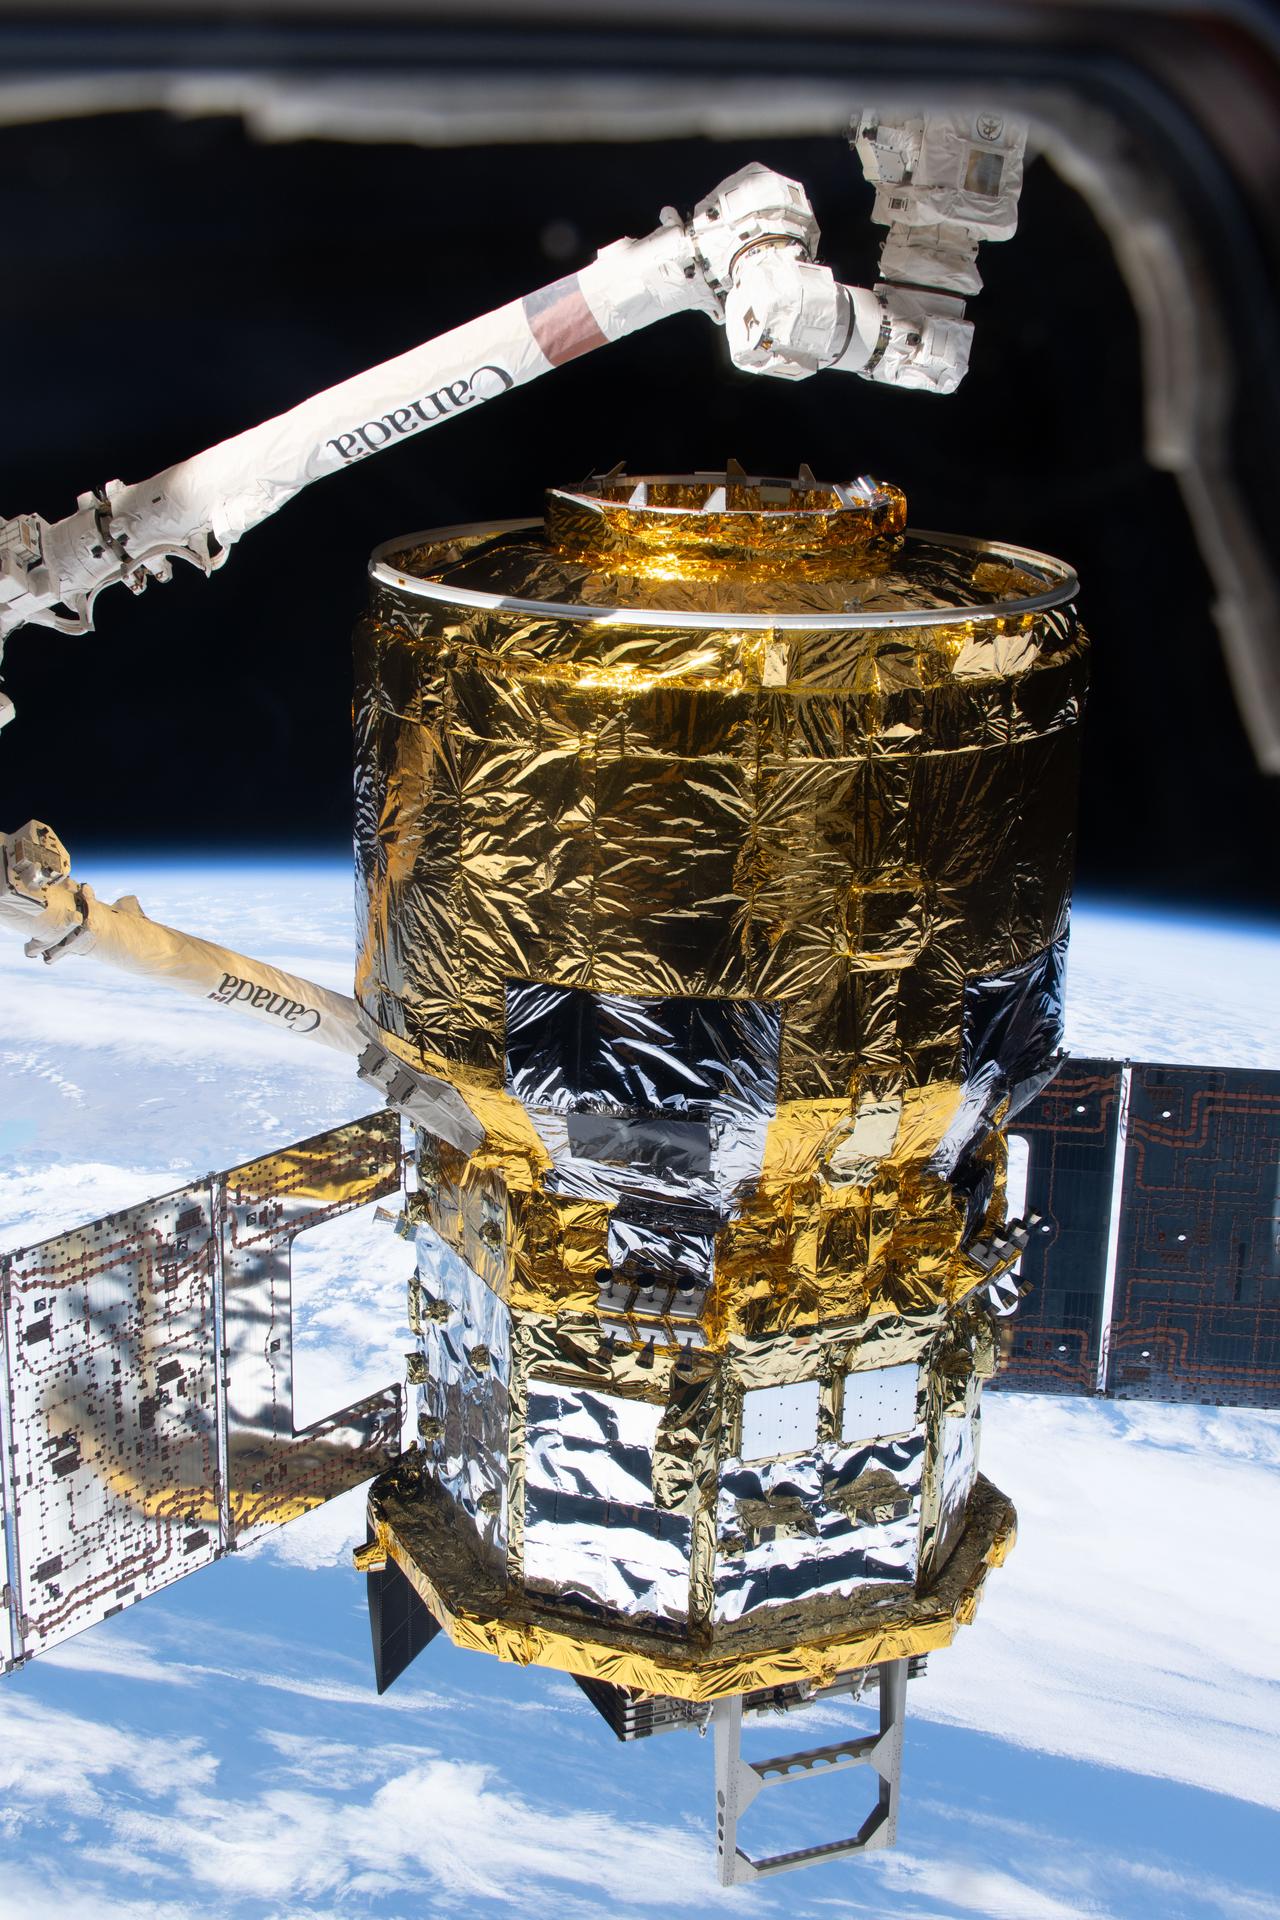
iss074e0364782 (March 5, 2026) --- The HTV‑X1 cargo spacecraft from JAXA (Japan Aerospace Exploration Agency) is in the grasp of the Canadarm2 robotic arm after being detached from the Earth‑facing port on the International Space Station’s Harmony module. The orbital outpost was soaring 274 miles above the Pacific Ocean off the coast of South America’s Patagonia region at the time of this photograph. Credit: NASA/Jessica Meir
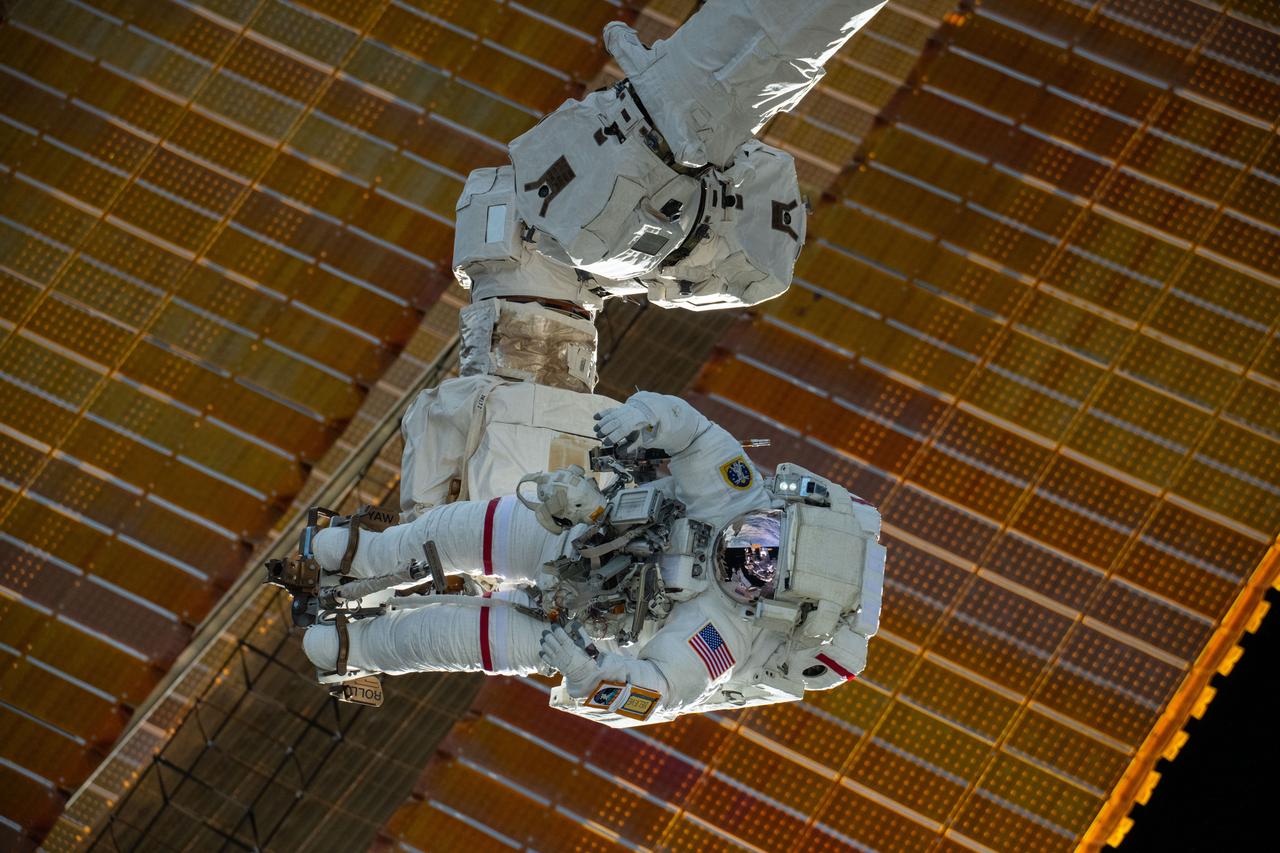
iss072e595502 (Jan. 30, 2025) --- NASA astronaut and Expedition 72 Commander Suni Williams is attached to the Canadarm2 robotic arm's latching end effector while being maneuvered to her worksite 264 miles above the South Pacific Ocean. Williams removed and stowed a radio frequency group antenna assembly during the five-hour and 26-minute spacewalk outside the International Space Station.
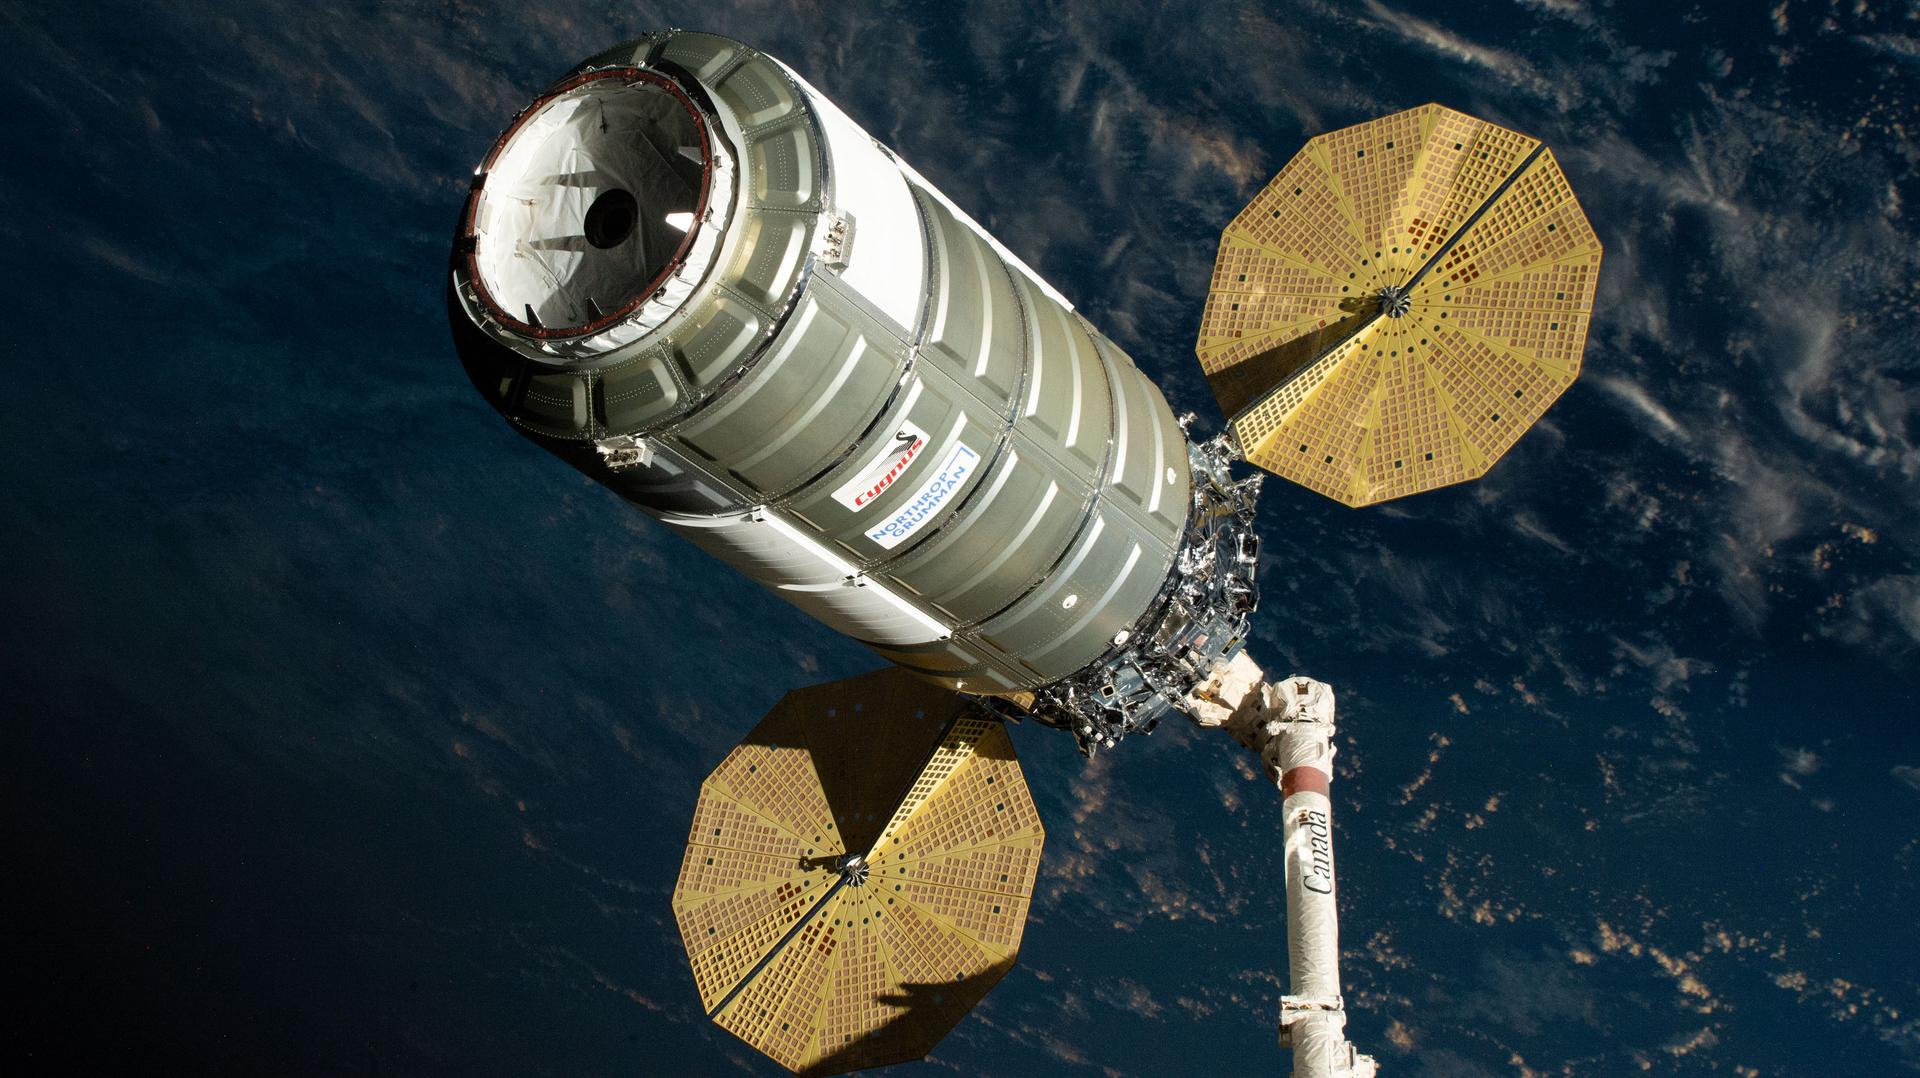
iss074e0459132 (April 13, 2026) --- Northrop Grumman's Cygnus XL cargo spacecraft is held in the grips of the Canadarm2 robotic arm as it is maneuvered toward the International Space Station’s Unity module for installation. Cygnus XL delivered more than 11,000 pounds of new science experiments, lab hardware, and crew supplies for the Expedition 74 crew. Credit: NASA/Jessica Meir
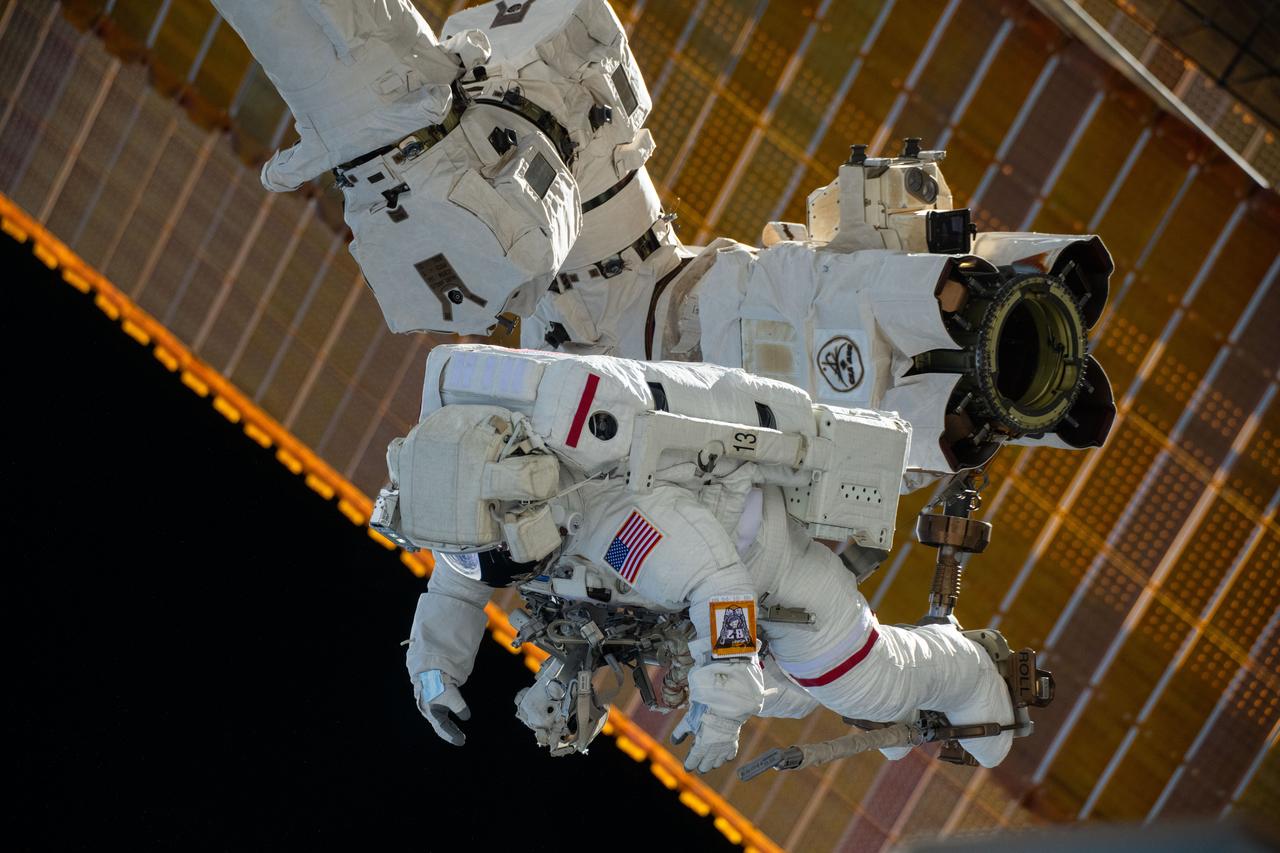
iss072e595491 (Jan. 30, 2025) --- NASA astronaut and Expedition 72 Commander Suni Williams is attached to the Canadarm2 robotic arm's latching end effector while being maneuvered to her worksite 264 miles above the South Pacific Ocean. Williams removed and stowed a radio frequency group antenna assembly during the five-hour and 26-minute spacewalk outside the International Space Station.

iss072e595496 (Jan. 30, 2025) --- NASA astronaut and Expedition 72 Commander Suni Williams is attached to the Canadarm2 robotic arm's latching end effector while being maneuvered to her worksite 264 miles above the South Pacific Ocean. Williams removed and stowed a radio frequency group antenna assembly during the five-hour and 26-minute spacewalk outside the International Space Station.
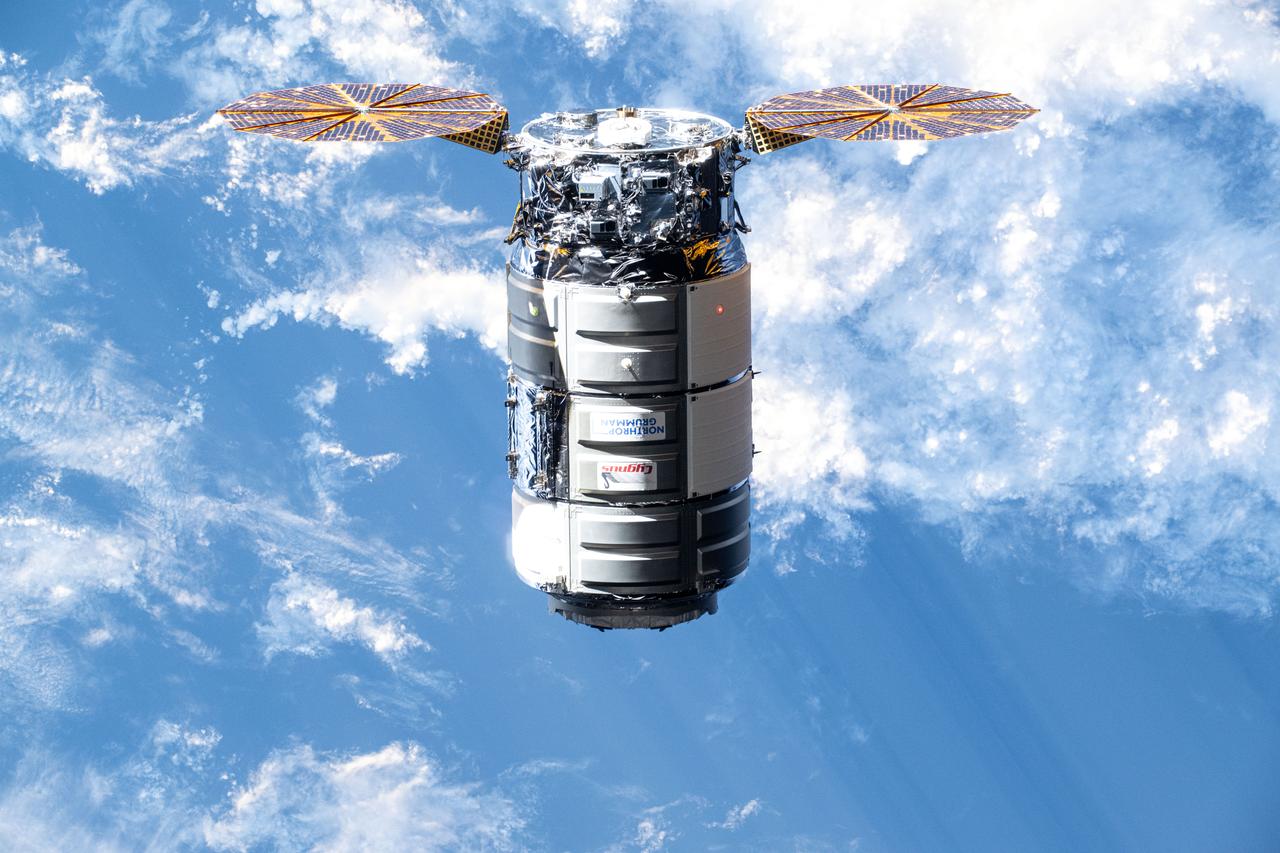
iss071e416851 (Aug. 6, 2024) --- Northrop Grumman's Cygnus cargo craft, carrying 8,200 pounds of science and supplies, approaches the International Space Station for a capture with the Canadarm2 robotic arm commanded by Expedition 71 Flight Engineer Matthew Dominick of NASA. The maneuver marked the 50th free-flying capture for the Canadarm2 robotic arm.
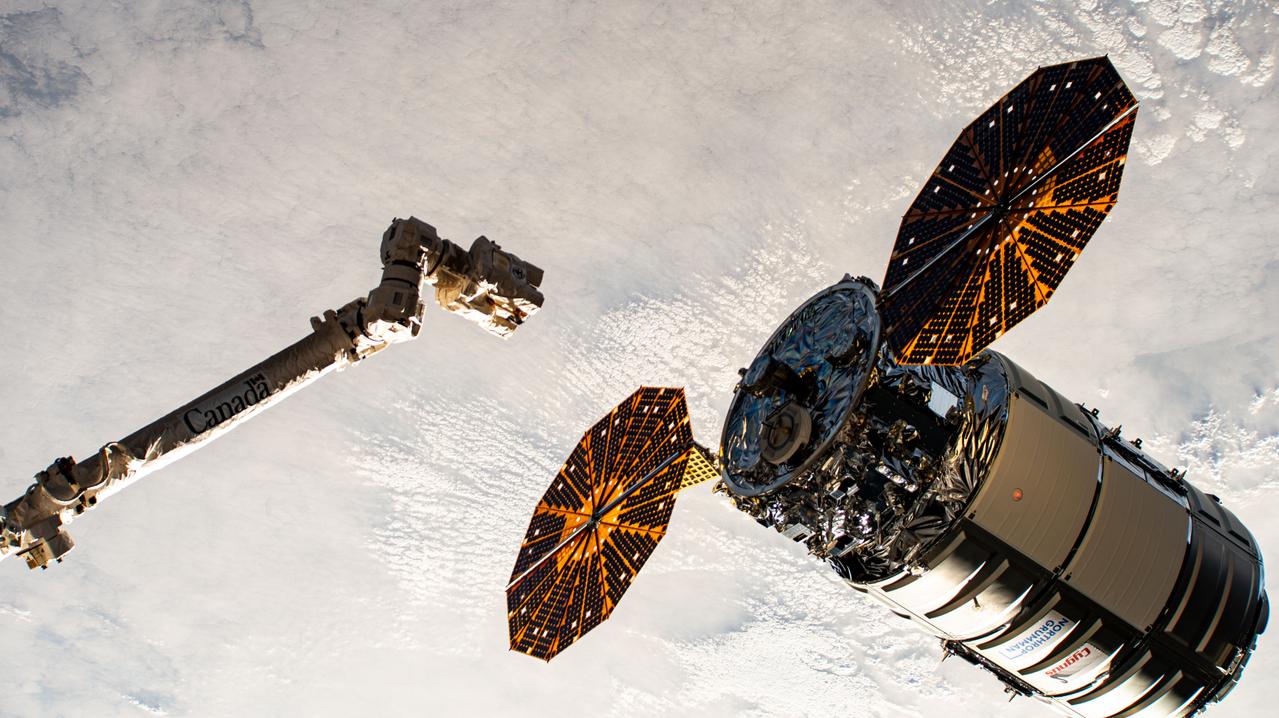
iss071e418233 (Aug. 6, 2024) --- Northrop Grumman's Cygnus cargo craft, with its prominent cymbal-shaped UltraFlex solar arrays, is pictured awaiting its capture by the Canadarm2 robotic arm commanded by Expedition 71 Flight Engineer Matthew Dominick of NASA. The maneuver marked the 50th free-flying capture for the Canadarm2 robotic arm.
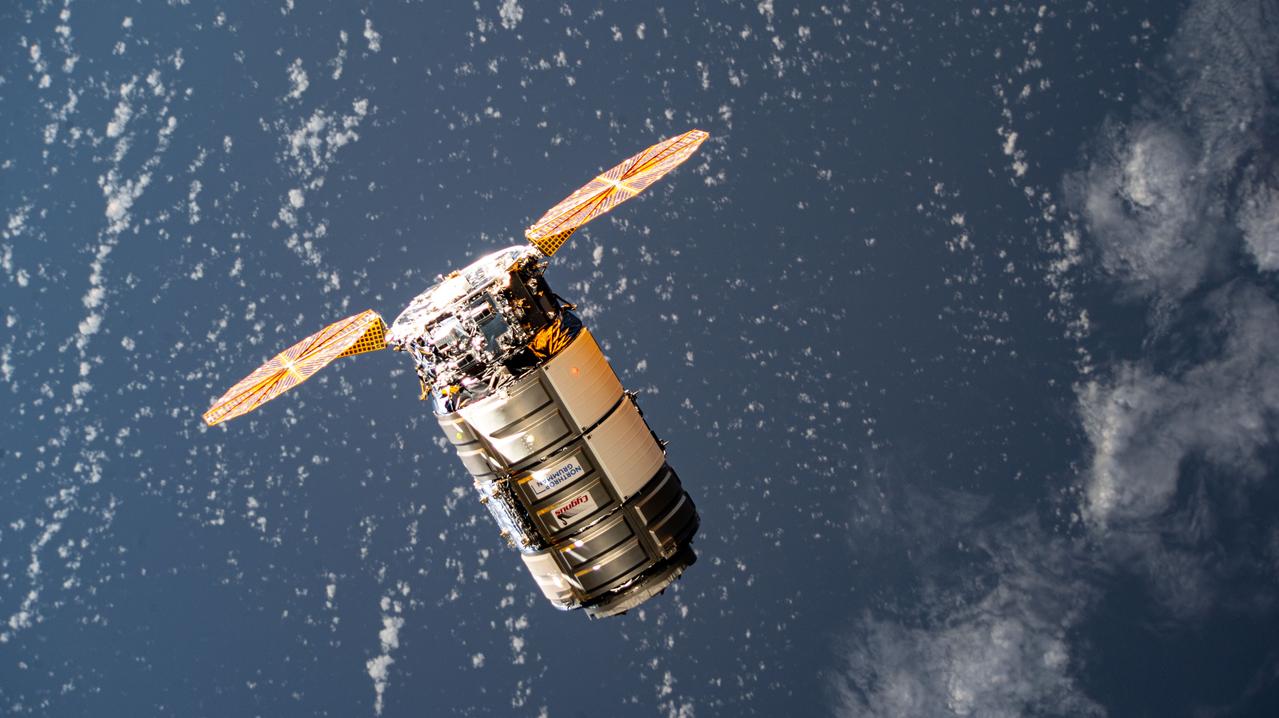
iss071e418230 (Aug. 6, 2024) --- Northrop Grumman's Cygnus cargo craft, carrying 8,200 pounds of science and supplies, approaches the International Space Station for a capture with the Canadarm2 robotic arm commanded by Expedition 71 Flight Engineer Matthew Dominick of NASA. The maneuver marked the 50th free-flying capture for the Canadarm2 robotic arm.
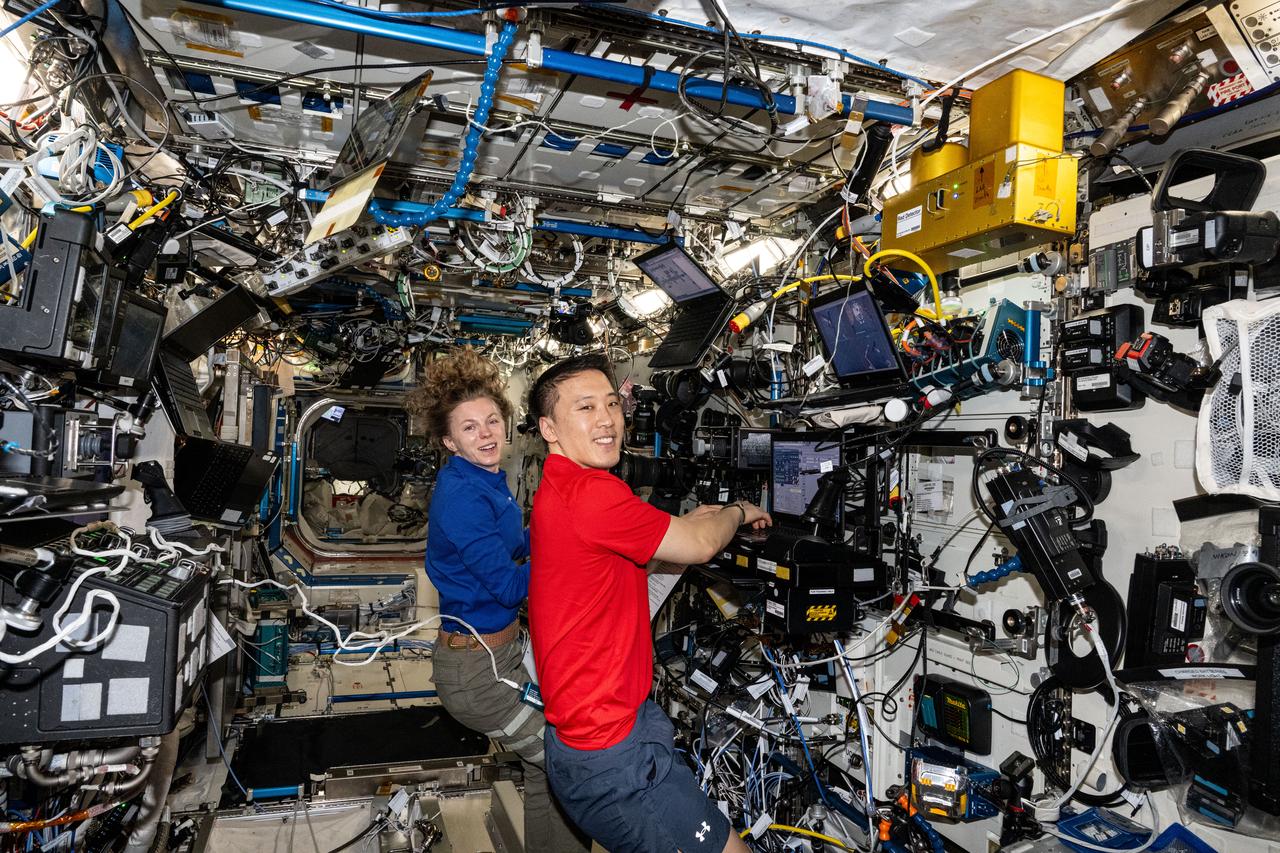
iss073e0702302 (Sept. 16, 2025) --- NASA astronauts Zena Cardman and Jonny Kim, both Expedition 73 flight engineers, practice Canadarm2 robotic arm maneuvers on the Destiny laboratory module's robotics workstation. Kim commanded the Canadarm2 two days later to capture Northrop Grumman's Cygnus XL cargo craft with Cardman backing him up as the spacecraft arrived at the International Space Station.
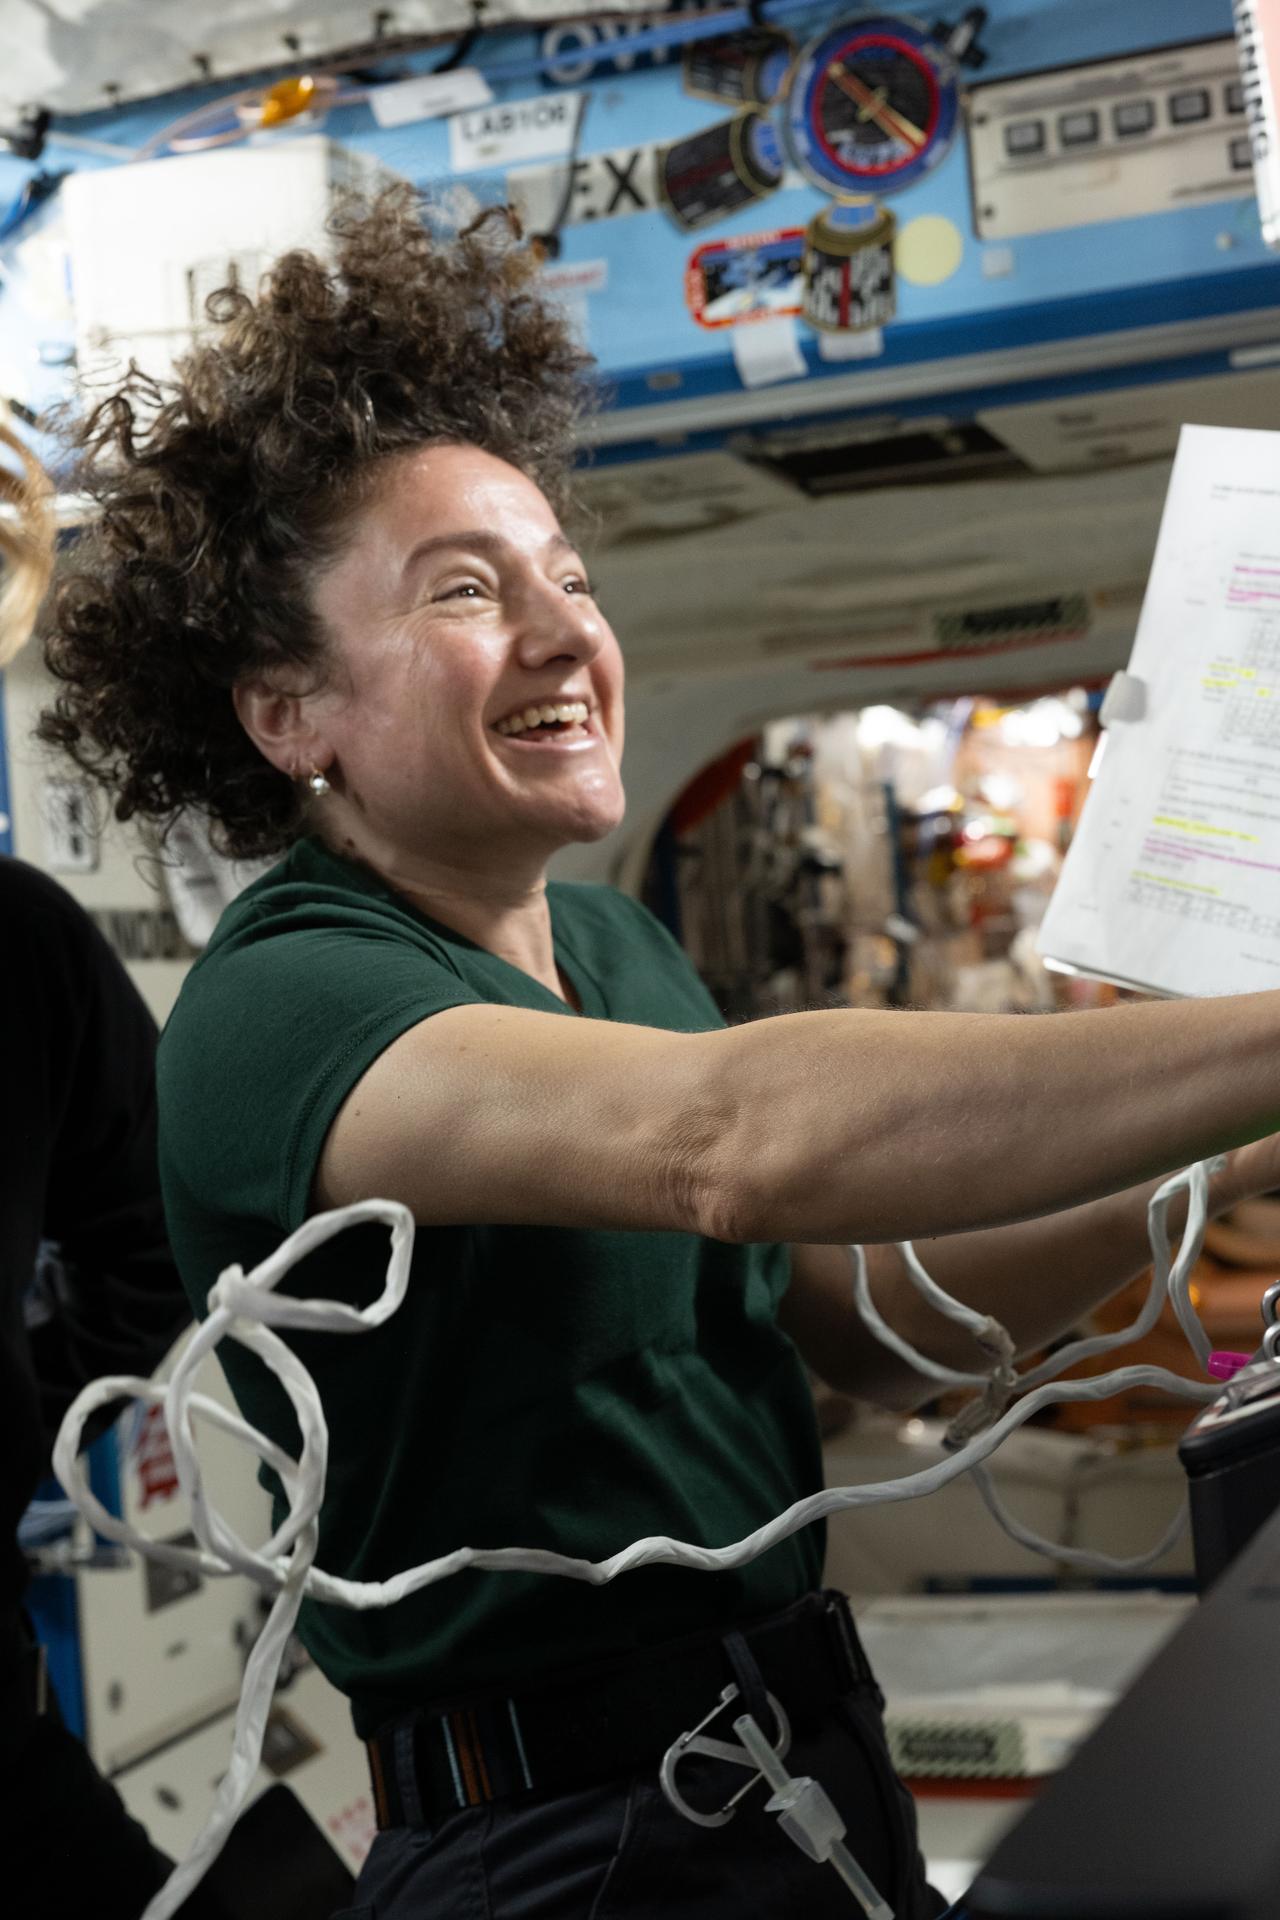
iss075e0039589 (Aug. 17, 2026) --- Expedition 75 commander Jessica Meir smiles during a light moment while studying Canadarm2 robotic arm procedures to support spacewalk operations to replace a space‑to‑ground antenna outside the International Space Station. Credit: NASA/Anil Menon
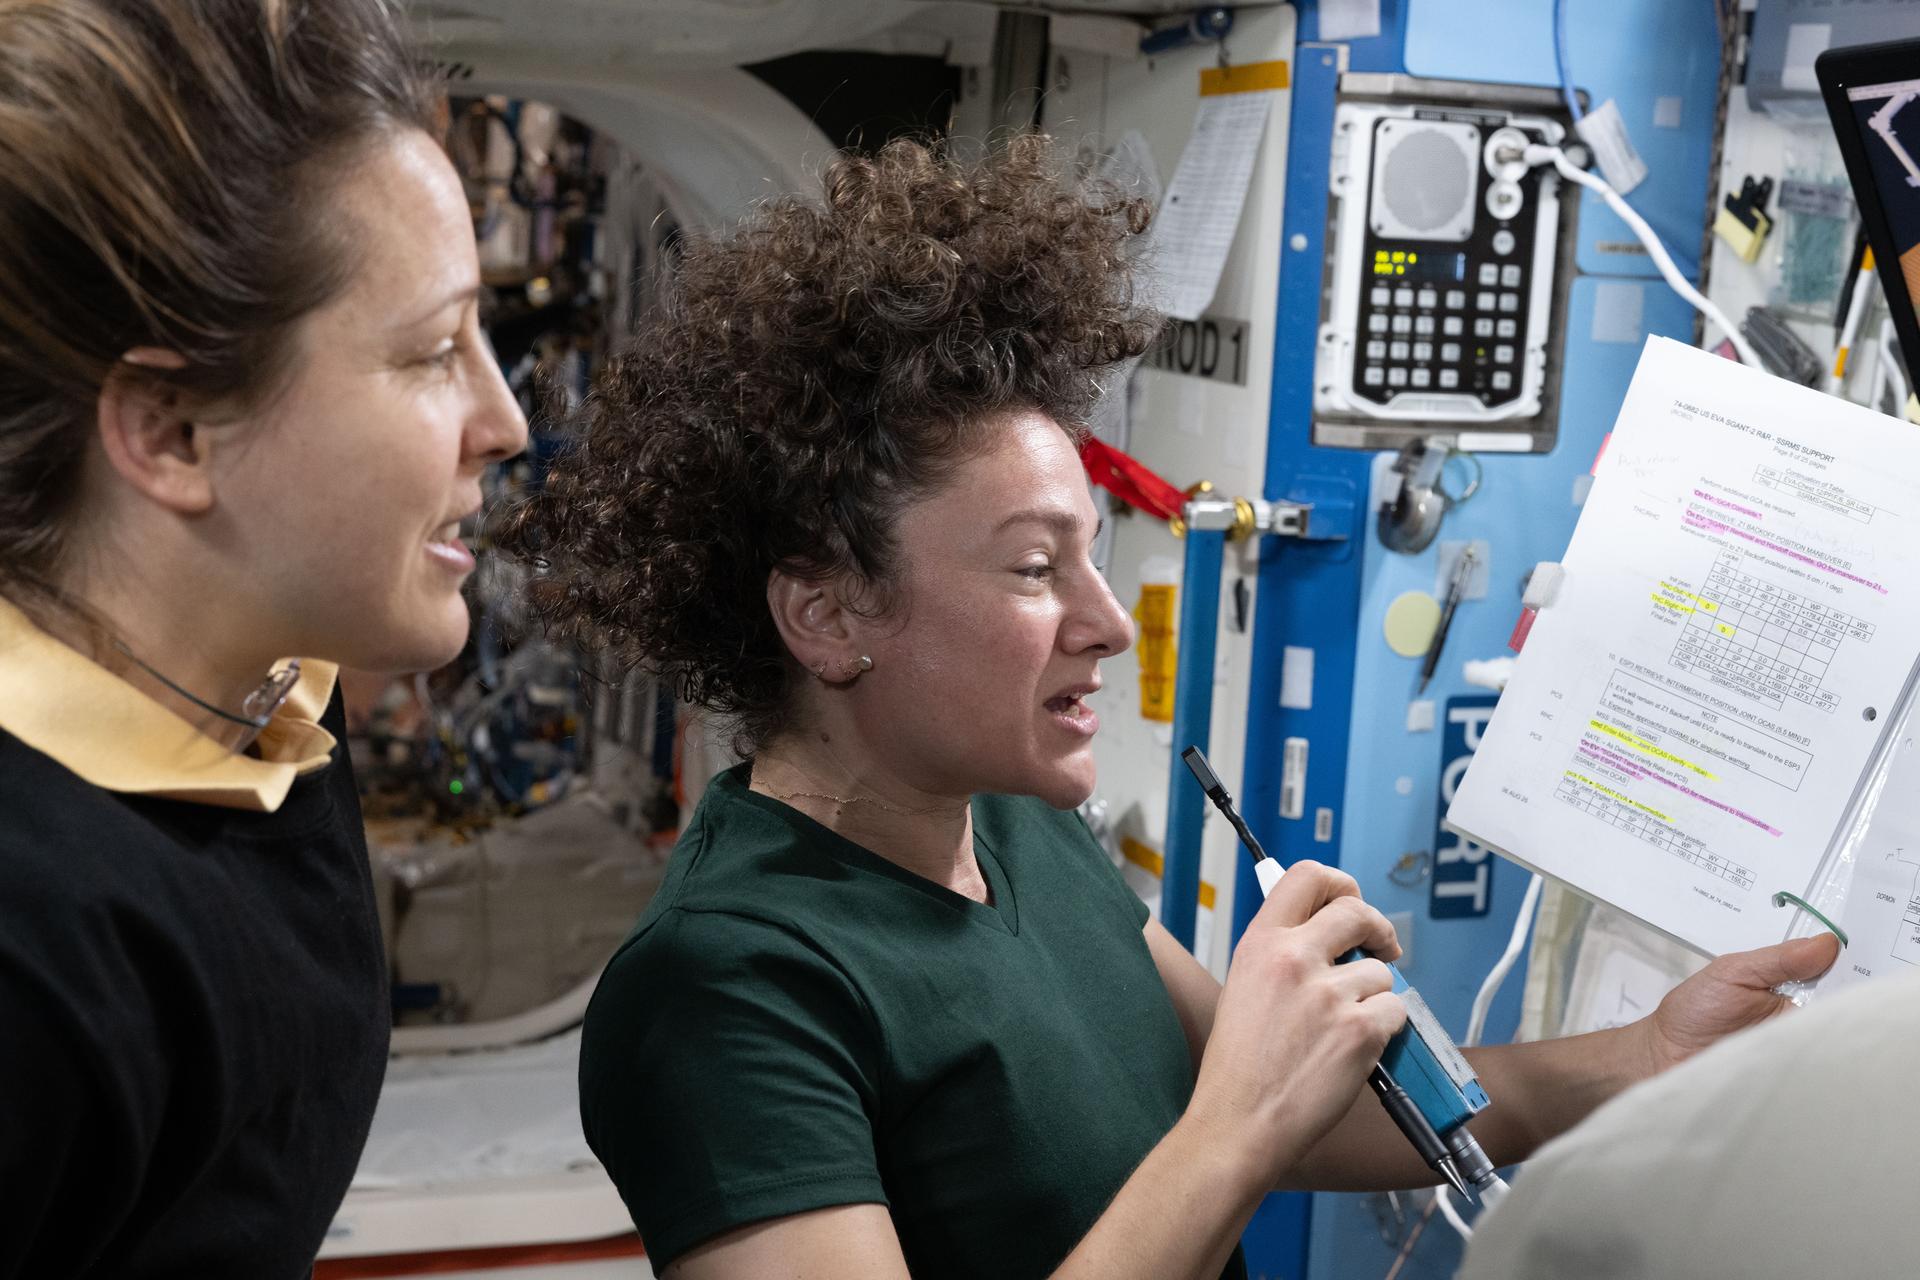
iss075e0039586 (Aug. 17, 2026) --- From left, Expedition 75 flight engineer Sophie Adenot of ESA (European Space Agency) and commander Jessica Meir of NASA study Canadarm2 robotic arm procedures to support spacewalk operations to replace a space‑to‑ground antenna outside the International Space Station. Credit: NASA/Anil Menon
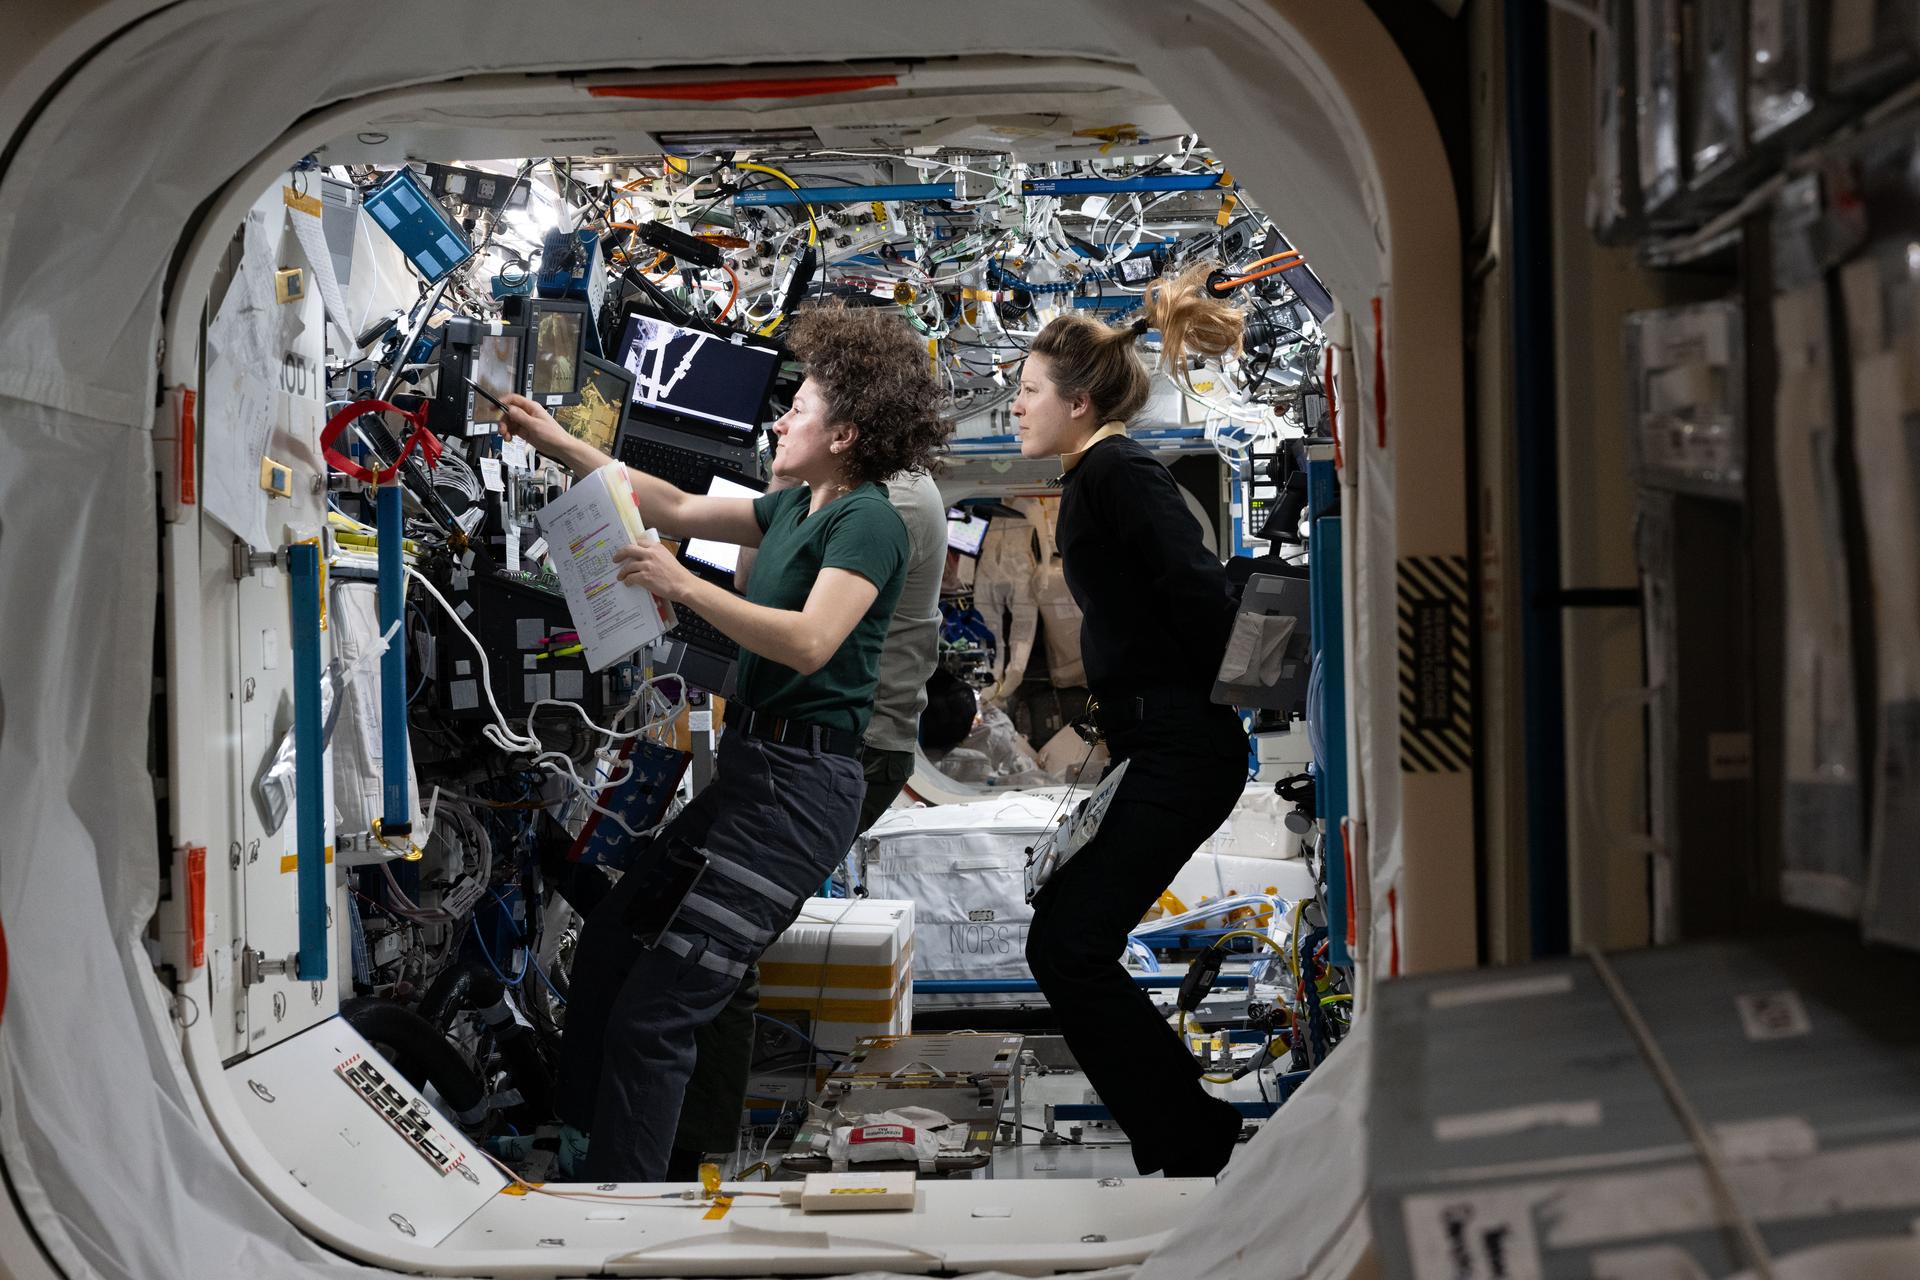
iss075e0039605 (Aug. 17, 2026) --- Expedition 75 commander Jessica Meir of NASA and flight engineer Sophie Adenot of ESA (European Space Agency) study Canadarm2 robotic arm procedures to support spacewalk operations to replace a space‑to‑ground antenna outside the International Space Station. Credit: NASA/Anil Menon
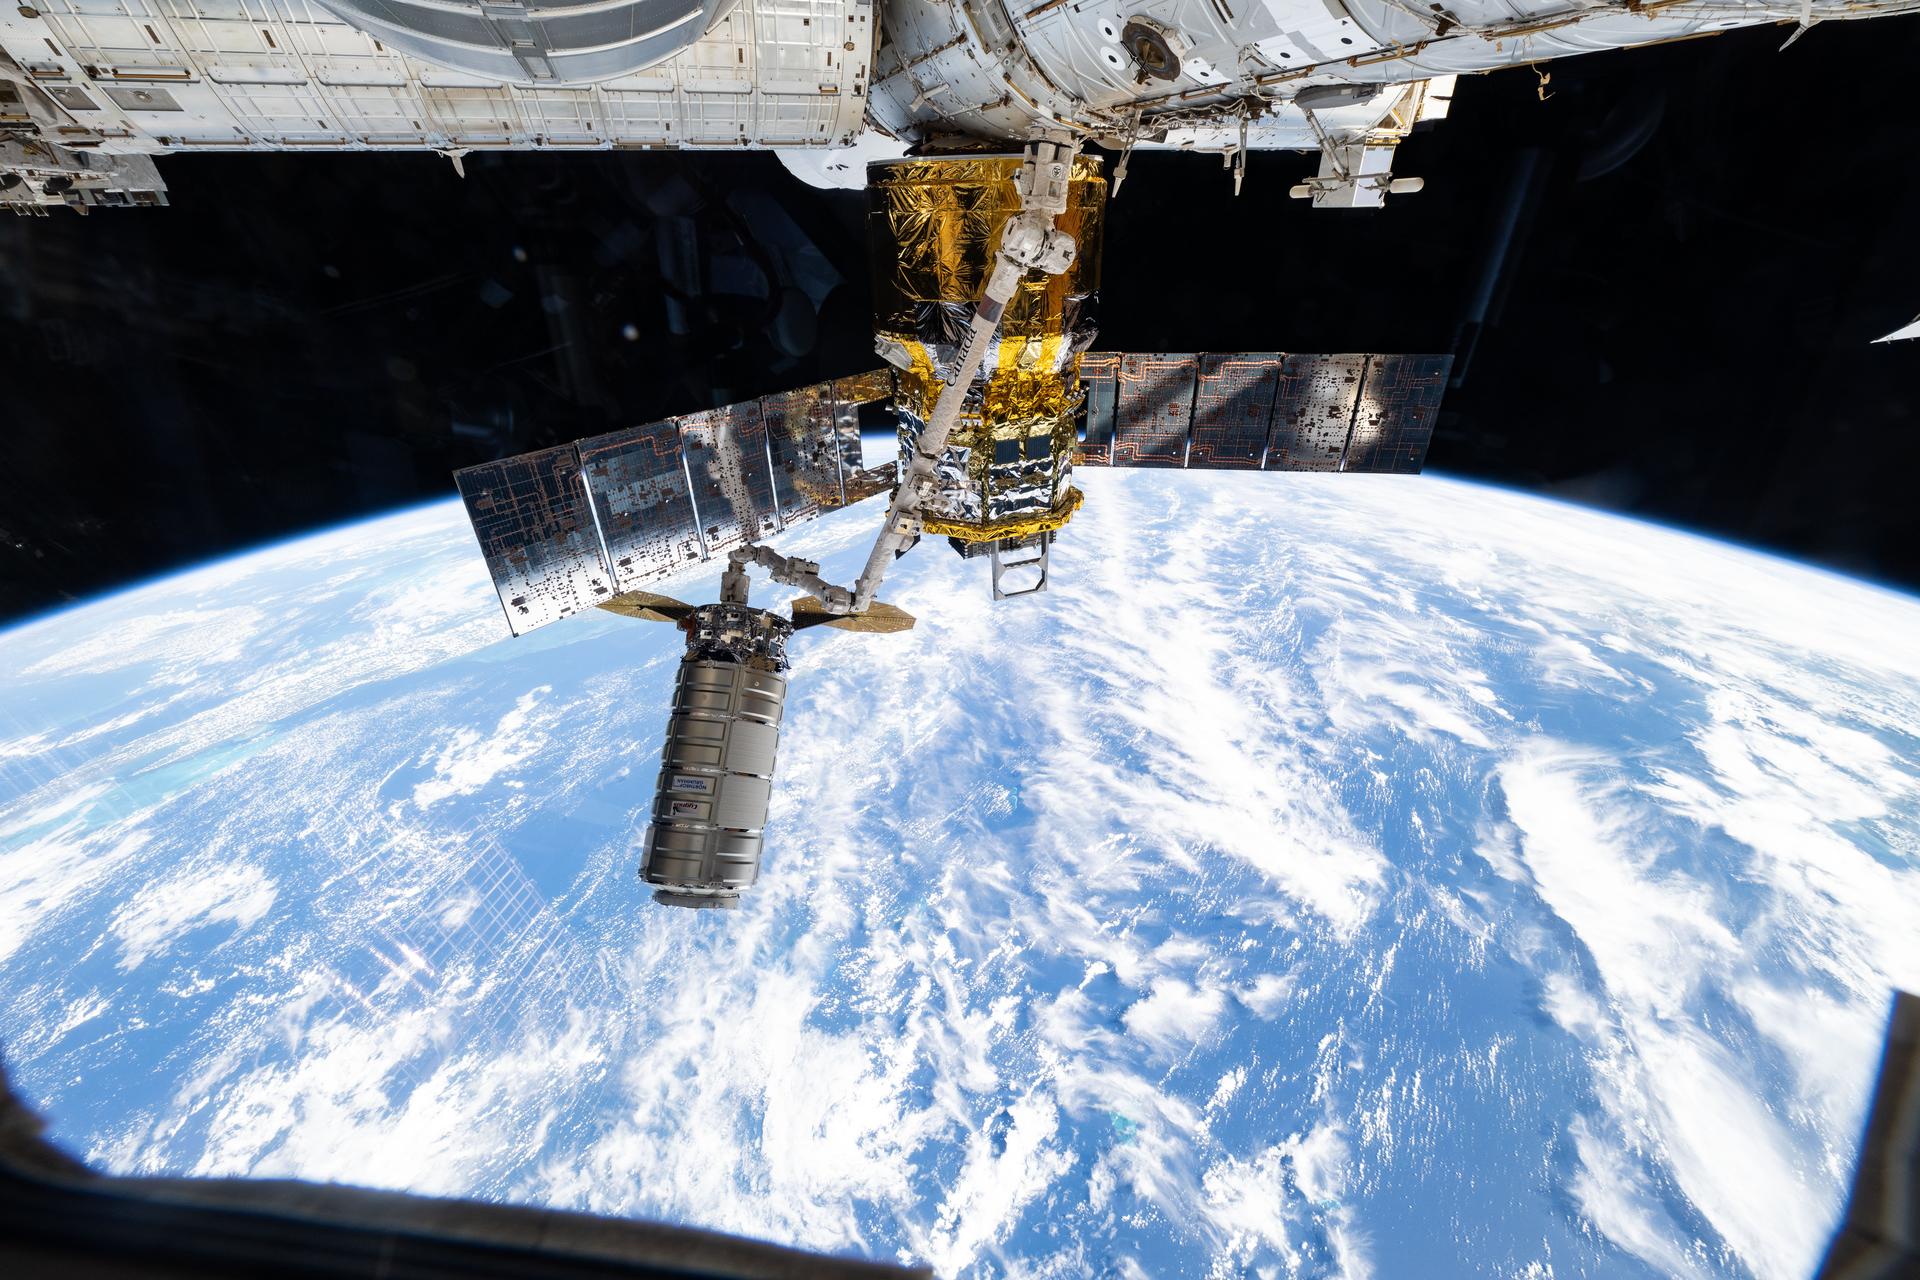
iss073e1196882 (Nov. 25, 2025) --- Northrop Grumman's Cygnus XL cargo craft is pictured in the grips of the International Space Station Canadarm2 robotic arm. Cygnus XL had been temporarily released from its Earth-facing port on the Unity module to make room for the Soyuz MS-28 crew spacecraft, which was scheduled to arrive the next day and dock to the Rassvet module. JAXA's (Japan Aerospace Exploration Agency) HTV-X1 cargo craft, with its solar arrays deployed, is seen berthed to the Earth-facing port of the Harmony module. The orbital outpost was soaring 262 miles above the Caribbean Sea east of the Yucatan Peninsula.
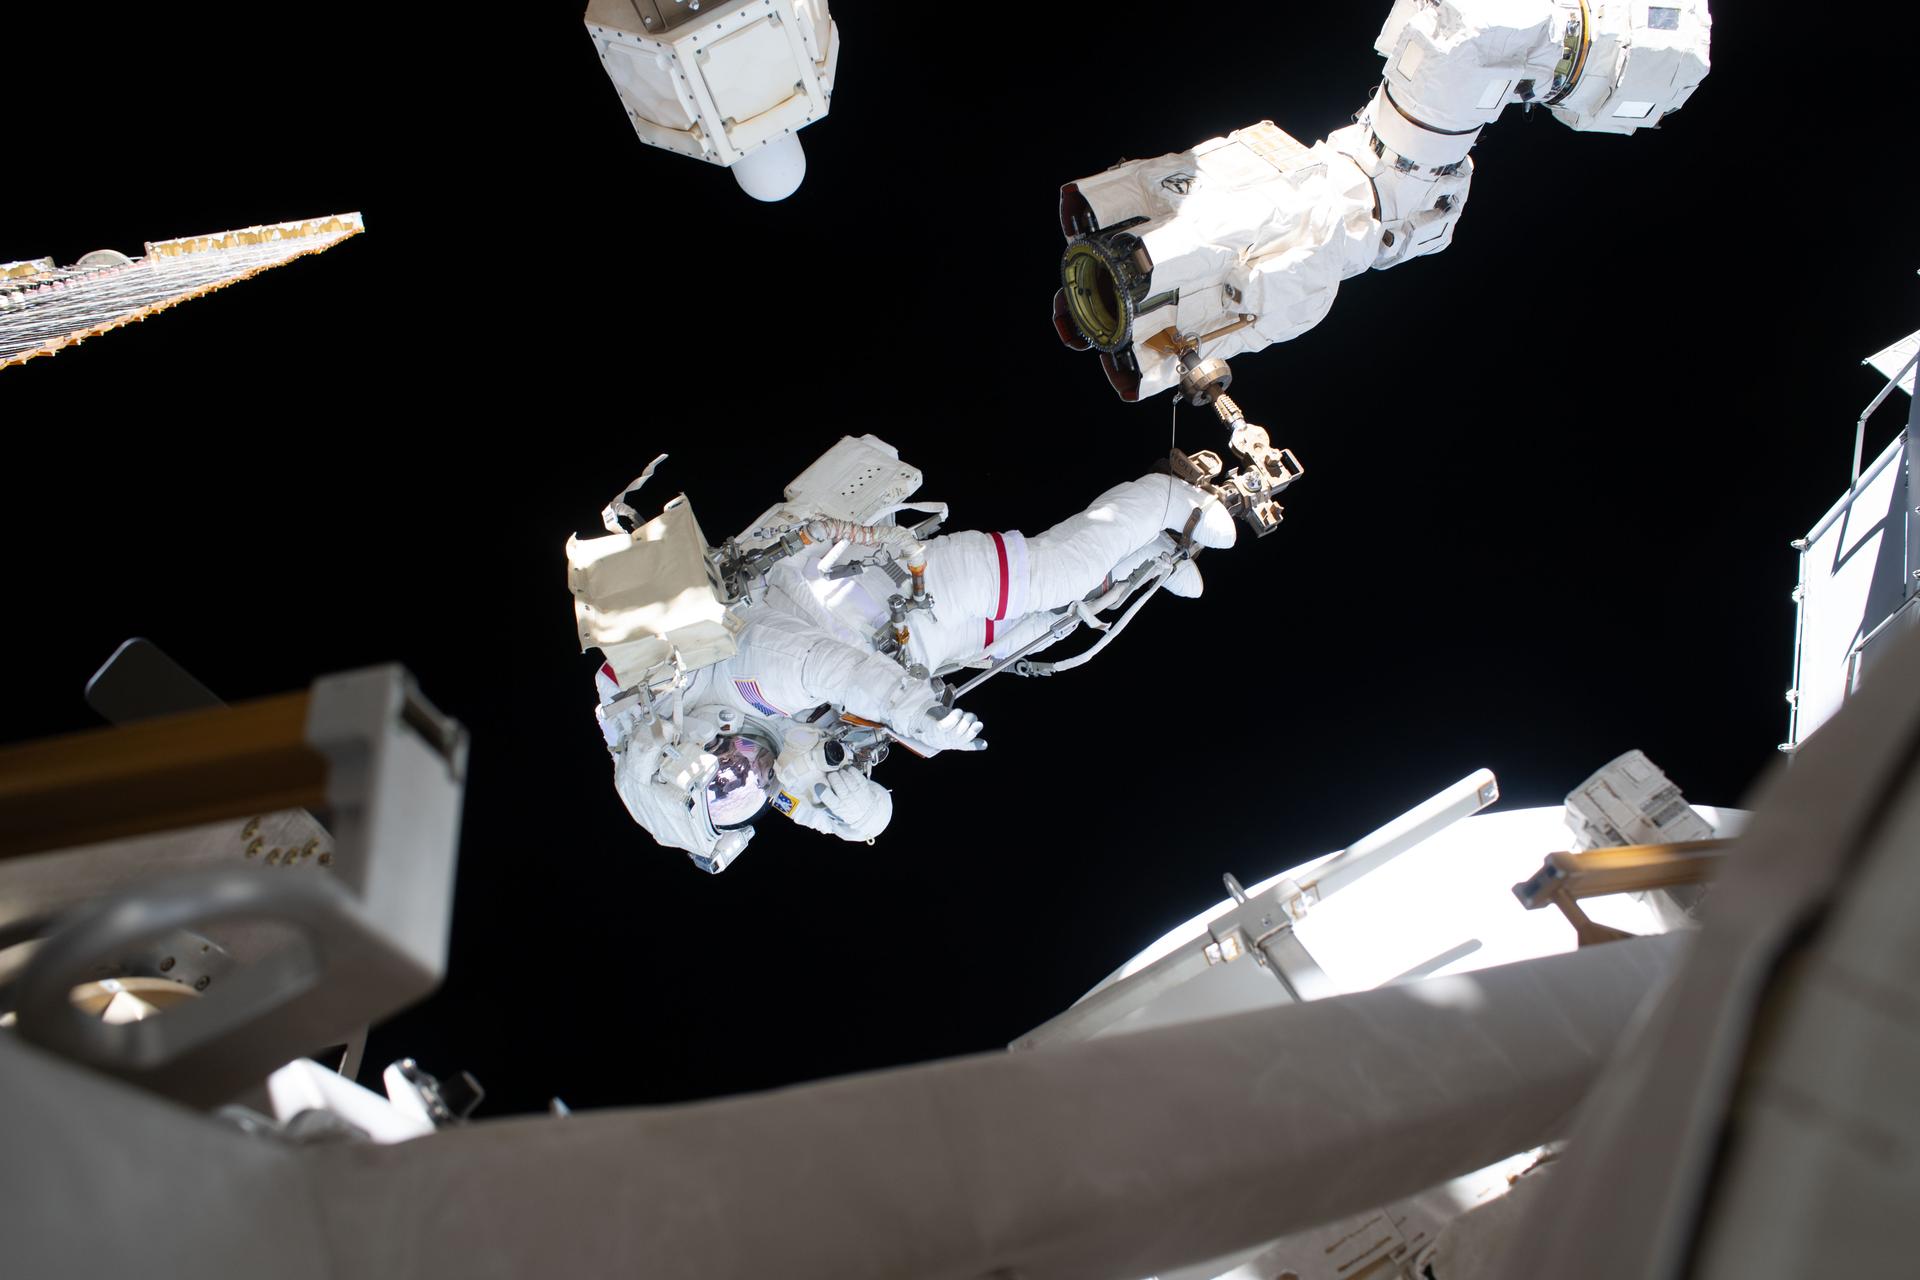
iss075e0070083 (Aug. 25, 2026) --- NASA astronaut and Expedition 75 flight engineer Anil Menon is attached to the Canadarm2 robotic arm’s latching end effector during a spacewalk to install a high-speed space-to-ground antenna on the International Space Station’s Z1 truss segment above the Unity module. Menon and ESA (European Space Agency) astronaut and Expedition 75 flight engineer Sophie Adenot (out of frame) spent six hours and 30 minutes replacing a failed antenna with a spare and making the precise connections needed to activate it for high-speed transmissions with mission control. Credit: NASA
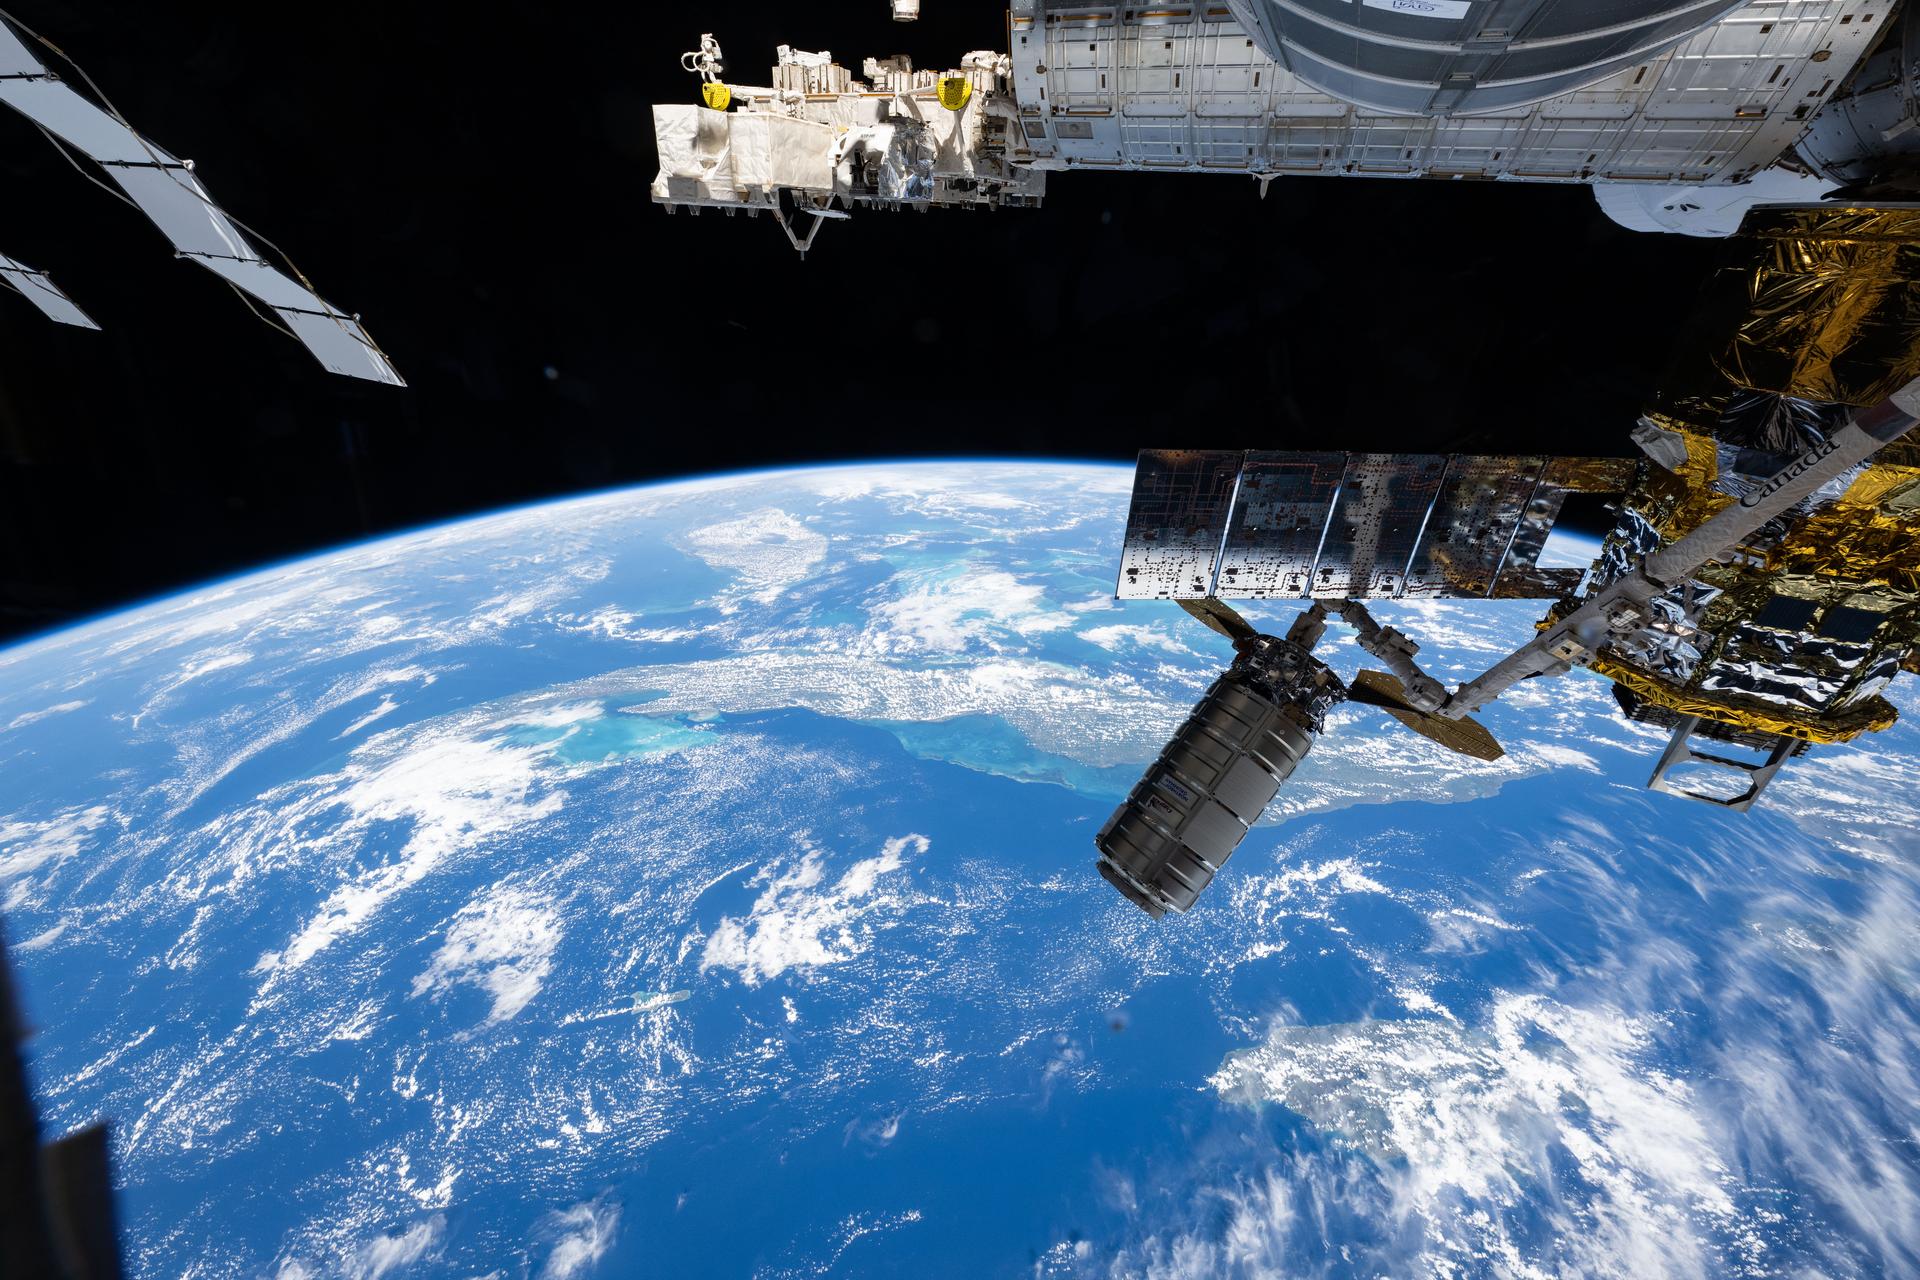
iss073e1196921 (Nov. 25, 2025) --- Northrop Grumman's Cygnus XL cargo craft is pictured in the grips of the International Space Station Canadarm2 robotic arm. Cygnus XL had been temporarily released from its Earth-facing port on the Unity module to make room for the Soyuz MS-28 crew spacecraft, which was scheduled to arrive the next day and dock to the Rassvet module. JAXA's (Japan Aerospace Exploration Agency) HTV-X1 cargo craft, with its solar arrays deployed, is seen berthed to the Earth-facing port of the Harmony module. The orbital outpost was soaring 262 miles above the Caribbean Sea south of Cuba at the time of this photograph.
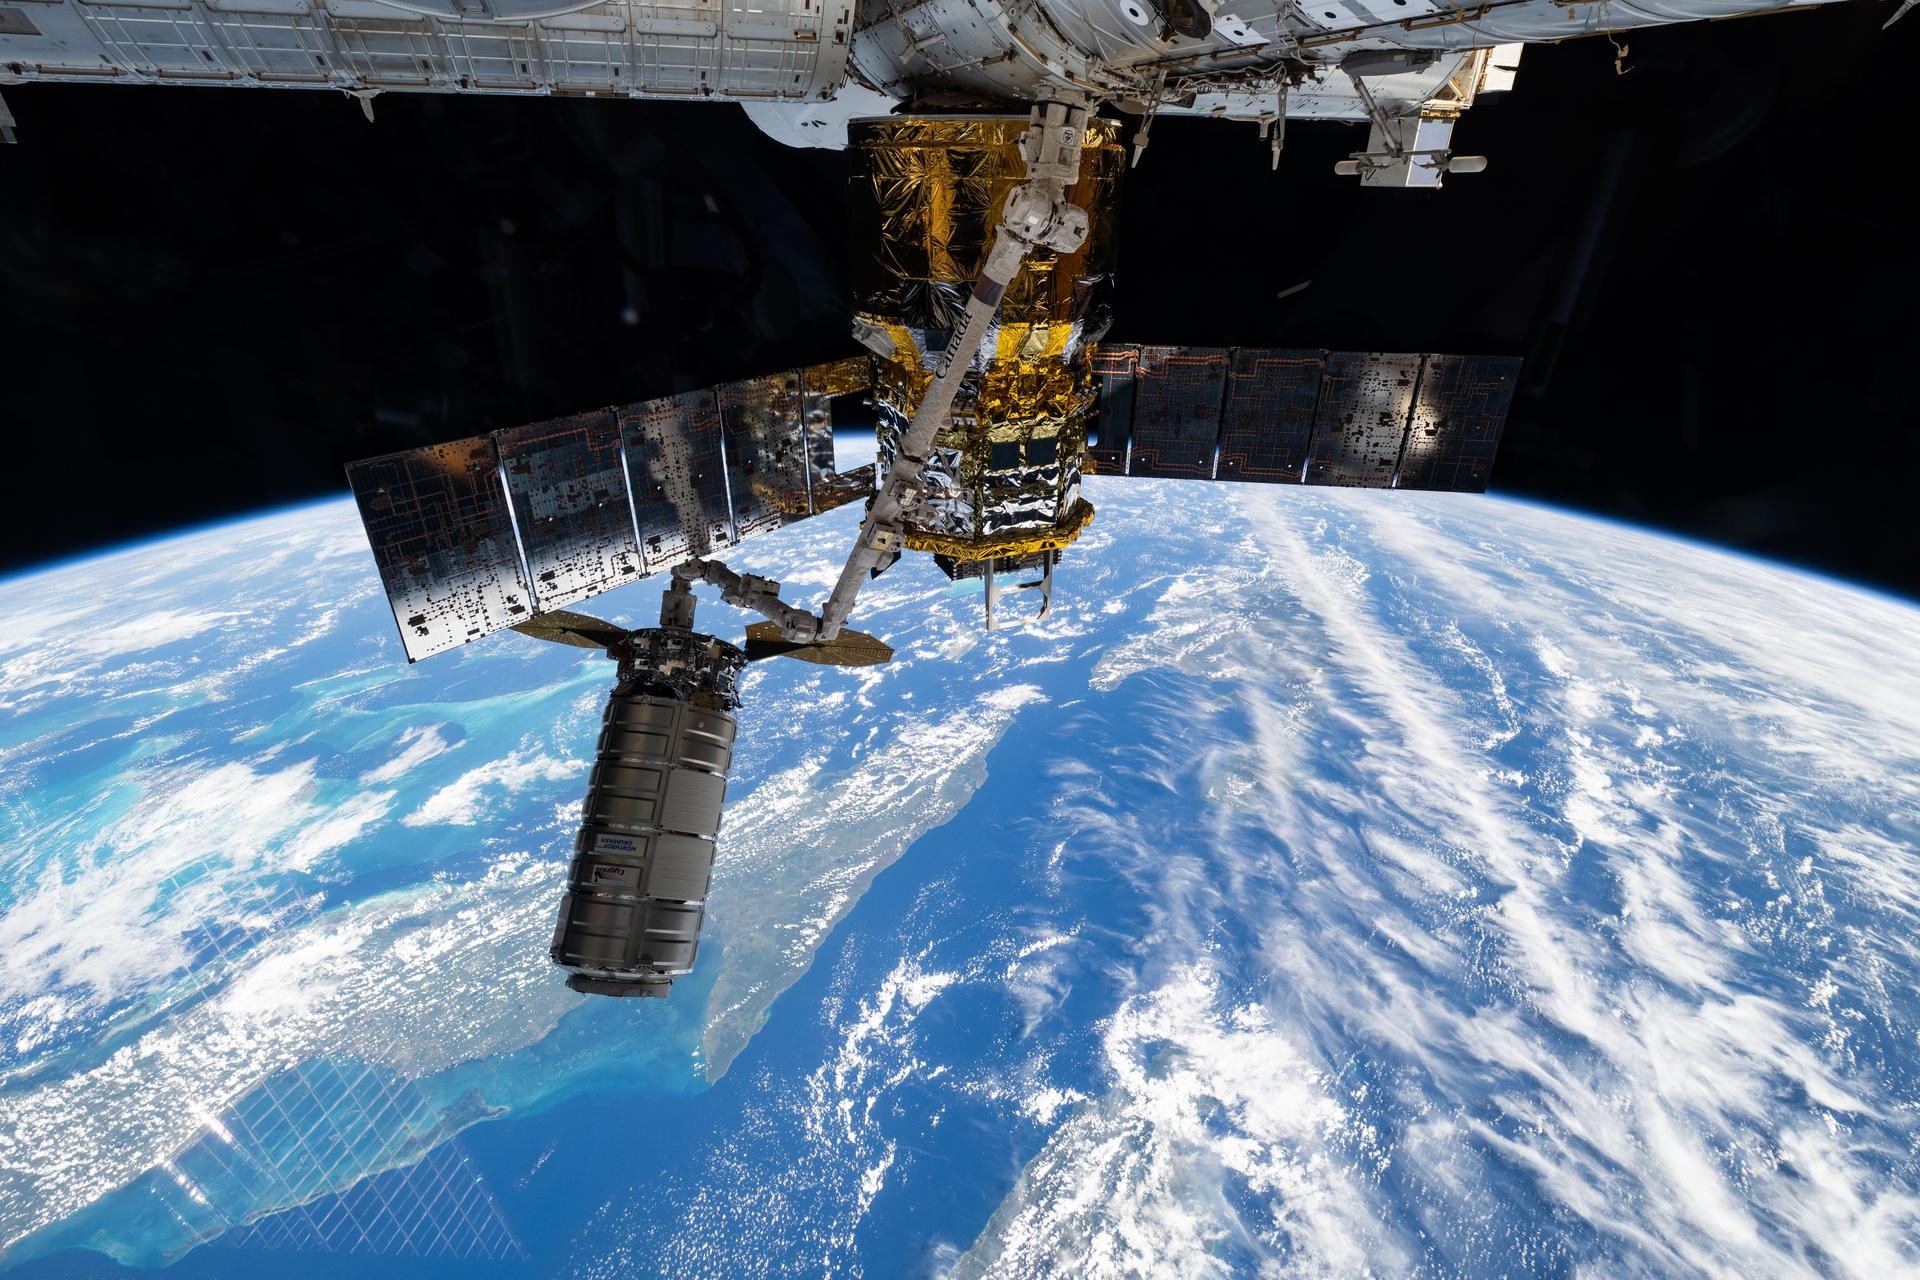
iss073e1196940 (Nov. 25, 2025) --- Northrop Grumman's Cygnus XL cargo craft is pictured in the grips of the International Space Station Canadarm2 robotic arm. Cygnus XL had been temporarily released from its Earth-facing port on the Unity module to make room for the Soyuz MS-28 crew spacecraft, which was scheduled to arrive the next day and dock to the Rassvet module. JAXA's (Japan Aerospace Exploration Agency) HTV-X1 cargo craft, with its solar arrays deployed, is seen berthed to the Earth-facing port of the Harmony module. The orbital outpost was soaring 261 miles above the Caribbean Sea south of Cuba at the time of this photograph.
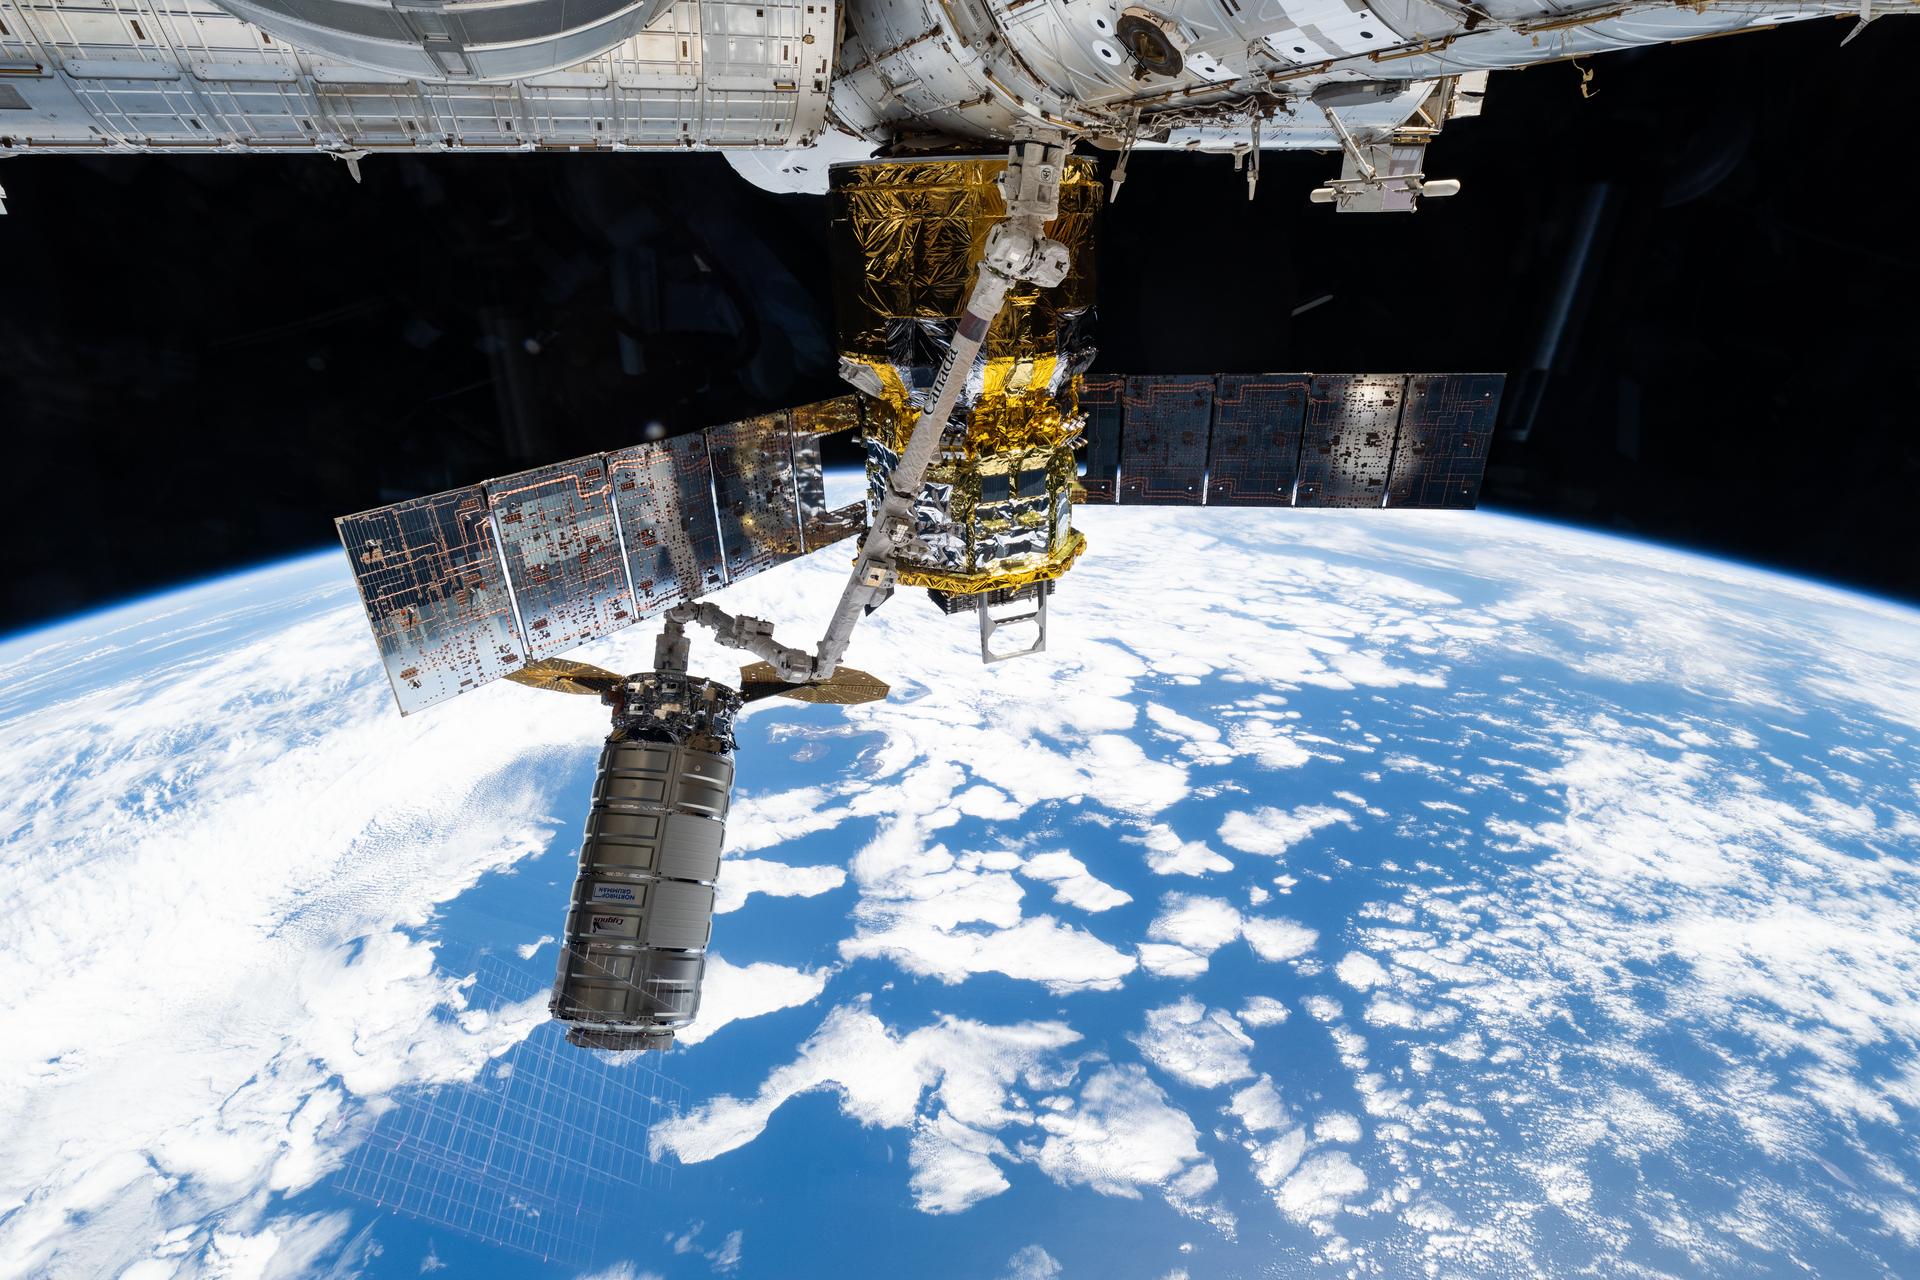
iss073e1196791 (Nov. 25, 2025) --- Northrop Grumman's Cygnus XL cargo craft is pictured in the grips of the International Space Station Canadarm2 robotic arm. Cygnus XL had been temporarily released from its Earth-facing port on the Unity module to make room for the Soyuz MS-28 crew spacecraft, which was scheduled to arrive the next day and dock to the Rassvet module. JAXA's (Japan Aerospace Exploration Agency) HTV-X1 cargo craft, with its solar arrays deployed, is seen berthed to the Earth-facing port of the Harmony module. The orbital outpost was soaring 263 miles above the Pacific Ocean southwest of Galapagos Islands at the time of this photograph.
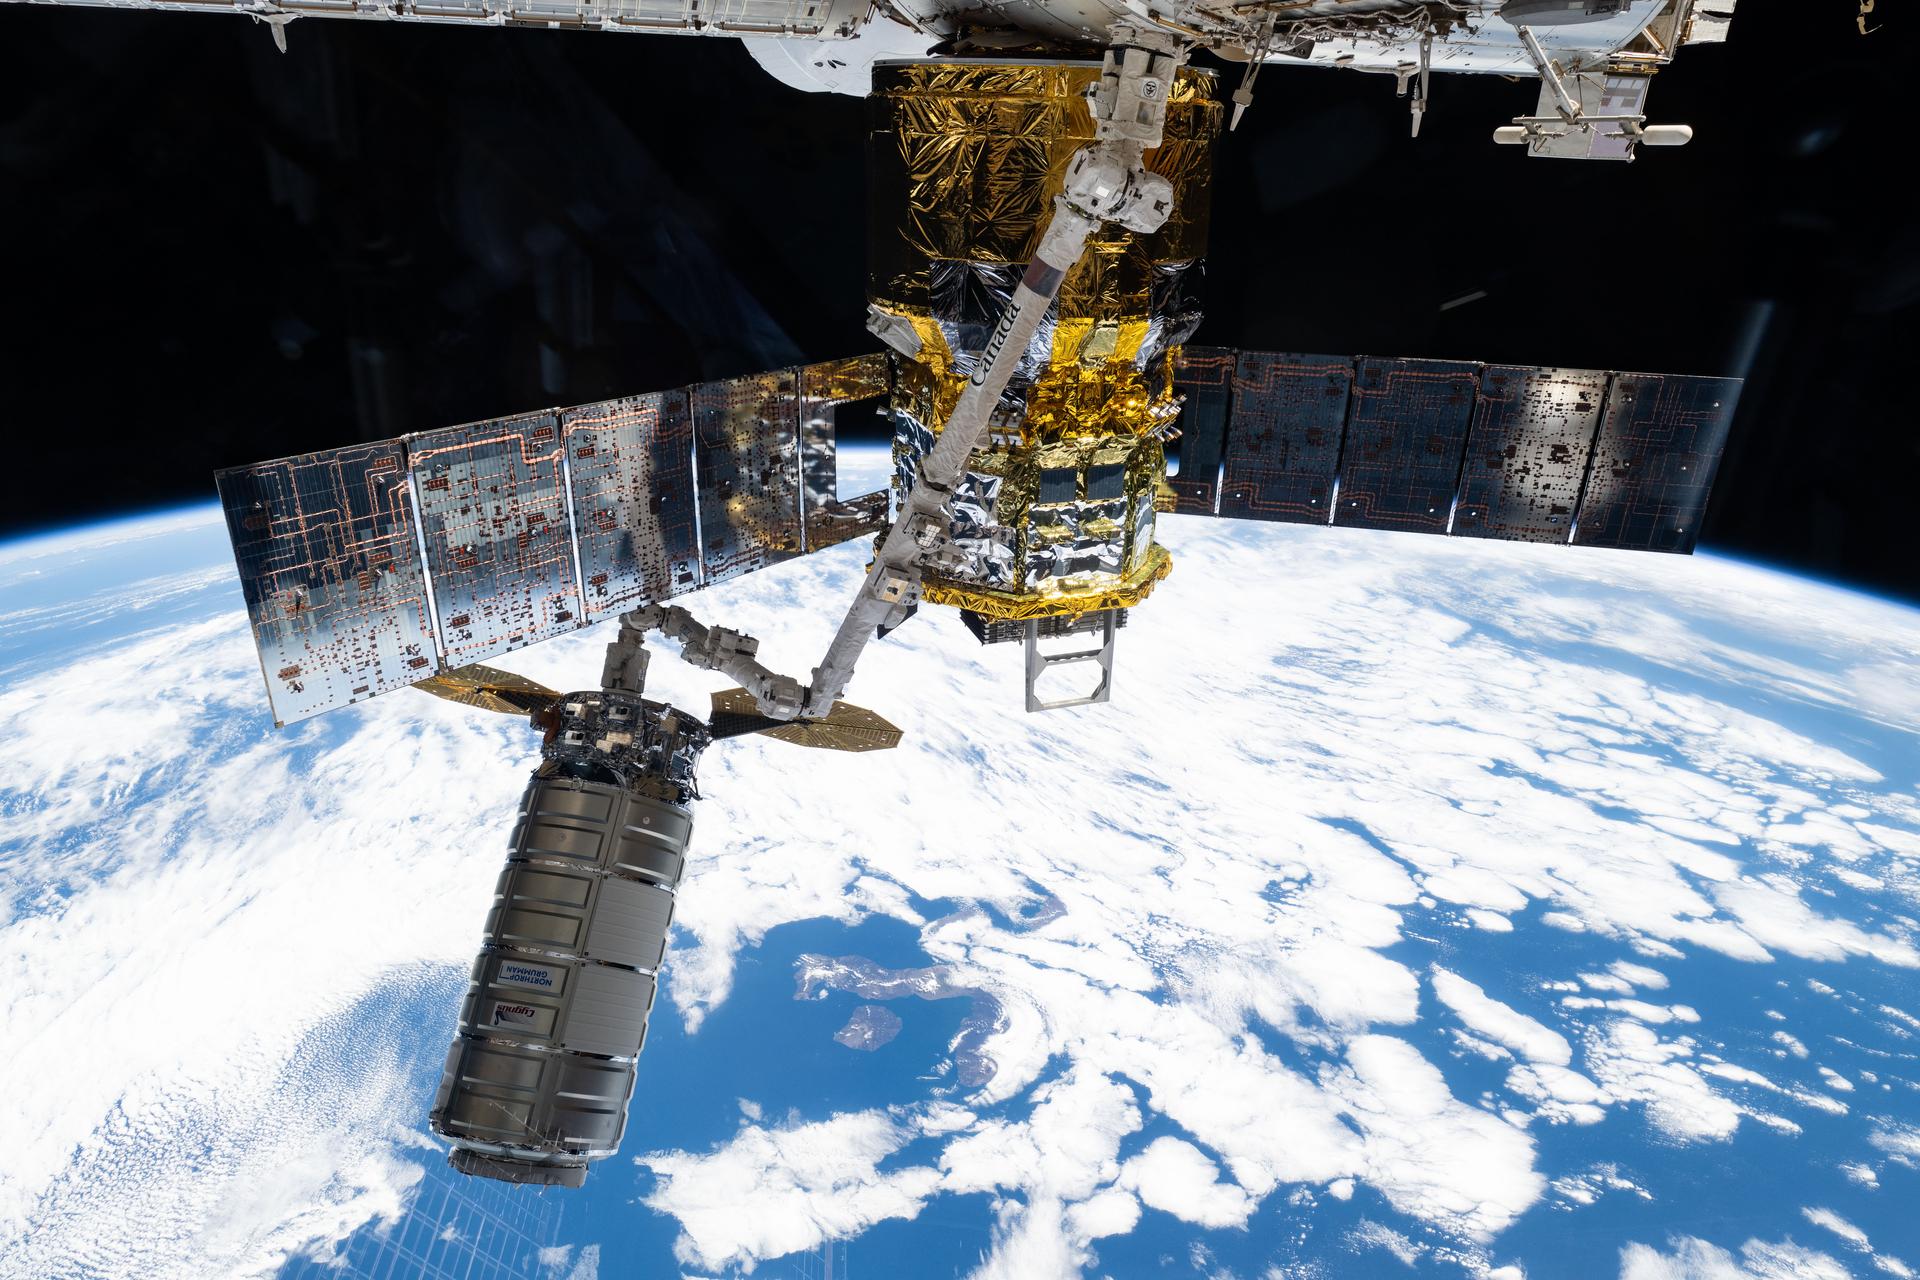
iss073e1196807 (Nov. 25, 2025) --- Northrop Grumman's Cygnus XL cargo craft is pictured in the grips of the International Space Station Canadarm2 robotic arm. Cygnus XL had been temporarily released from its Earth-facing port on the Unity module to make room for the Soyuz MS-28 crew spacecraft, which was scheduled to arrive the next day and dock to the Rassvet module. JAXA's (Japan Aerospace Exploration Agency) HTV-X1 cargo craft, with its solar arrays deployed, is seen berthed to the Earth-facing port of the Harmony module. The orbital outpost was soaring 263 miles above the Pacific Ocean southwest of Galapagos Islands at the time of this photograph.
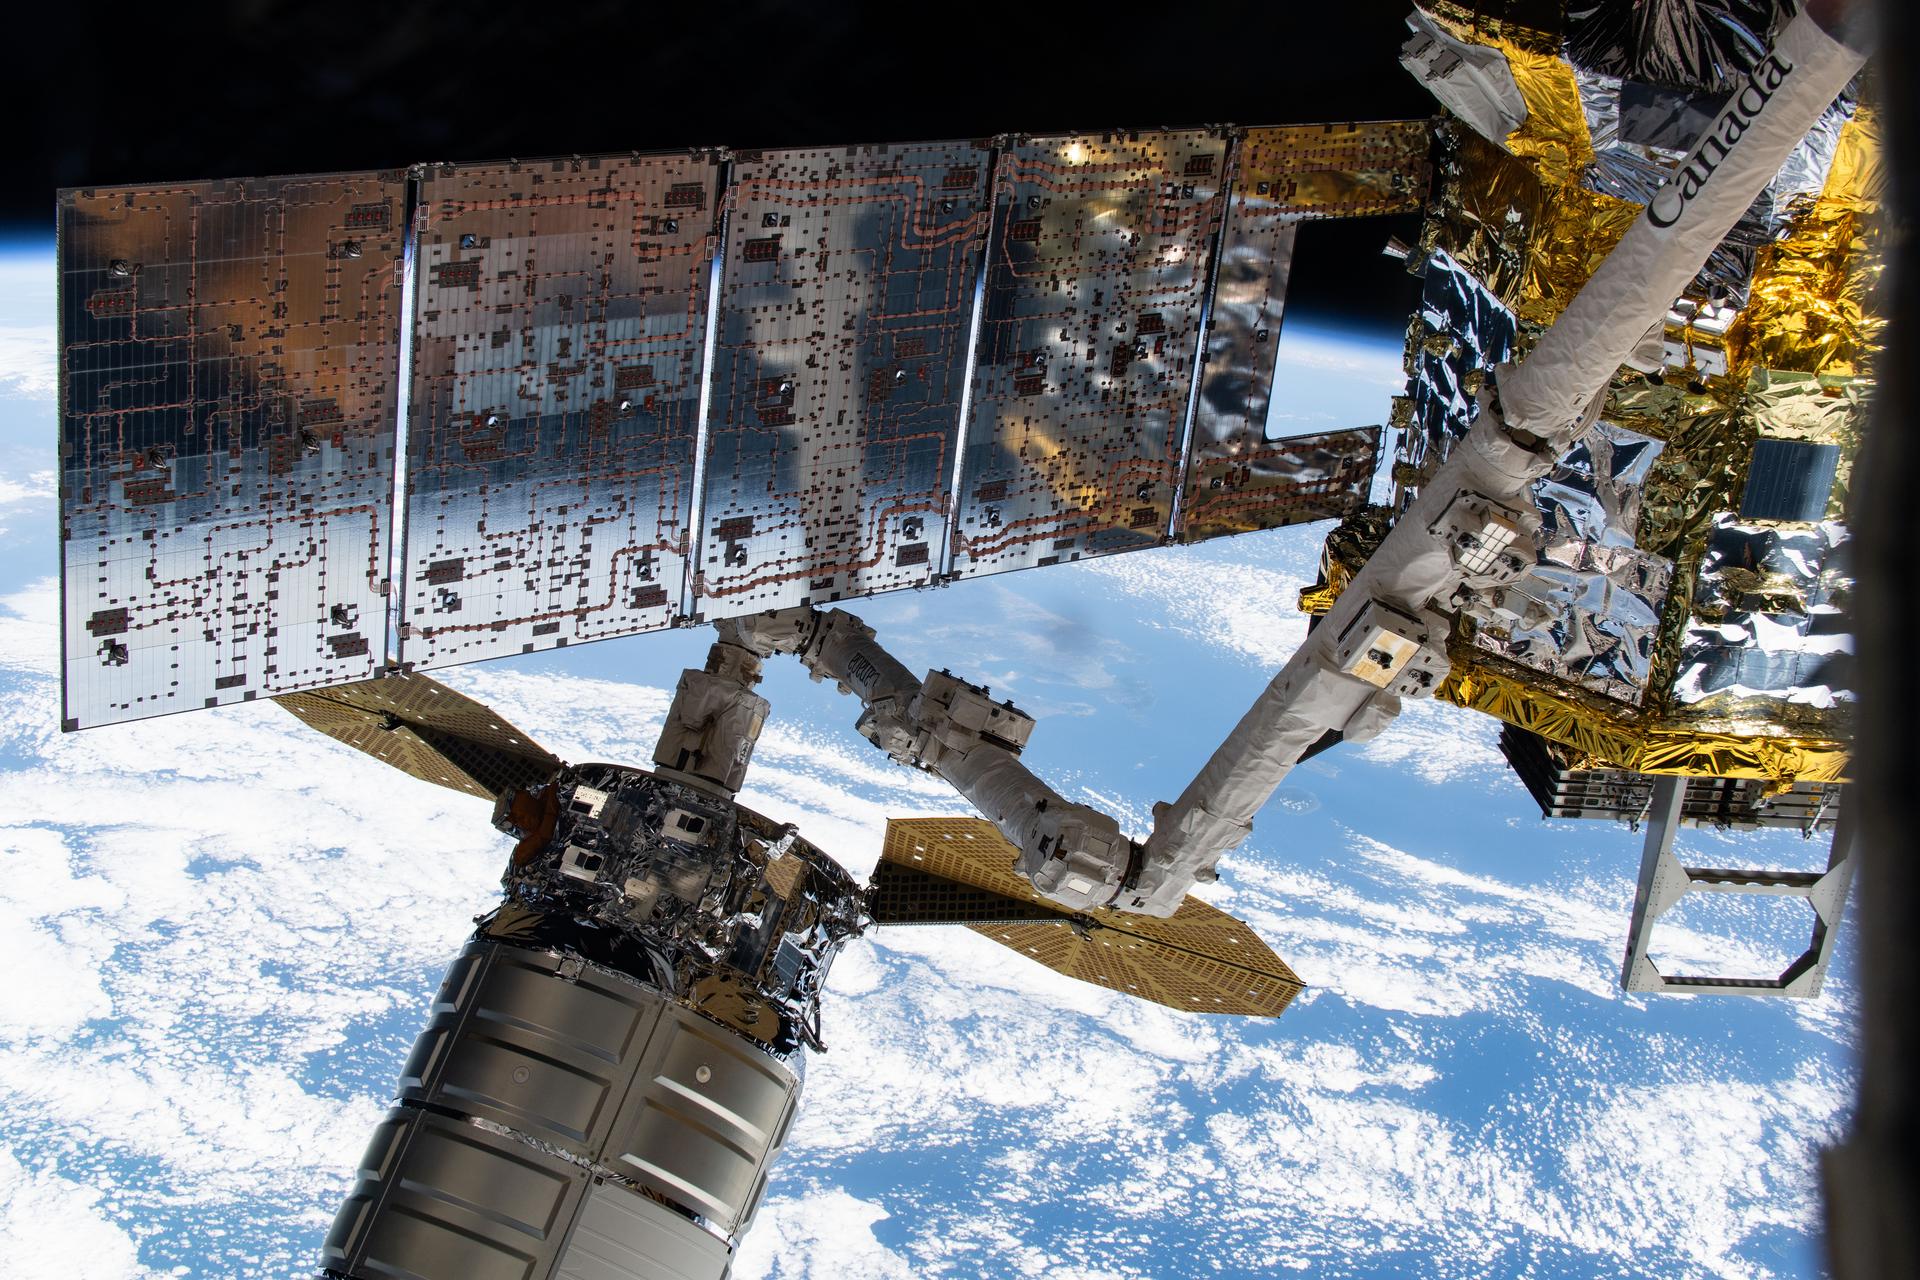
iss073e1197220 (Nov. 26, 2025) --- This close-up view from a window on the International Space Station's cupola shows Northrop Grumman's Cygnus XL cargo craft in the grips of the Canadarm2 robotic arm. Cygnus XL had been temporarily released from its Earth-facing port on the Unity module to make room for the Soyuz MS-28 crew spacecraft, which was scheduled to arrive the next day and dock to the Rassvet module. A solar array belonging to JAXA's (Japan Aerospace Exploration Agency) HTV-X1 cargo craft extends across the frame.
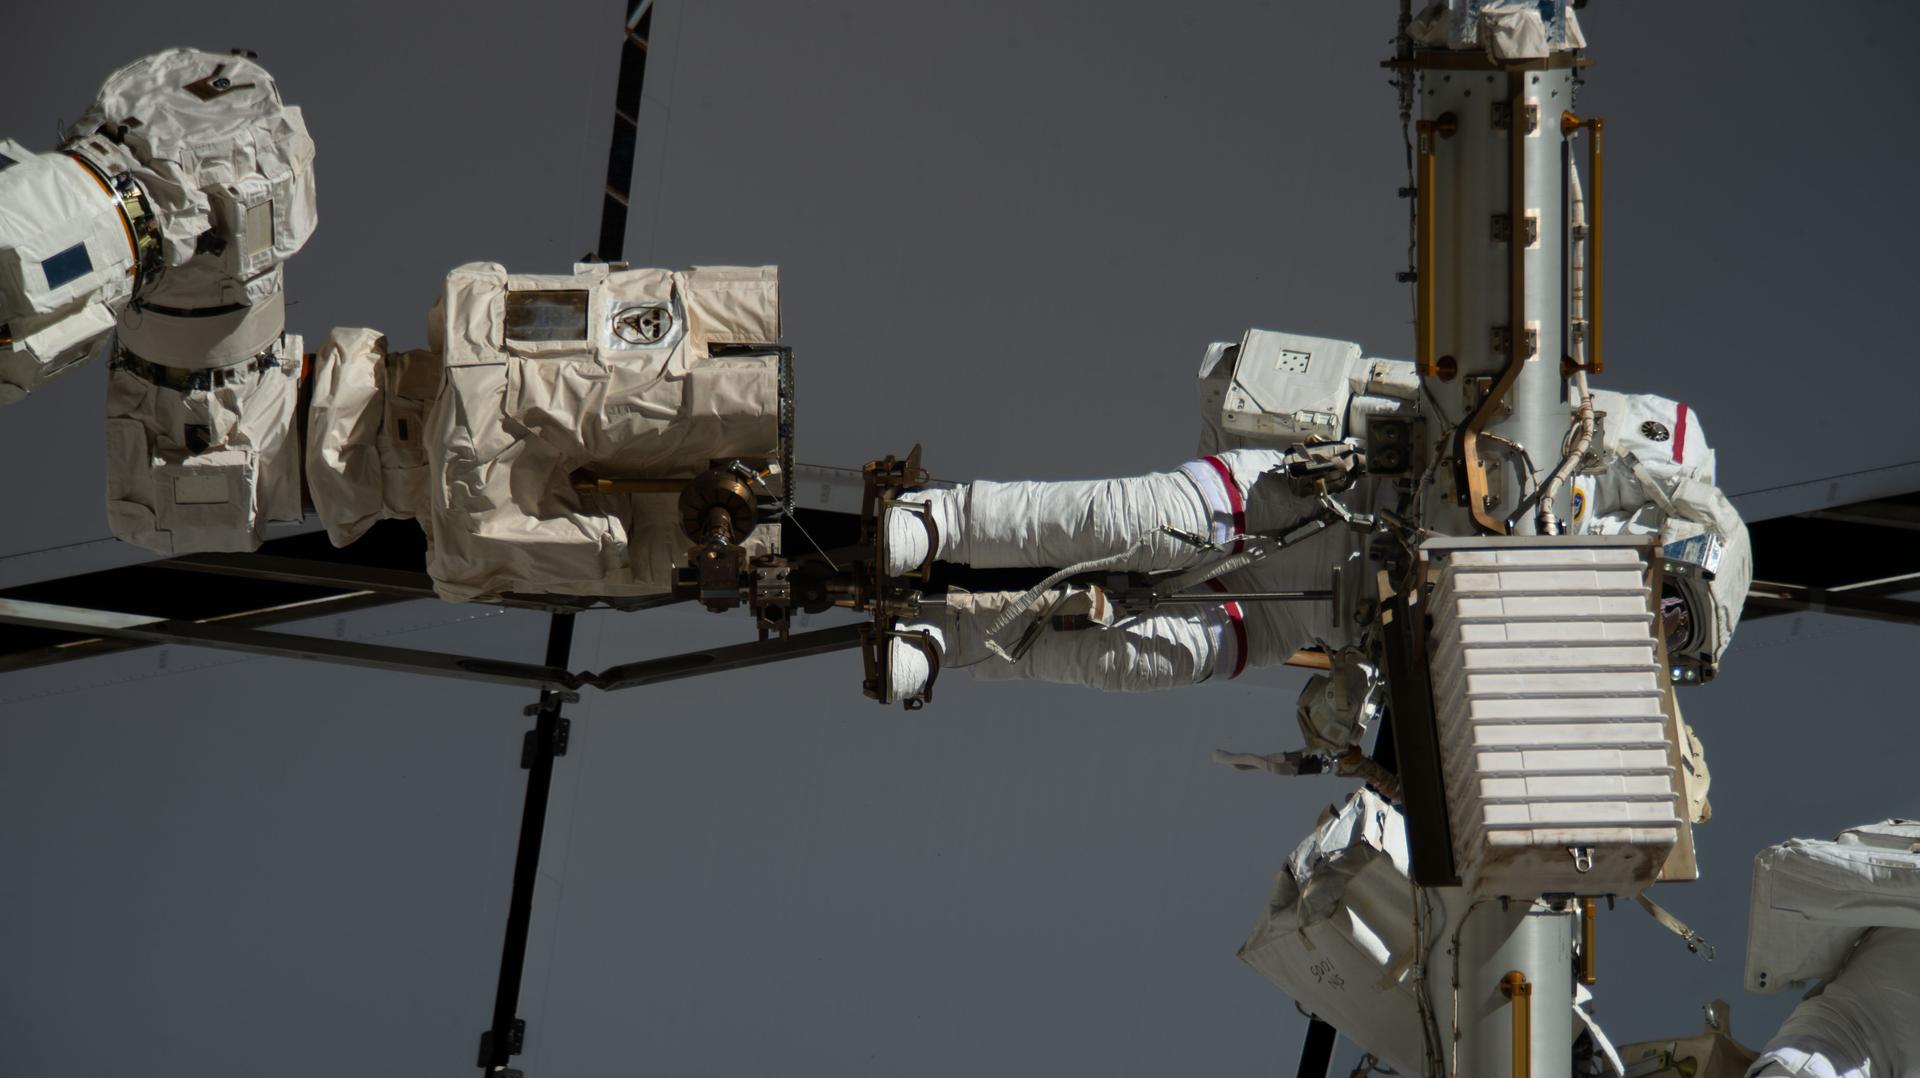
iss075e0068385 (Aug. 25, 2026) --- NASA astronaut and Expedition 75 flight engineer Anil Menon is attached to the Canadarm2 robotic arm’s latching end effector during a spacewalk to install a high-speed space-to-ground antenna on the International Space Station’s Z1 truss segment above the Unity module. Menon and ESA (European Space Agency) astronaut and Expedition 75 flight engineer Sophie Adenot (out of frame) spent six hours and 30 minutes replacing a failed antenna with a spare and making the precise connections needed to activate it for high-speed transmissions with mission control. Credit: NASA
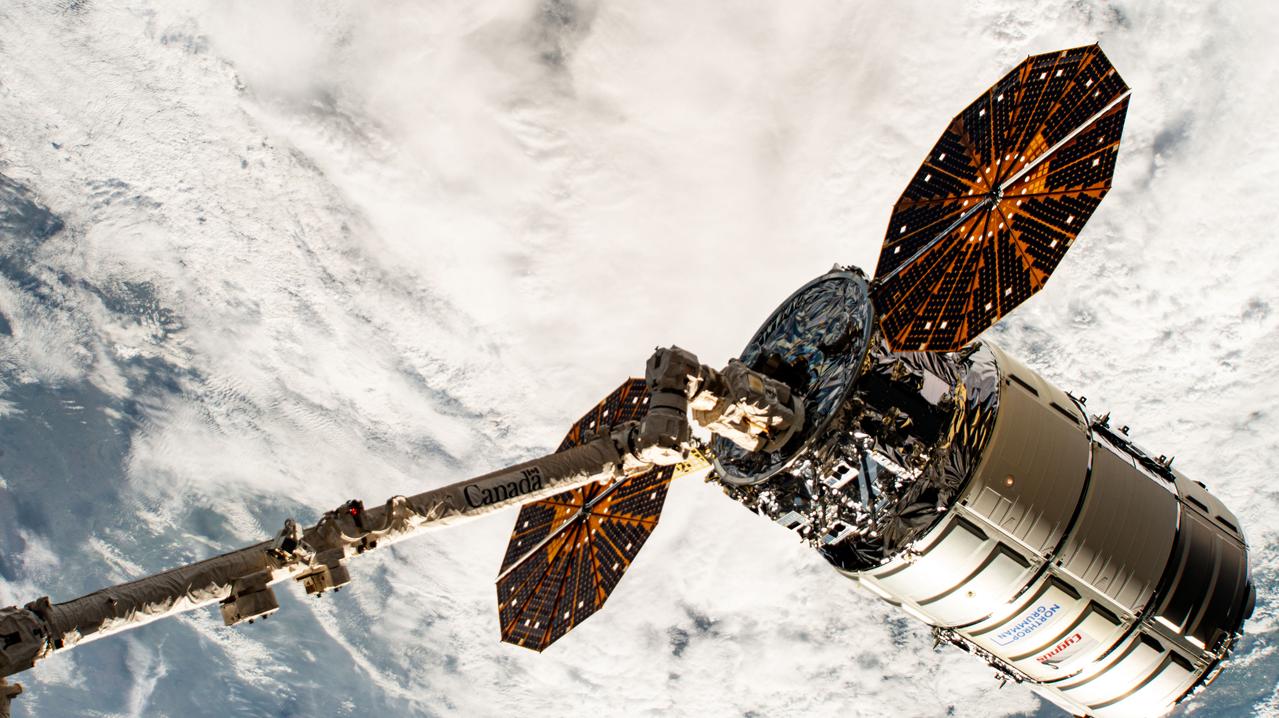
iss071e418235 (Aug. 6, 2024) --- Northrop Grumman's Cygnus cargo craft, with its prominent cymbal-shaped UltraFlex solar arrays, is pictured in the grips of the Canadarm2 robotic arm shortly after its capture was commanded by Expedition 71 Flight Engineer Matthew Dominick of NASA. The maneuver marked the 50th free-flying capture for the Canadarm2 robotic arm.
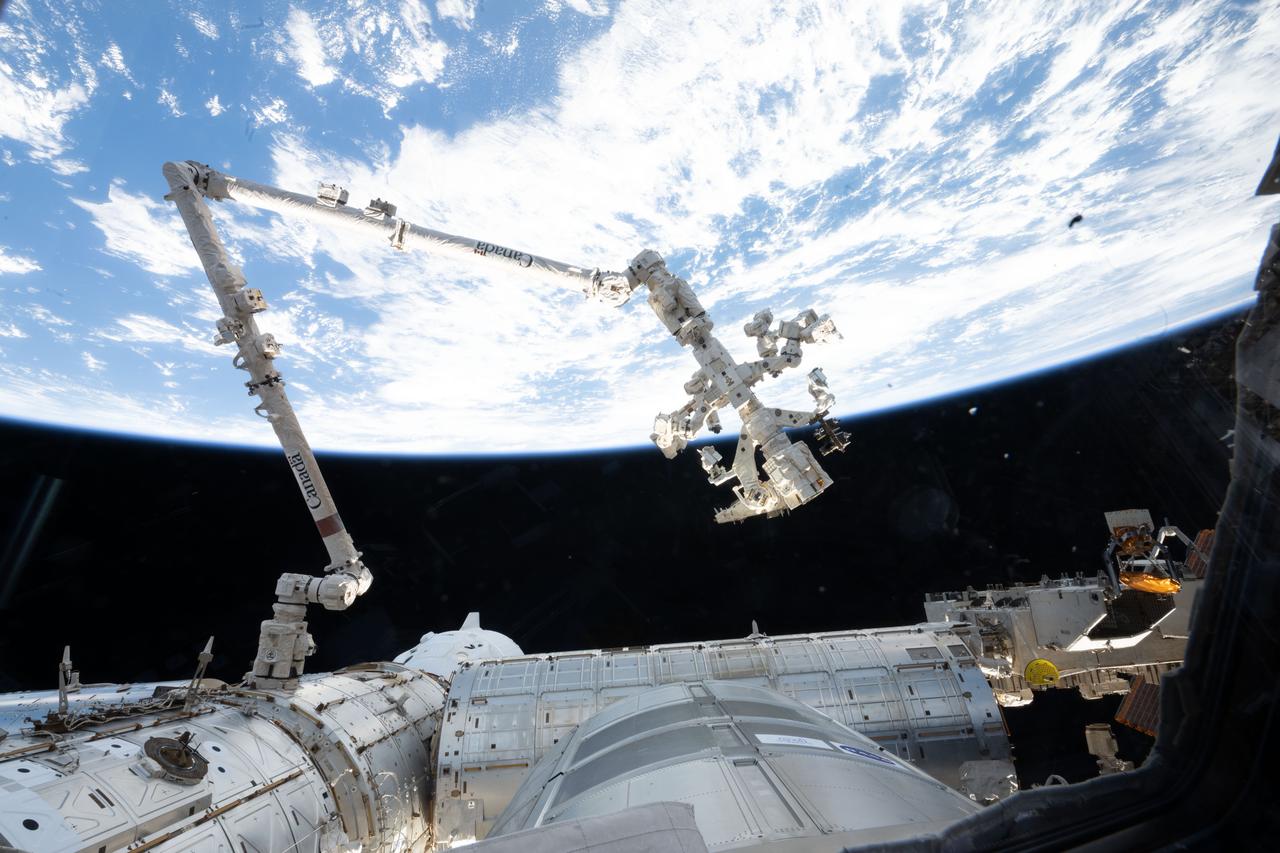
iss073e0575226 (July 23, 2025) --- The 57.7-foot-long Canadarm2 robotic arm extends from a data grapple fixture on the International Space Station’s Harmony module. Attached to its latching end effector is Dextre, the station’s fine-tuned robotic hand designed for delicate external maintenance tasks. The SpaceX Dragon crew spacecraft, partially obscured, is docked to Harmony’s forward port 259 miles above a cloudy Pacific Ocean southwest of Mexico.
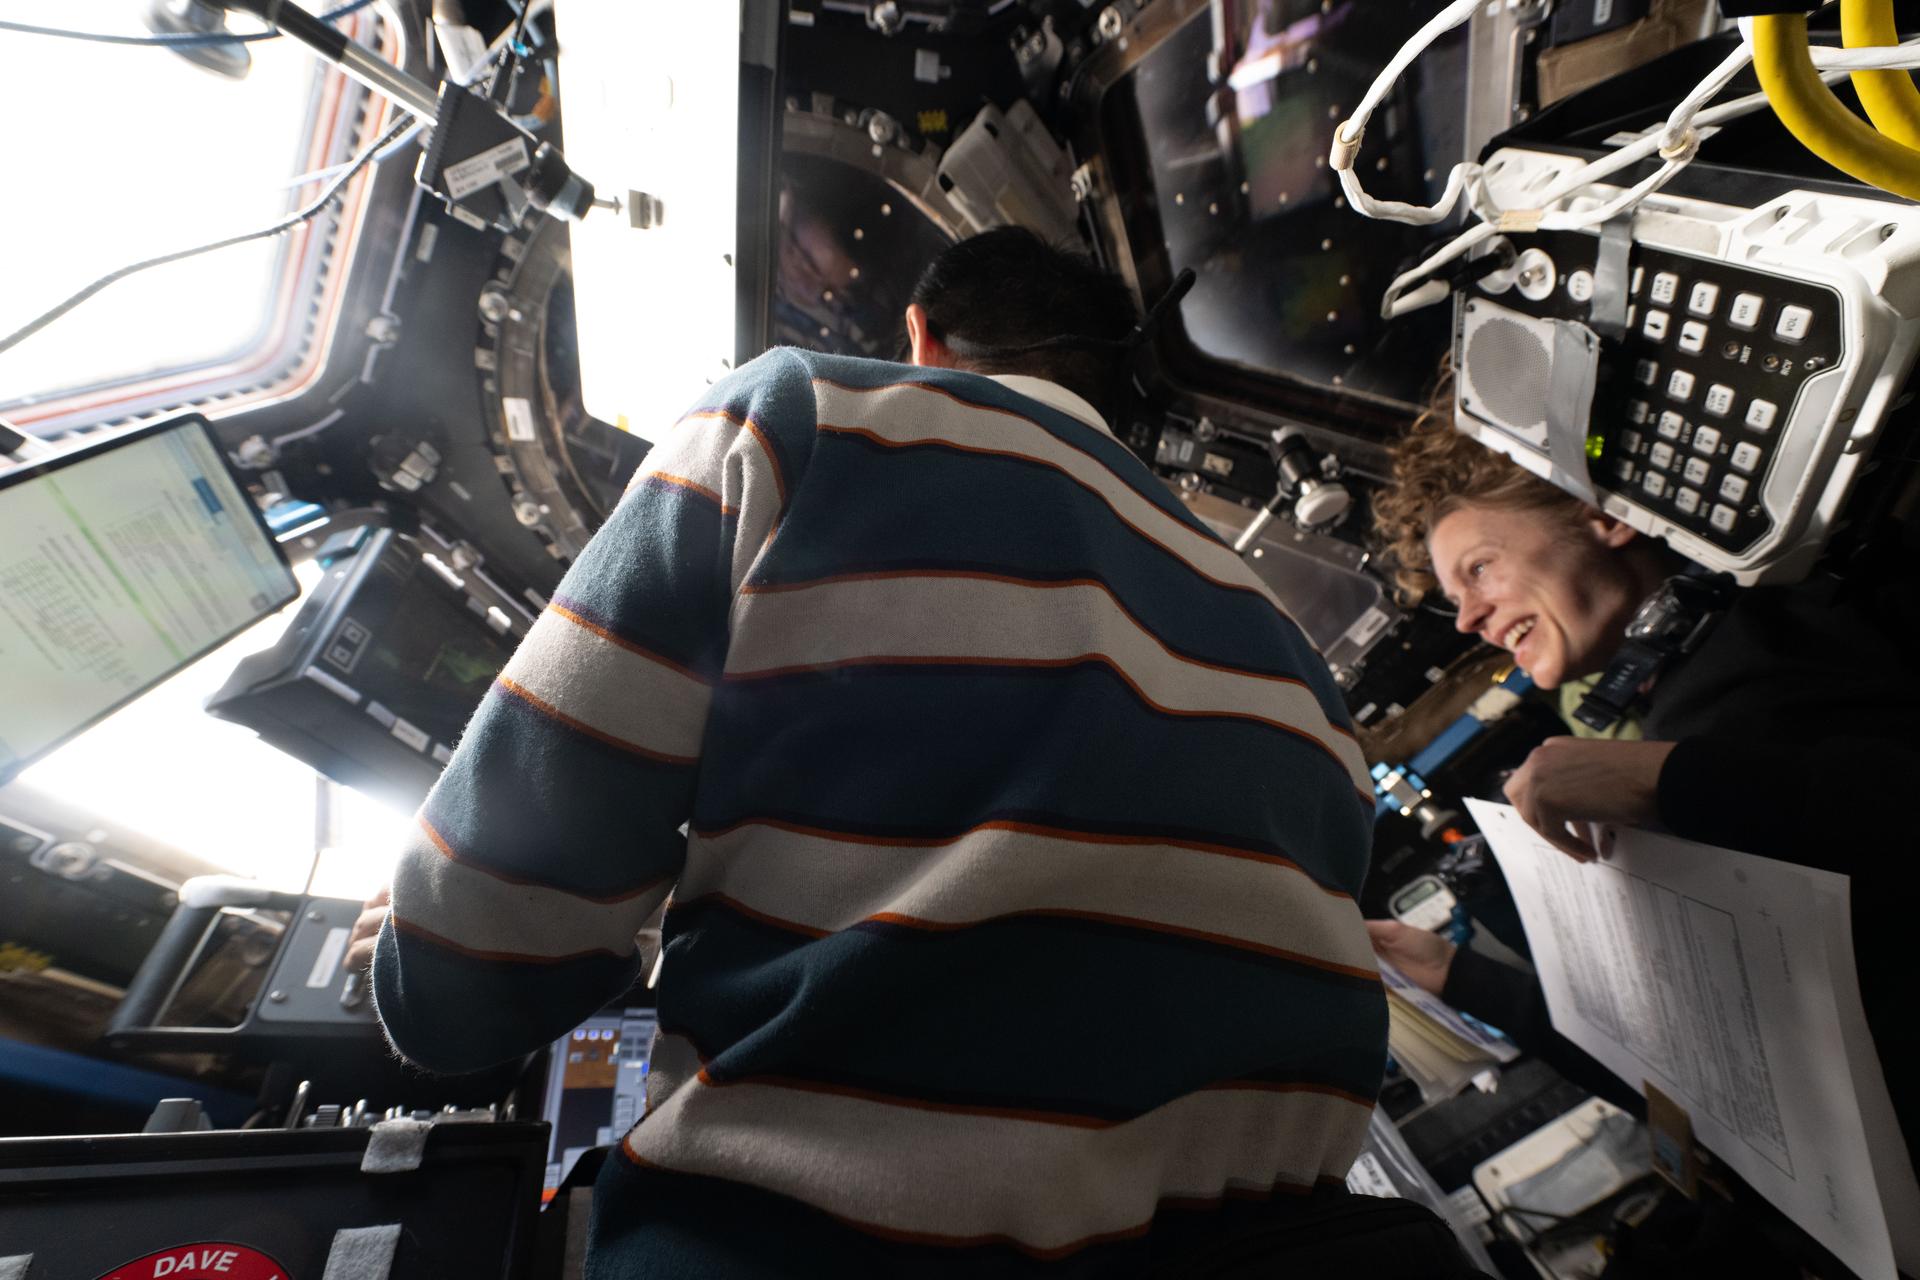
iss073e0886350 (Oct. 17, 2025) --- Expedition 73 Flight Engineers Kimiya Yui of JAXA (Japan Aerospace Exploration Agency) and Zena Cardman of NASA train inside the cupola to capture JAXA’s HTV-X1 cargo spacecraft using the Canadarm2 robotic arm. Yui will lead the robotic capture operations, while Cardman will monitor data and telemetry during HTV-X1’s approach and rendezvous with the International Space Station.
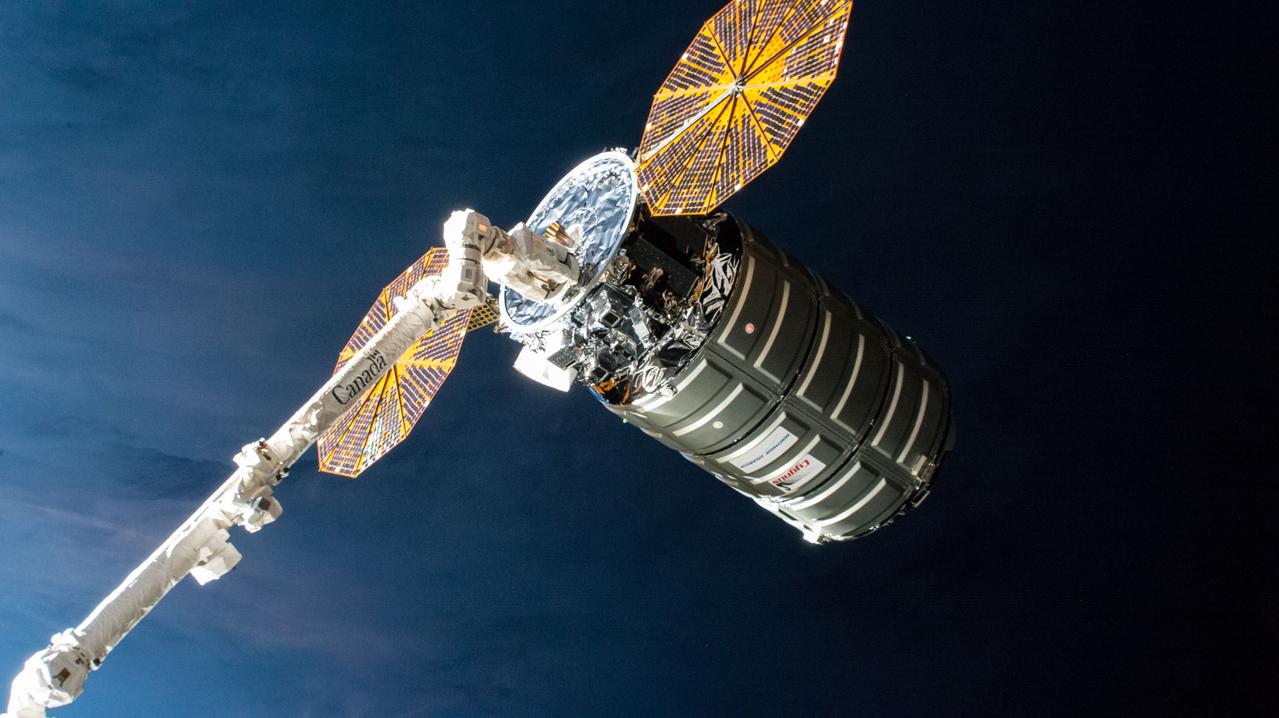
iss058e011396 (Feb. 8, 2019) --- The Cygnus cargo craft from Northrop Grumman is pictured firmly in the grips of the Canadarm2 robotic arm just before its release from the International Space Station.
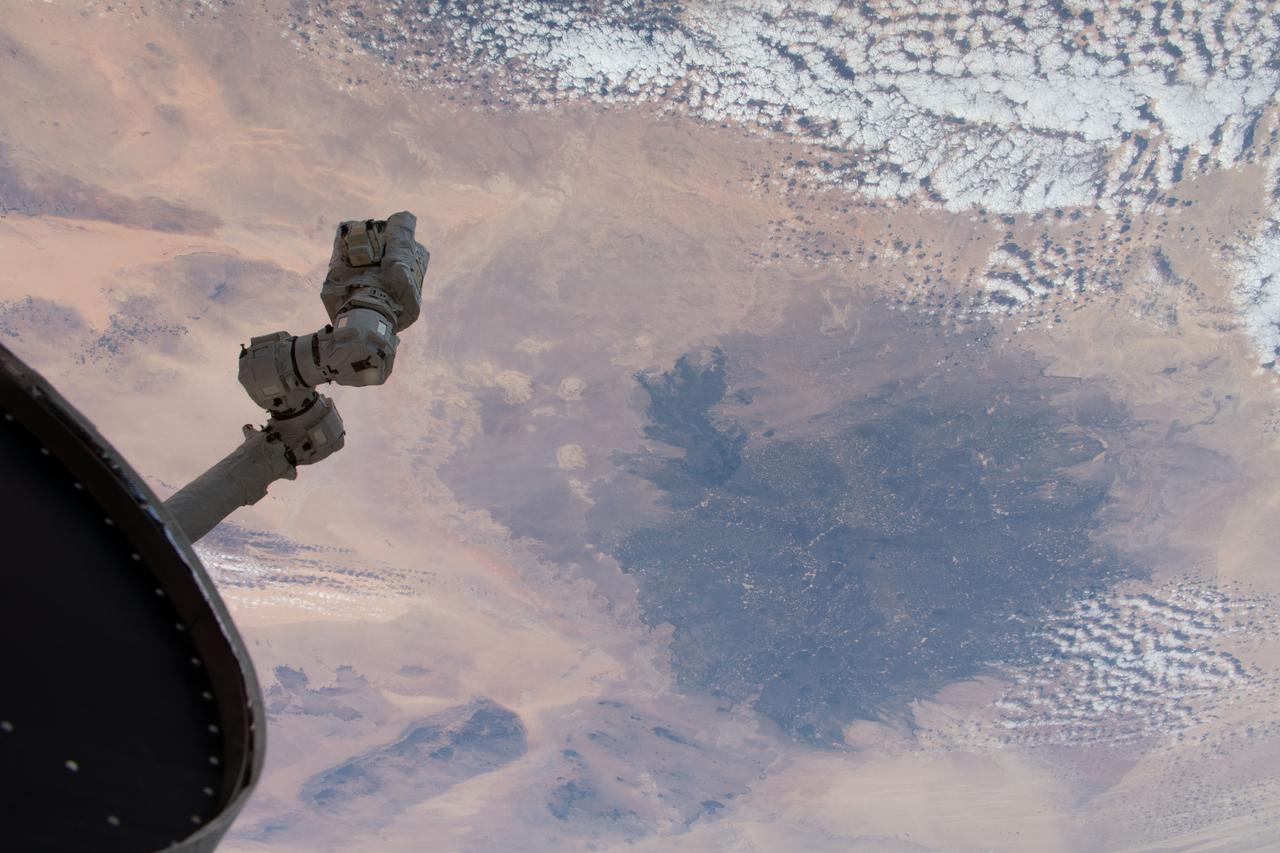
iss058e000174 (Dec. 23, 2018) --- The International Space Station's robotic arm, Canadarm2, seemingly reaches out to the North African nation of Libya and the Sahara 251 miles below.
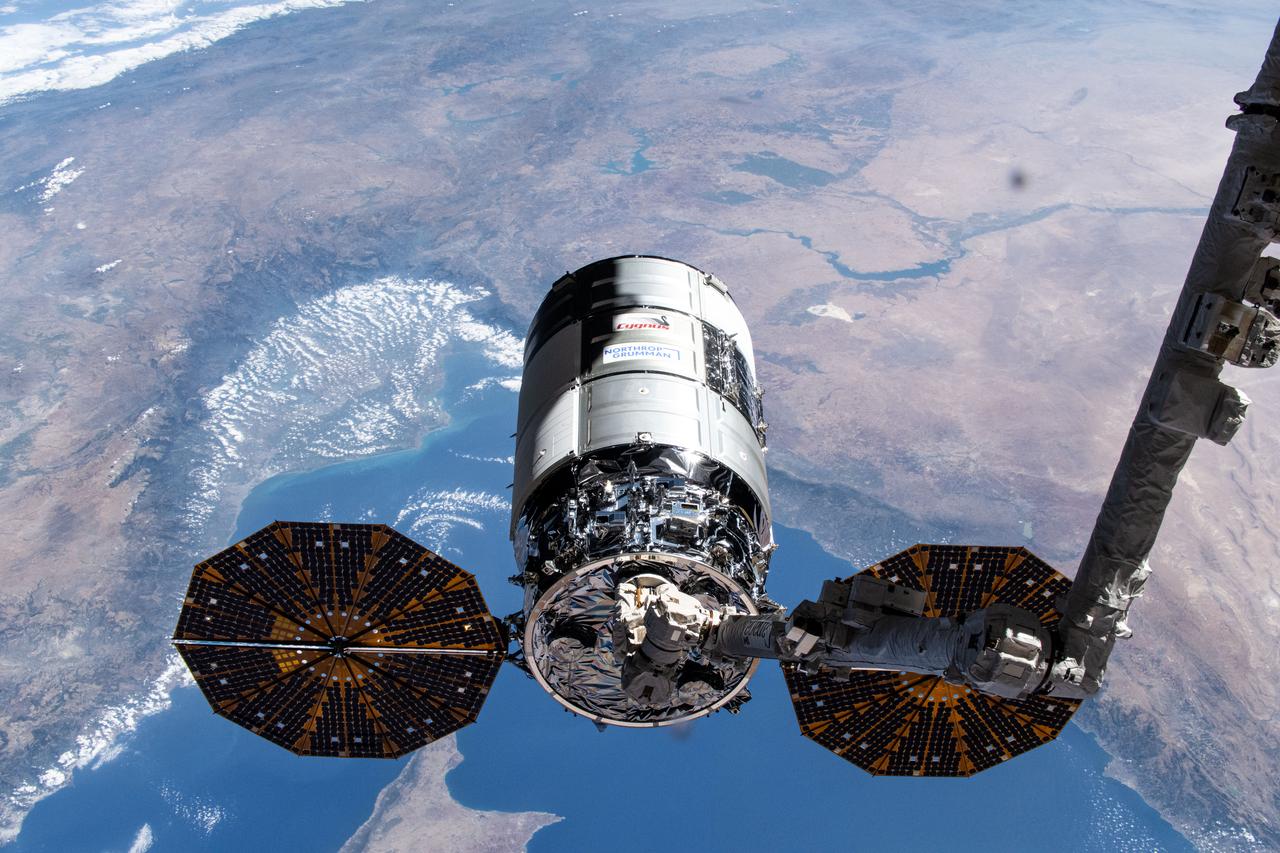
iss071e417237 (Aug. 6, 2024) --- Northrop Grumman's Cygnus cargo craft, with its prominent cymbal-shaped UltraFlex solar arrays, is pictured in the grips of the Canadarm2 robotic arm shortly after its capture was commanded by Expedition 71 Flight Engineer Matthew Dominick of NASA. The maneuver marked the 50th free-flying capture for the Canadarm2 robotic arm. The International Space Station was orbiting 262 miles above the Mediterranean Sea at the time of this photograph.
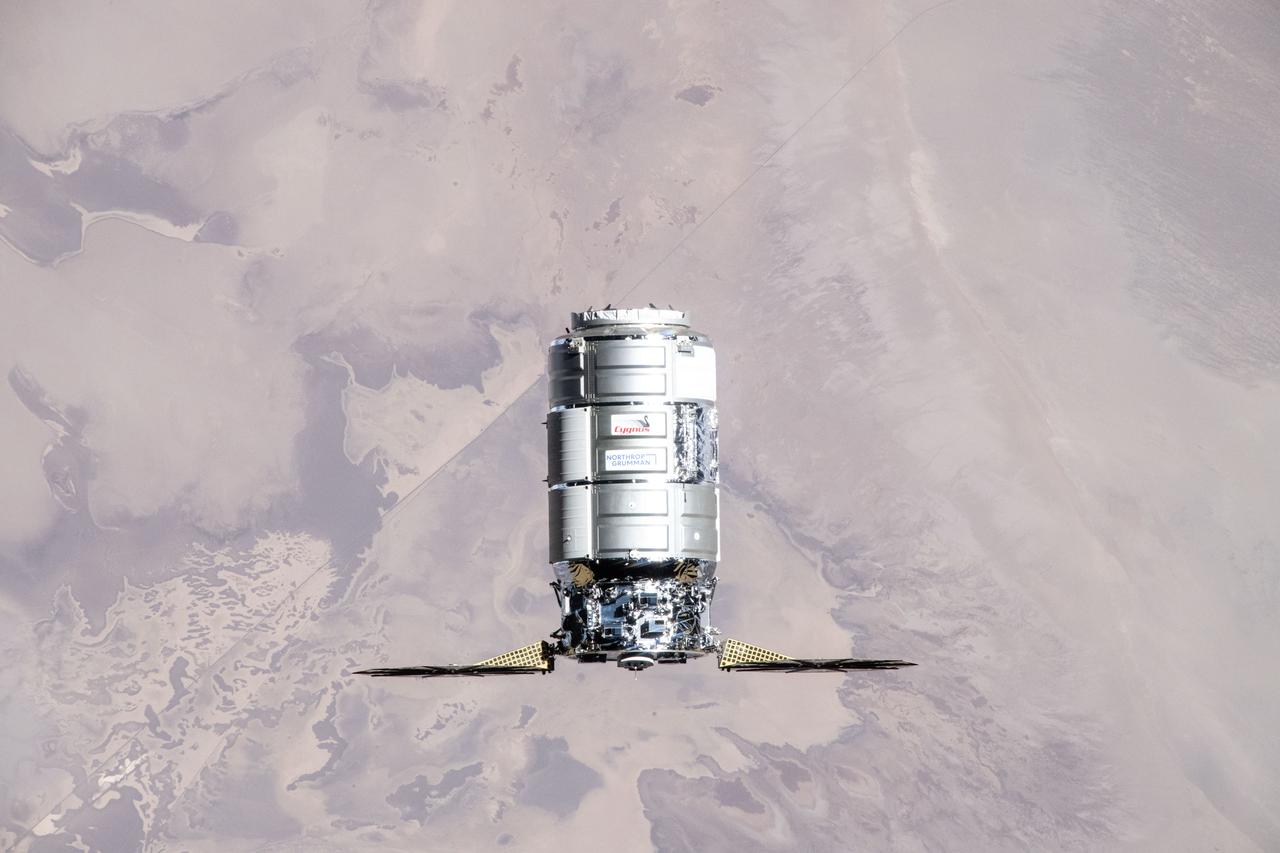
iss071e416716 (Aug. 6, 2024) --- Northrop Grumman's Cygnus cargo craft, carrying 8,200 pounds of science and supplies, approaches the International Space Station for a capture with the Canadarm2 robotic arm commanded by Expedition 71 Flight Engineer Matthew Dominick of NASA. The maneuver marked the 50th free-flying capture for the Canadarm2 robotic arm. The orbital outpost was soaring 262 miles above central Iran at the time of this photograph.
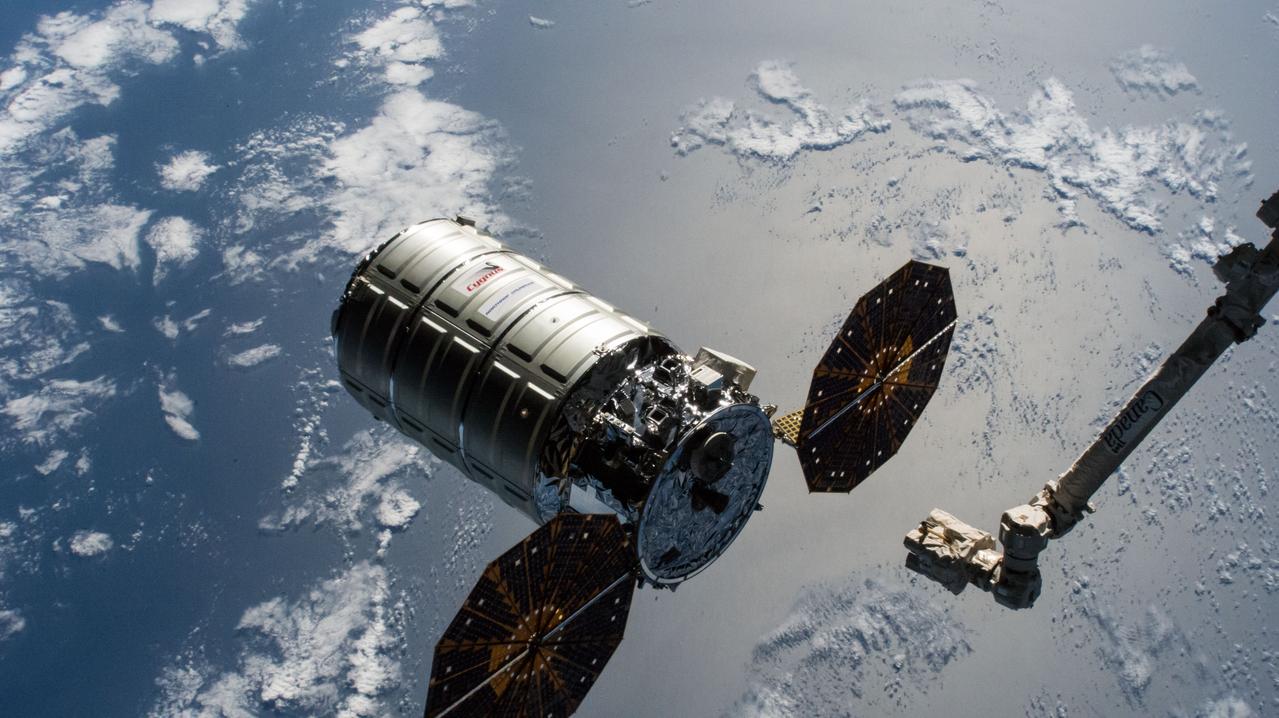
iss058e011814 (Feb. 8, 2019) --- The Cygnus cargo craft from Northrop Grumman is released from the grips of the Canadarm2 robotic arm as the International Space Station was orbiting over the Pacific Ocean off the coast of Peru.
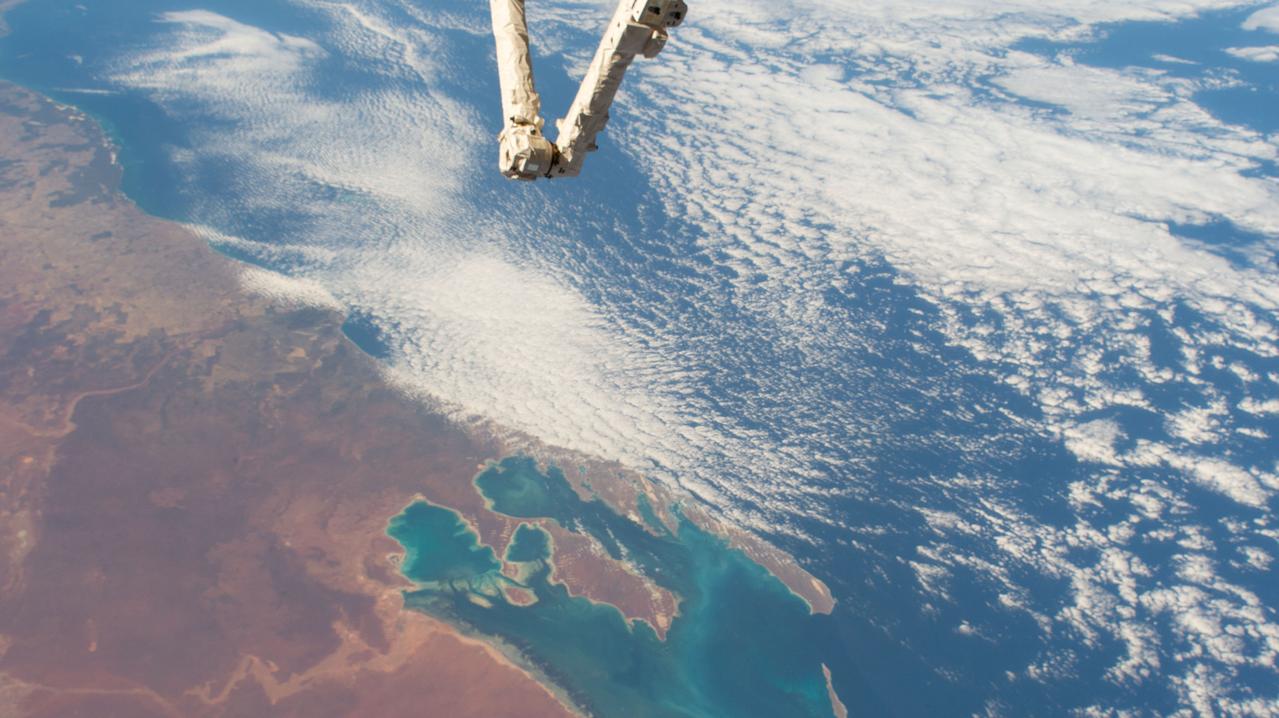
iss058e002638 (Jan. 14, 2019) --- Australia's Shark Bay, the Indian Ocean and the elbow of the Canadarm2 robotic arm are pictured as the International Space Station orbited nearly 256 miles above the state of Western Australia.

iss058e011813 (Feb. 8, 2019) --- The Cygnus cargo craft from Northrop Grumman is pictured in the grips of the Canadarm2 robotic arm moments before its release as the International Space Station was orbiting over the Pacific Ocean.
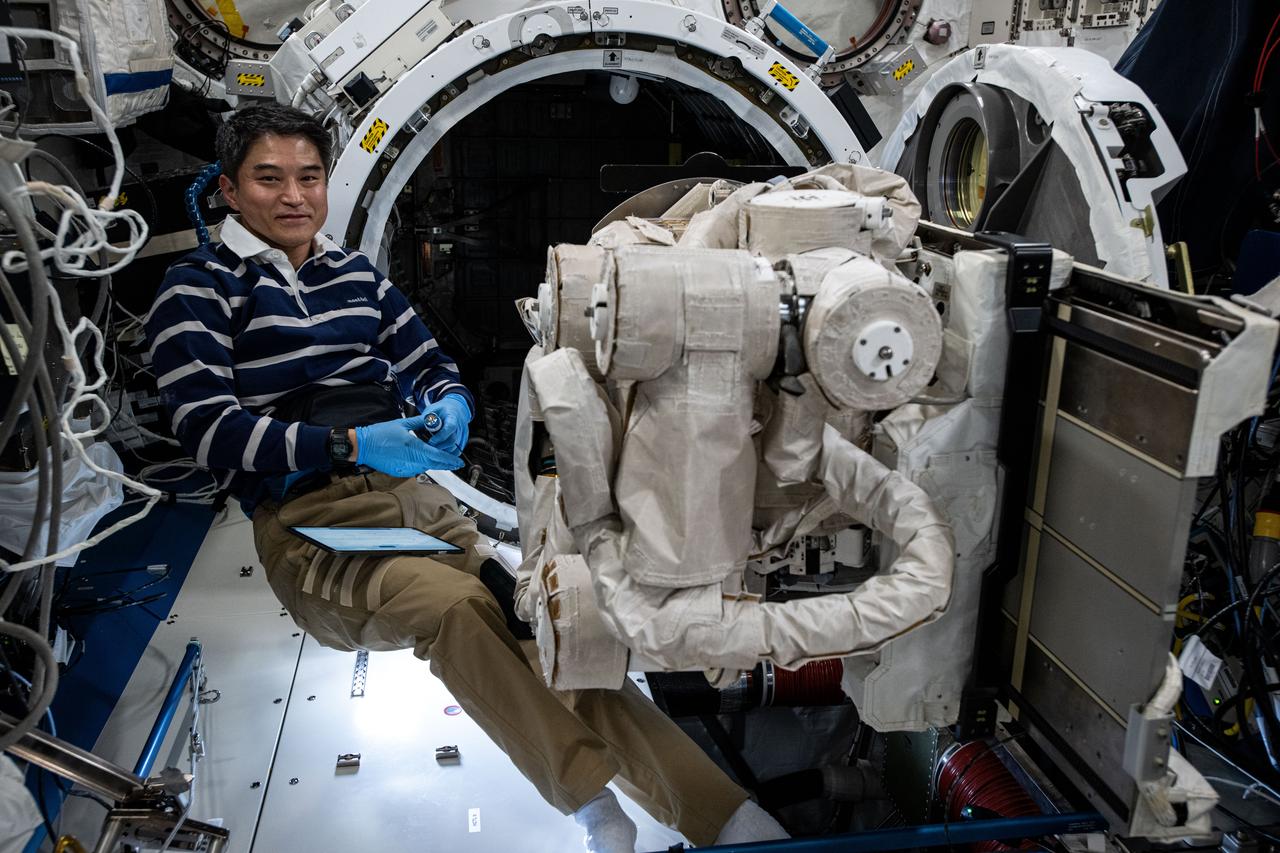
iss073e0133686 (June 3, 2025) --- JAXA (Japan Aerospace Exploration Agency) astronaut and Expedition 73 Commander is pictured during maintenance operations on the Japanese robotic arm's Small Fine Arm inside the Kibo laboratory module. The Small Fine Arm is used for precise and dexterous robotic maneuvers when grappling small components or payloads on the outside of the International Space Station. There are two other robotic arms on the outside of the orbital outpost including the Canadarm2 robotic arm and the European robotic arm (ERA). Canadarm2 can be used to maneuver spacecraft, spacewalkers, and large payloads. ERA can also be used to maneuver spacewalkers and space station components.
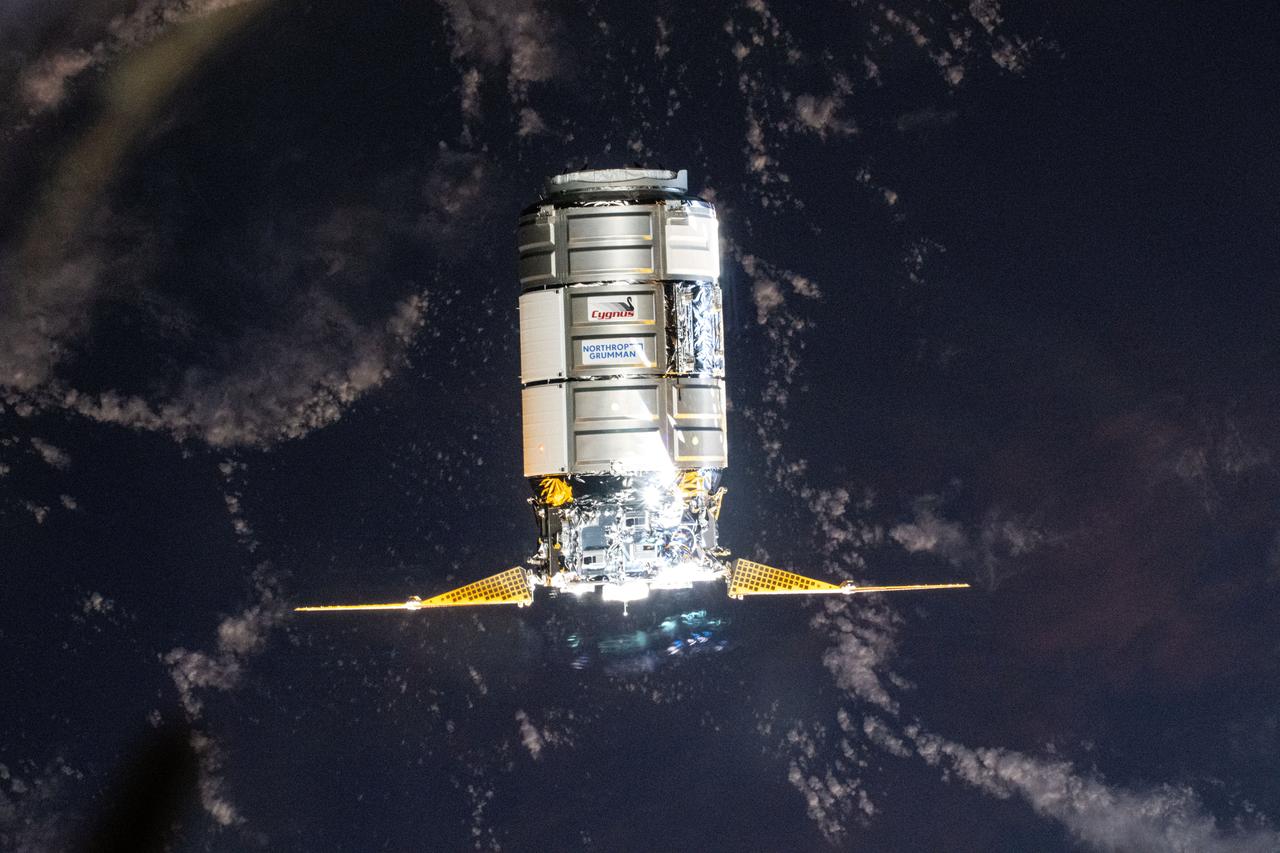
iss071e418212 (Aug. 6, 2024) --- Northrop Grumman's Cygnus cargo craft, carrying 8,200 pounds of science and supplies, approaches the International Space Station for a capture with the Canadarm2 robotic arm commanded by Expedition 71 Flight Engineer Matthew Dominick of NASA. The maneuver marked the 50th free-flying capture for the Canadarm2 robotic arm.

ISS047e152971 (03/26/2016) --- Expedition 47 robotic arm operator Tim Kopra of NASA commanded the International Space Station’s Canadarm2 robotic arm to capture the Cygnus spacecraft.
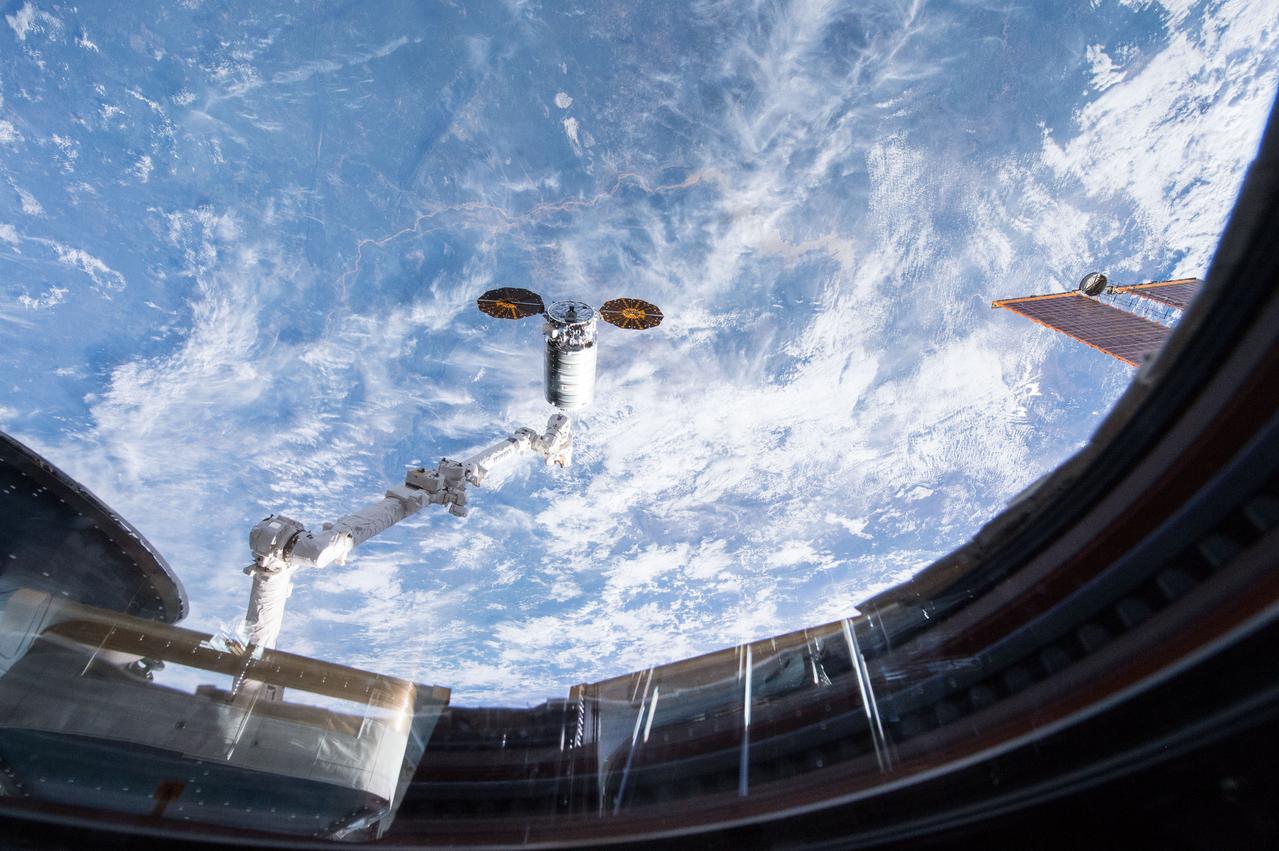
ISS047e021586 03/26/2016) --- Cygnus capture March 26, 2016. Expedition 47 robotic arm operator NASA astronaut Tim Kopra commanded the International Space Station’s Canadarm2 robotic arm to capture the Cygnus spacecraft .
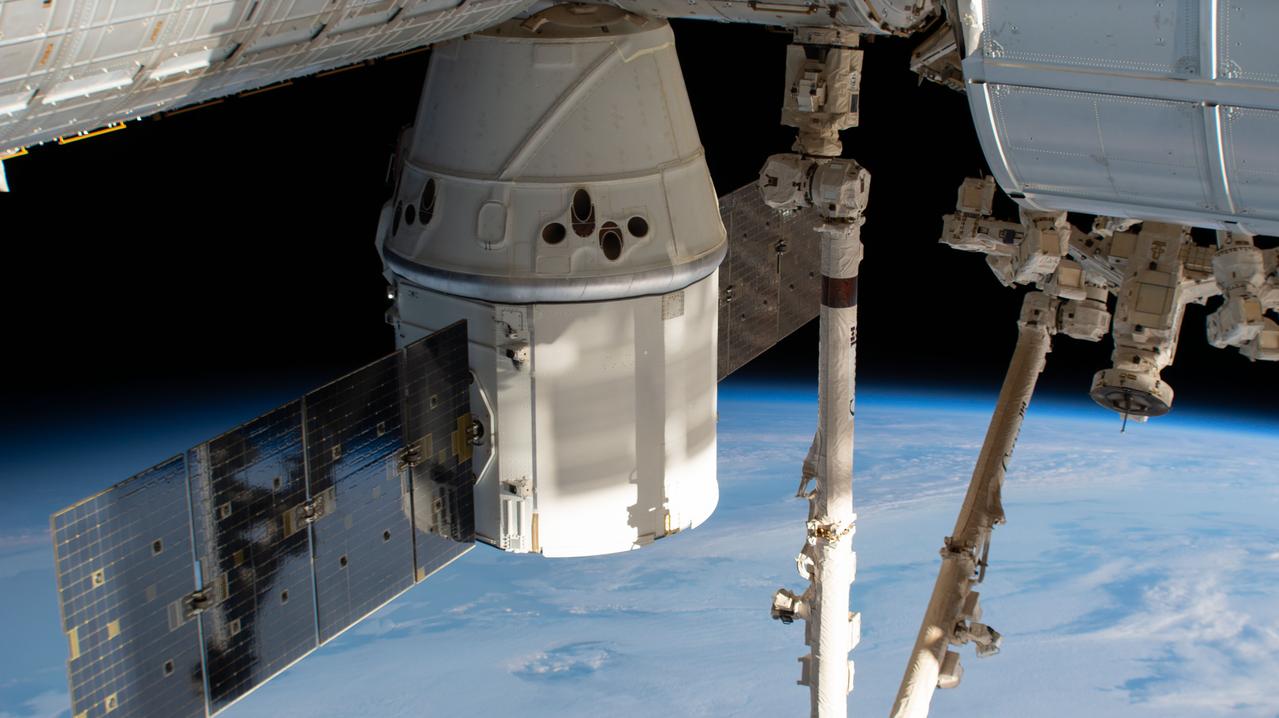
iss058e002241 (Jan. 7, 2019) --- The SpaceX Dragon cargo craft is pictured attached to the International Space Station's Harmony module as the orbital complex orbited 261 miles above the Indian Ocean southeast of the continent of Africa. The Canadarm2 robotic arm vertically splits the frame prior to grappling the spacecraft ahead of planned departure activities.
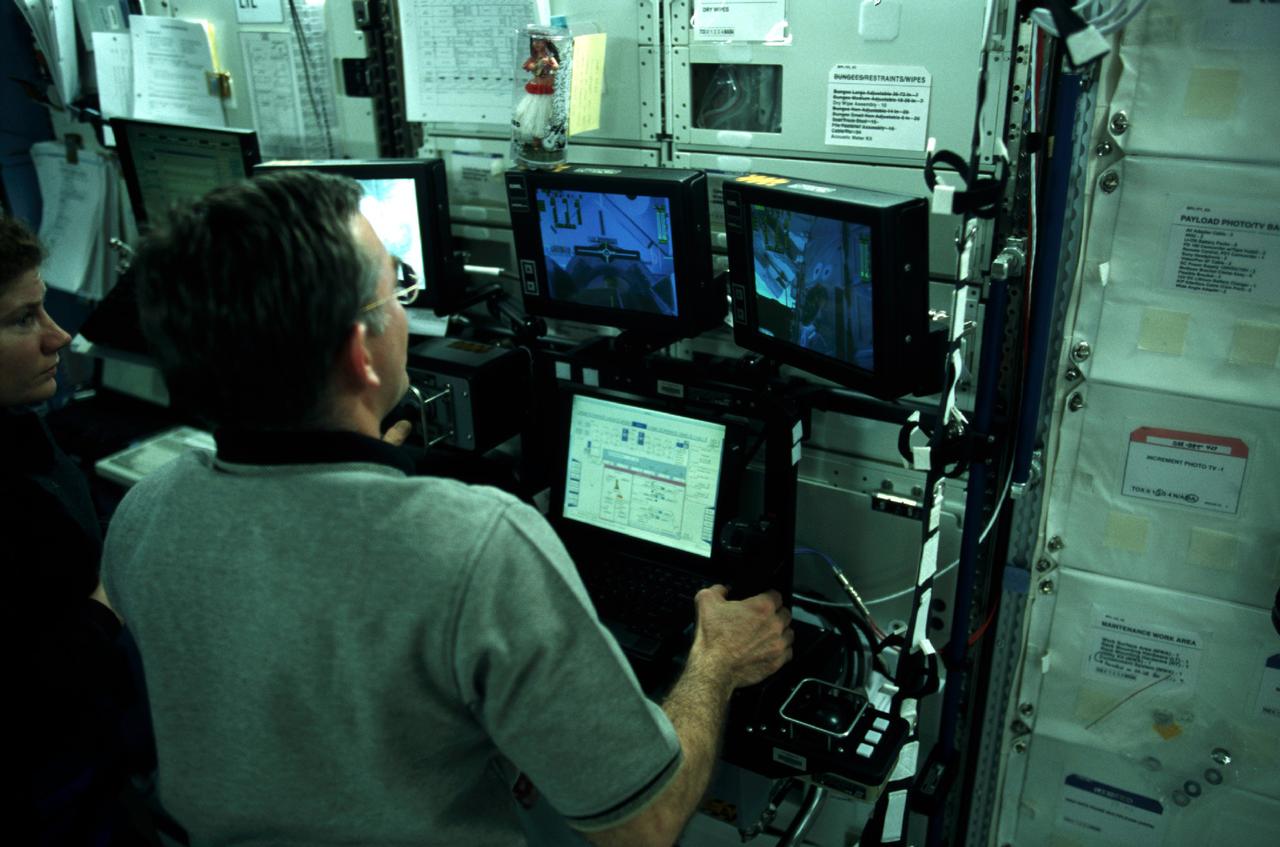
A Canadian "handshake" in space occurred on April 28, 2001, as the Canadian-built space station robotic arm (Canadarm2) transferred its launch cradle over to Endeavour's robotic arm. Pictured is astronaut James S. Voss, Expedition Two flight engineer, working the controls of the new robotic arm. Marning the controls from the shuttle's aft flight deck, Canadian Mission Specialist Chris A. Hadfield of the Canadian Space Agency (CSA) was instrumental in the activity. The Space lab pallet that carried the Canadarm2 robotic arm to the station was developed at the Marshall Space Flight Center (MSFC) in Huntsville, Alabama.
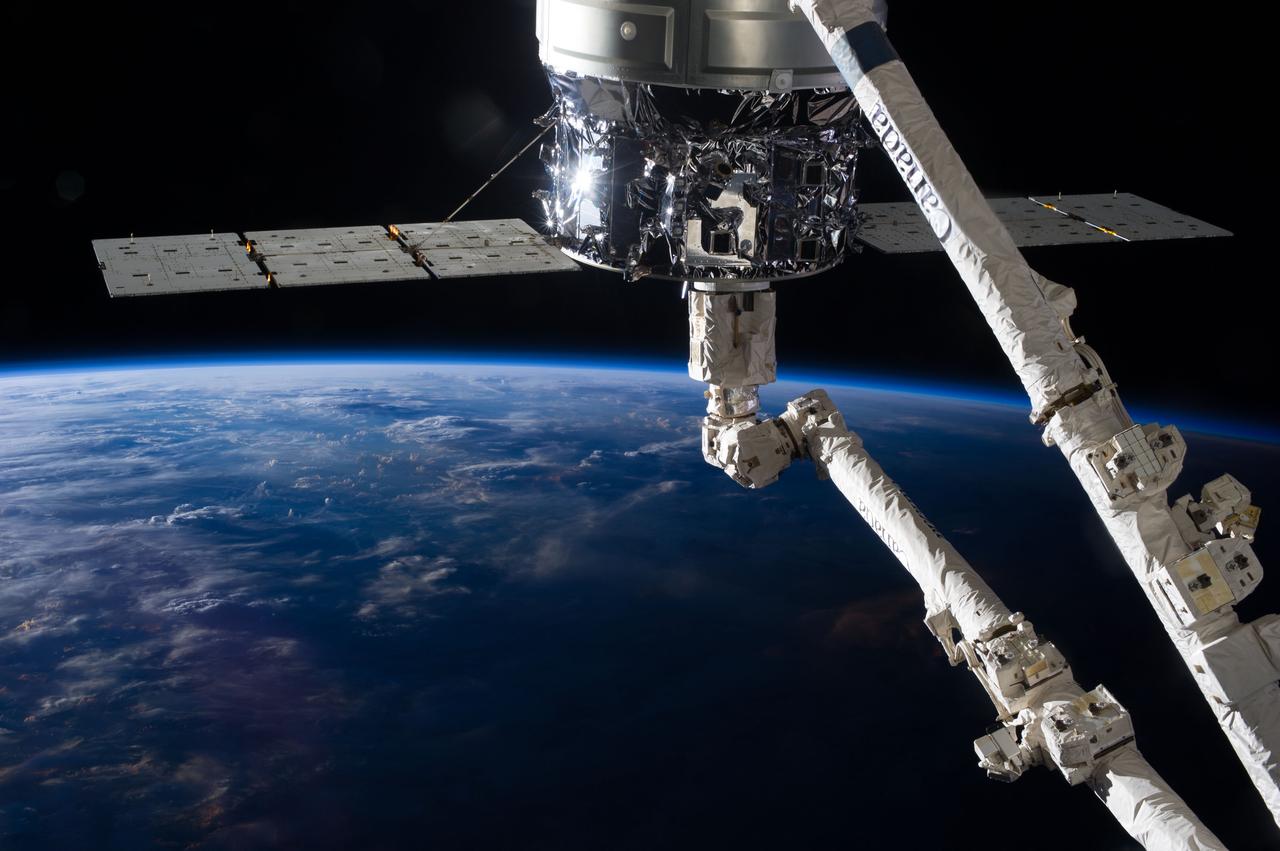
View of the first Cygnus commercial cargo spacecraft built by Orbital Sciences Corp attached to the end of the robotic arm (AKA Canadarm2) and docked the Node 2 module of the ISS. Per Twitter message: Sunrise on #Cygnus and #Canadarm2.

iss059e043274 (May 6, 2019) --- The SpaceX Dragon cargo craft is maneuvered toward the Harmony module's Earth-facing port by robotics controllers remotely operating the Canadarm2 robotic arm. Astronaut David Saint-Jacques earlier commanded the Canadarm2 robotic arm to capture Dragon as astronaut Nick Hague backed him up and monitored systems.

iss064e020720 (Jan. 2021) --- The Northrop Grumman Cygnus space freighter is pictured attached to the Canadarm2 robotic arm after it had been uninstalled from the International Space Station's Unity module. Robotics controllers would command the Canadarm2 a few hours later to release Cygnus after 93 days attached to Unity.

iss064e020615 (Jan. 2021) --- The Northrop Grumman Cygnus space freighter is pictured attached to the Canadarm2 robotic arm after it had been uninstalled from the International Space Station's Unity module. Robotics controllers would command the Canadarm2 a few hours later to release Cygnus after 93 days attached to Unity.

iss064e020730 (Jan. 2021) --- The Northrop Grumman Cygnus space freighter is pictured attached to the Canadarm2 robotic arm after it had been uninstalled from the International Space Station's Unity module. Robotics controllers would command the Canadarm2 a few hours later to release Cygnus after 93 days attached to Unity.
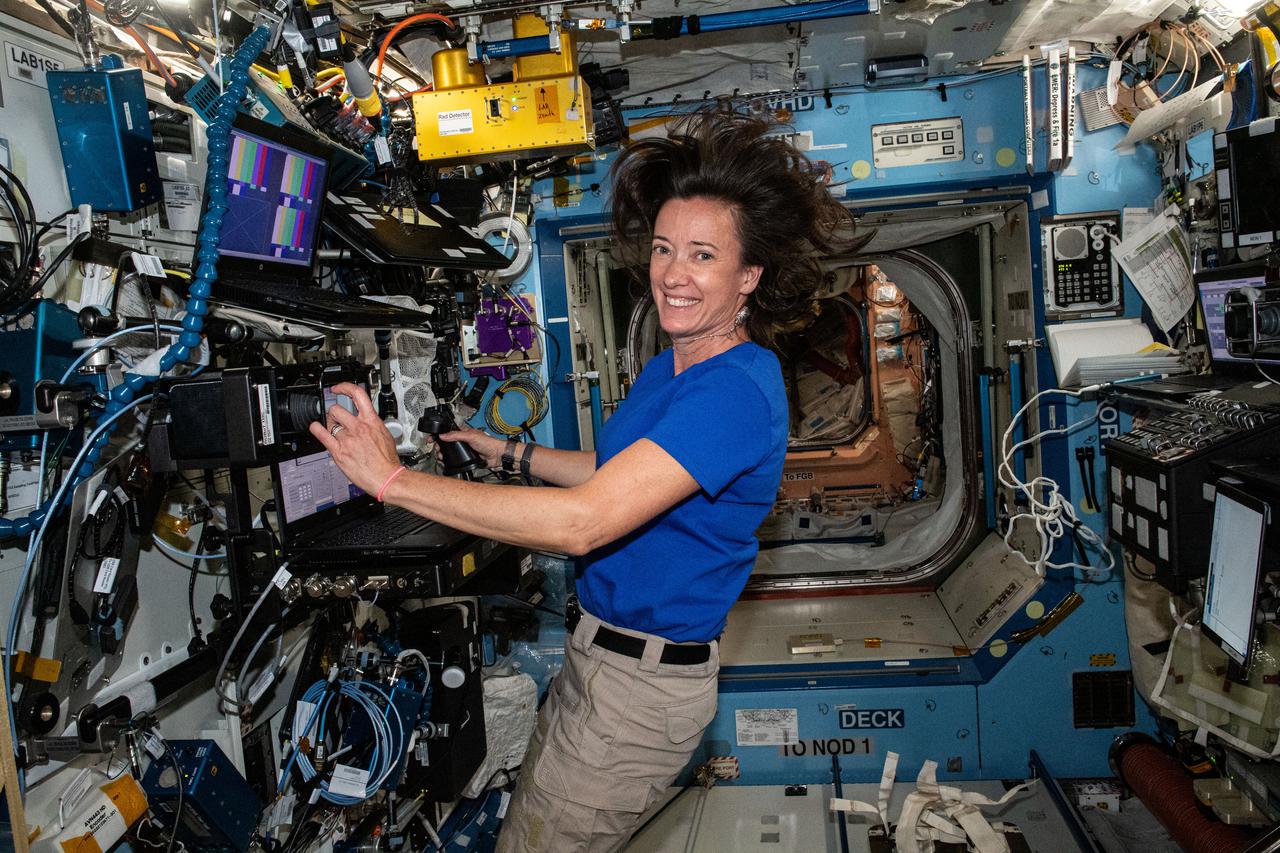
iss065e009568 (April 29, 2021) --- NASA astronaut and Expedition 65 Flight Engineer Megan McArthur is at the robotics workstation inside the U.S. Destiny laboratory module participating in Canadarm2 robotic arm training.

iss061e077393 (Dec. 12, 2019) --- The Canadarm2 robotic arm with the Dextre robotic hand attached seemingly protrudes from the side of the International Space Station as the orbiting complex soared 263 miles above the South Pacific Ocean.
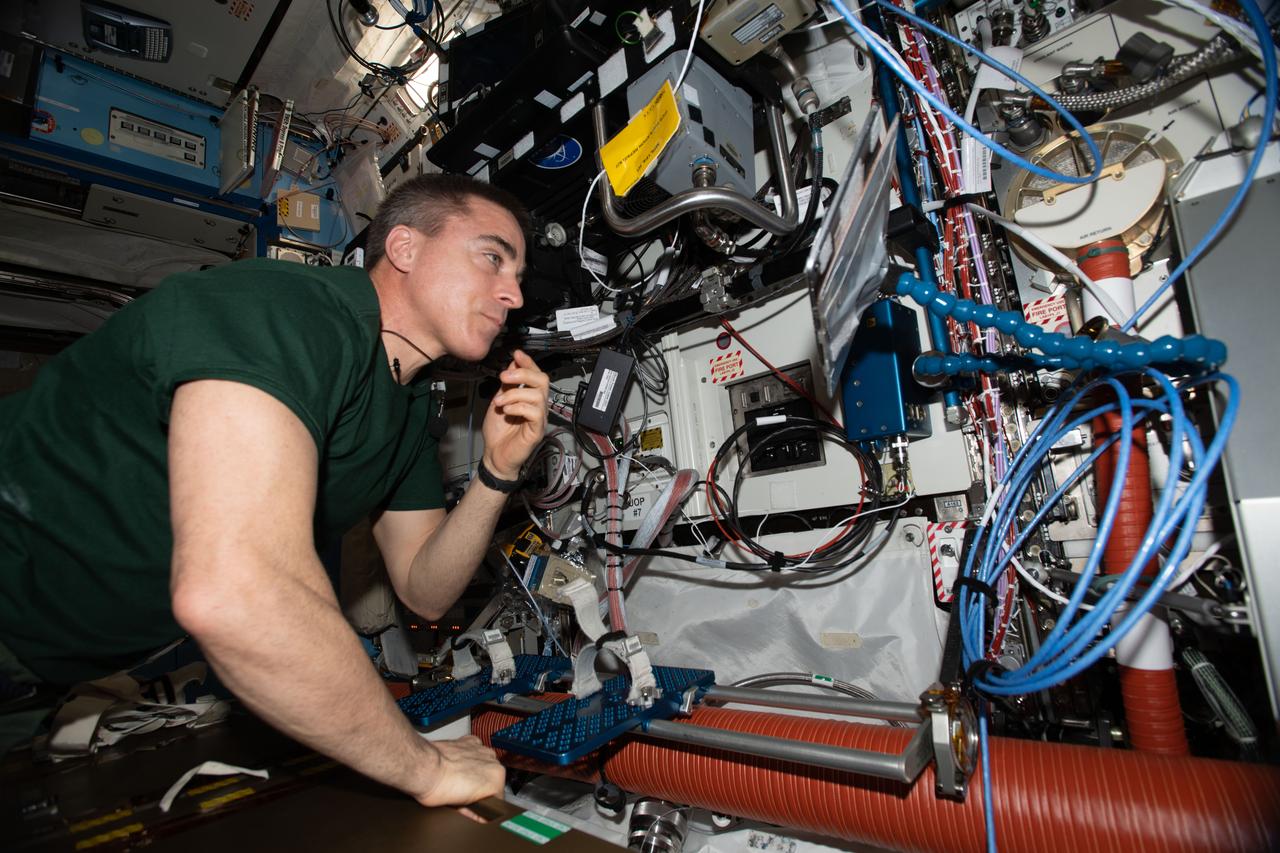
iss063e044599 (July 13, 2020) --- NASA astronaut and Expedition 63 Commander Chris Cassidy swaps a hard disk drive during computer maintenance on the robotics work station which controls and commands the Canadarm2 robotic arm.

iss071e178989 (June 9, 2024) --- Dextre, the fine-tuned robotic hand attached to the Canadarm2 robotic arm, extends from the International Space Station while orbiting 259 miles above the Pacific Ocean southwest of Baja California.

iss071e185049 (June 14, 2024) --- The Canadarm2 robotic arm with Dextre, its fine-tuned robotic hand attached, extends from the International Space Station while orbiting 263 miles above the Atlantic Ocean.

iss070e014288 (Oct. 26, 2023) --- The Canadarm2 robotic arm, with its fine-tuned robotic hand Dextre attached, is pictured as the International Space Station orbited 260 miles above the city lights of the Arabian Peninsula.
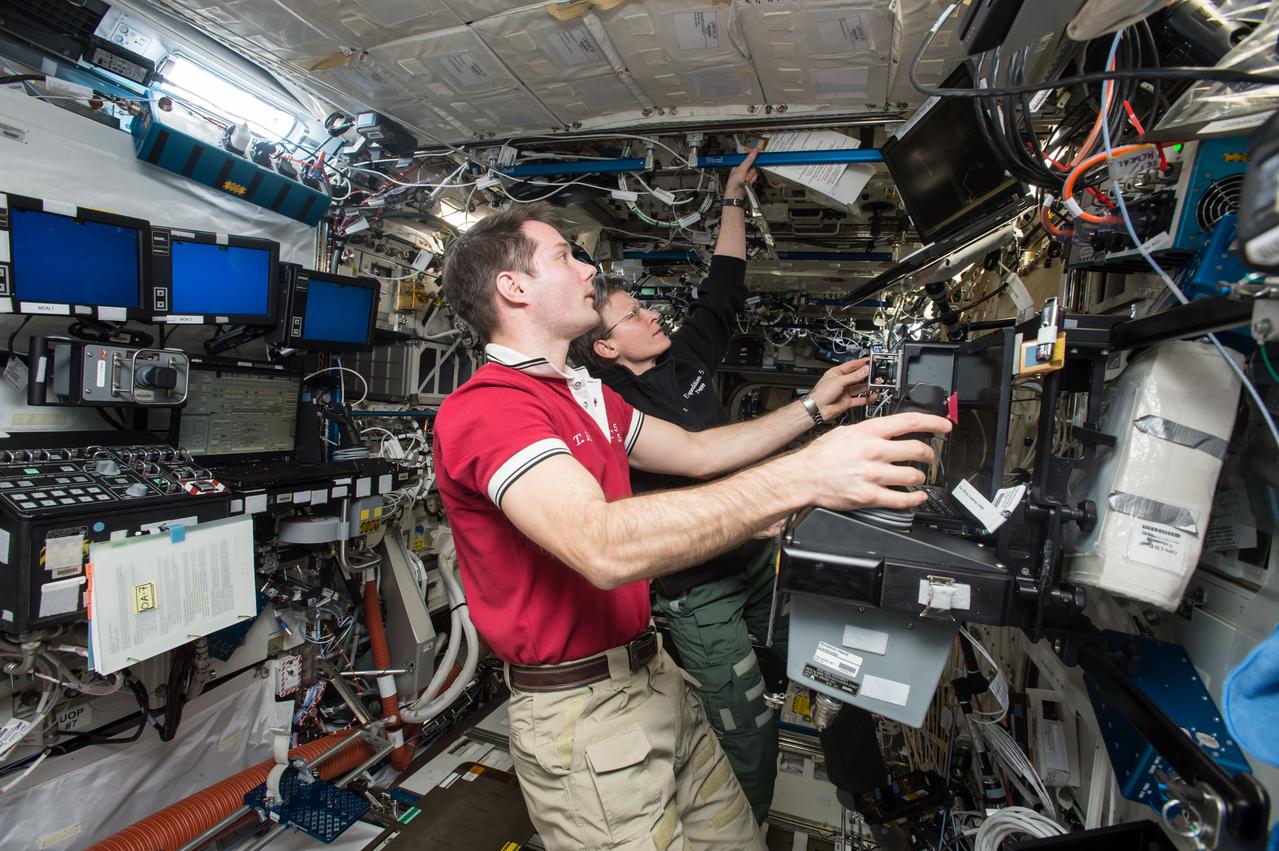
iss051e020157 (April 21, 2017) --- Expedition 51 Flight Engineer Thomas Pesquet (foreground) and Commander Peggy Whitson use the robotics work station in the Destiny laboratory module to practice capturing a resupply ship with the Canadarm2 robotic arm.
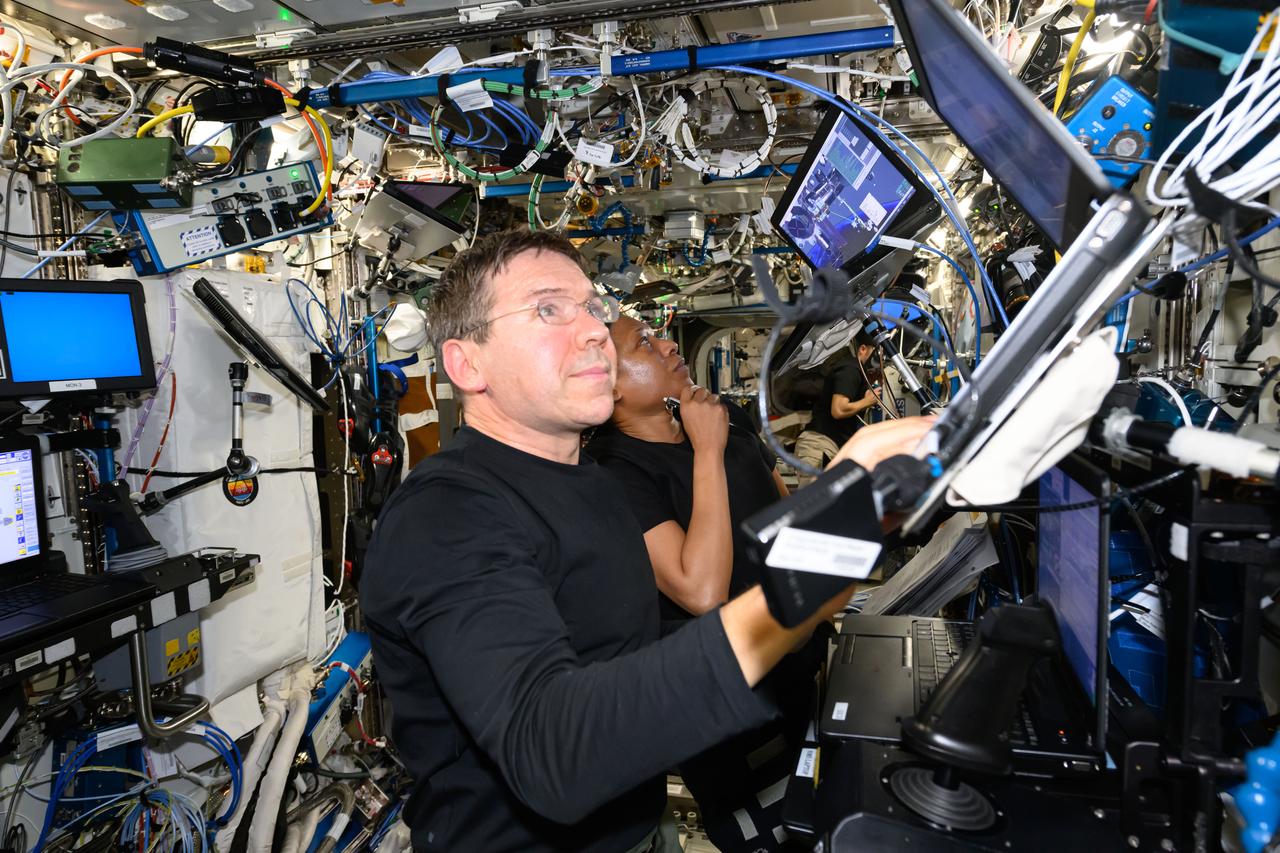
iss071e180163 (June 10, 2024) --- Expedition 71 Flight Engineers Mike Barratt and Jeanette Epps, both NASA astronauts, look at computer monitors on the Destiny laboratory module's robotics workstation that controls the Canadarm2 robotic arm.

iss065e009564 (April 28, 2021) --- NASA astronaut and Expedition 65 Flight Engineer Shane Kimbrough is at the robotics workstation inside the U.S. Destiny laboratory module participating in Canadarm2 robotic arm training.
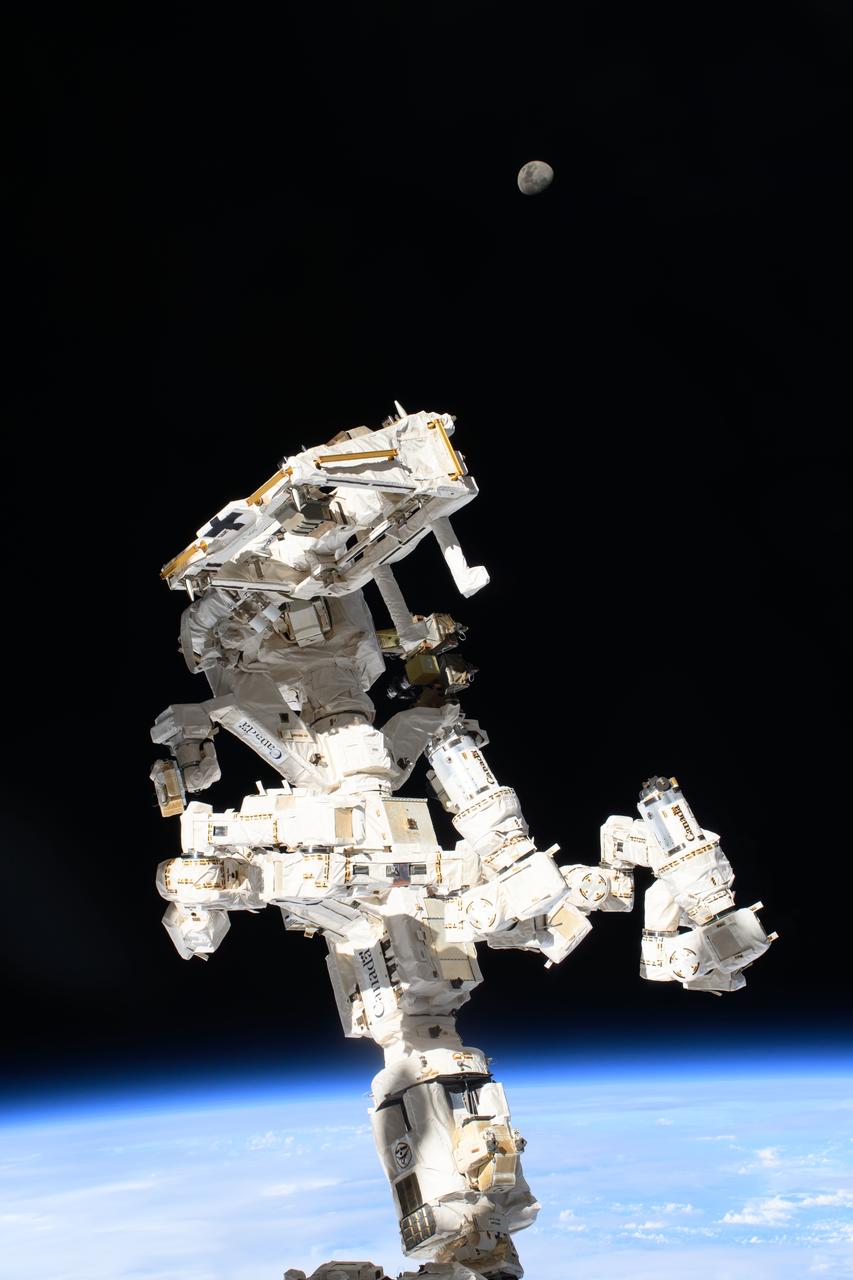
iss071e092171 (May 19, 2024) --- The International Space Station's Dextre, the fine-tuned robotic hand, attached to the Canadarm2 robotic arm dominates the frame with the waxing gibbous Moon (at top) in the background and the Indian Ocean 259 miles below.

iss068e035568 (Dec. 29, 2022) --- The SpaceX Dragon cargo craft is pictured docked to the International Space Station's space-facing port on the Harmony module. In the foreground, is the Dextre fine-tuned robotic hand attached to the Canadarm2 robotic arm.

iss062e115307 (March 24, 2020) --- The SpaceX Dragon resupply ship is pictured attached to the International Space Station's Harmony module with the Canadarm2 robotic arm at right.
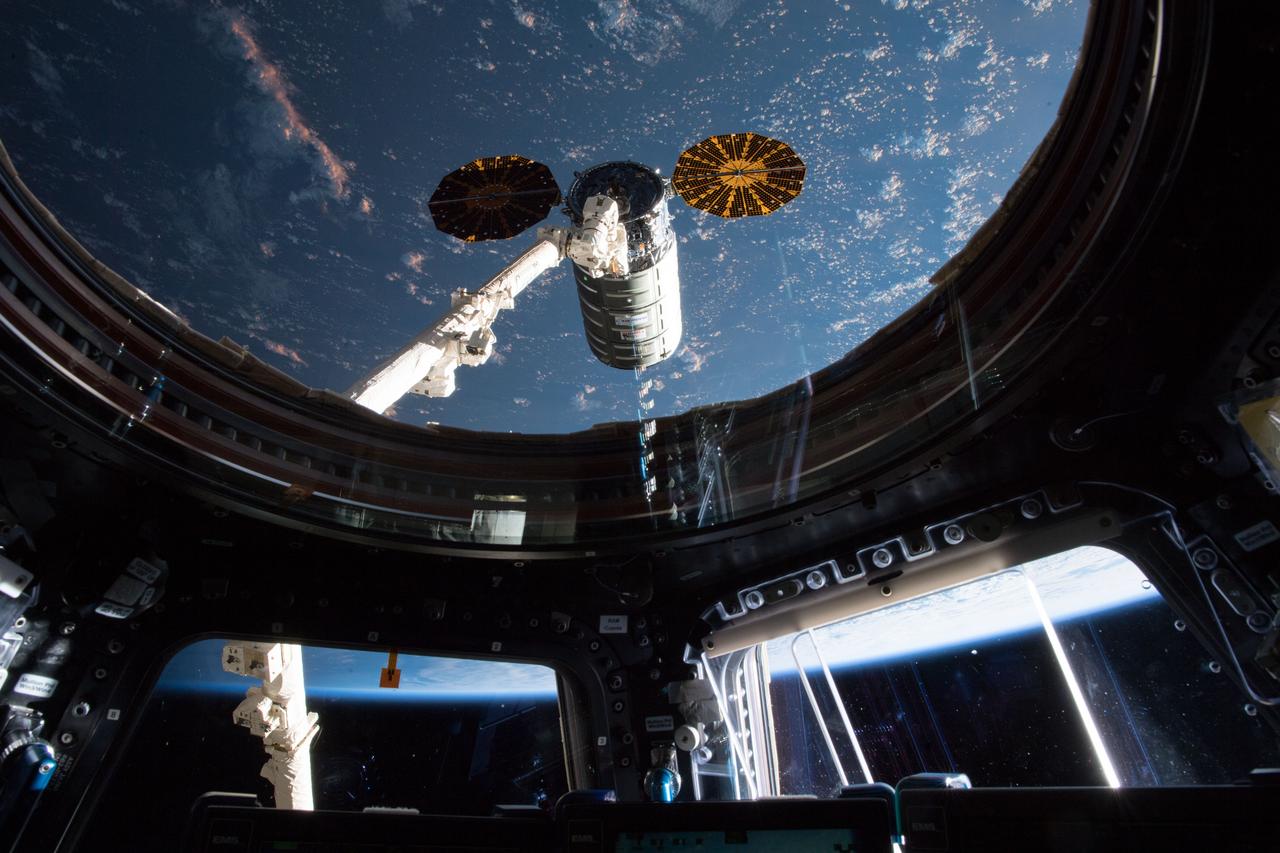
iss055e074781 (May 24, 2018) --- This view taken from inside the Cupola shows the Orbital ATK space freighter moments before it was grappled with the Canadarm2 robotic arm.
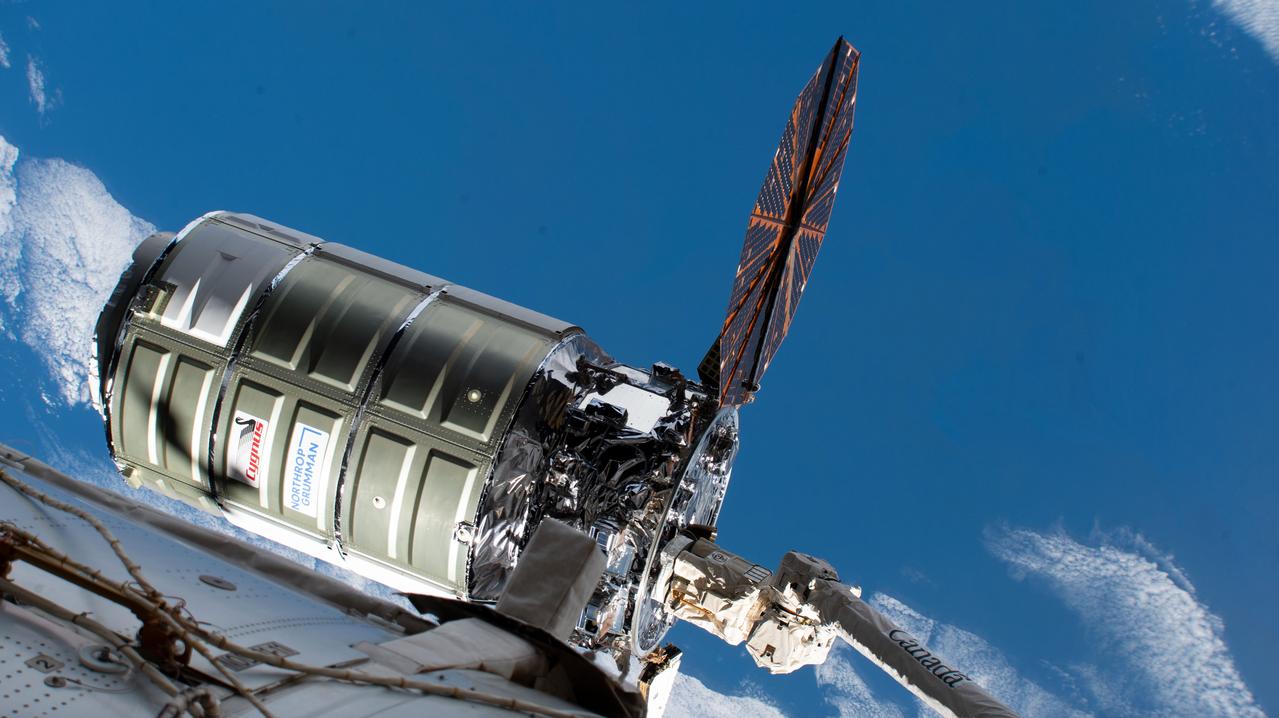
iss068e021345 (Nov. 9, 2022) --- The Northrop Grumman Cygnus space freighter is pictured in the grip of the Canadarm2 robotic arm shortly after arriving at the International Space Station.
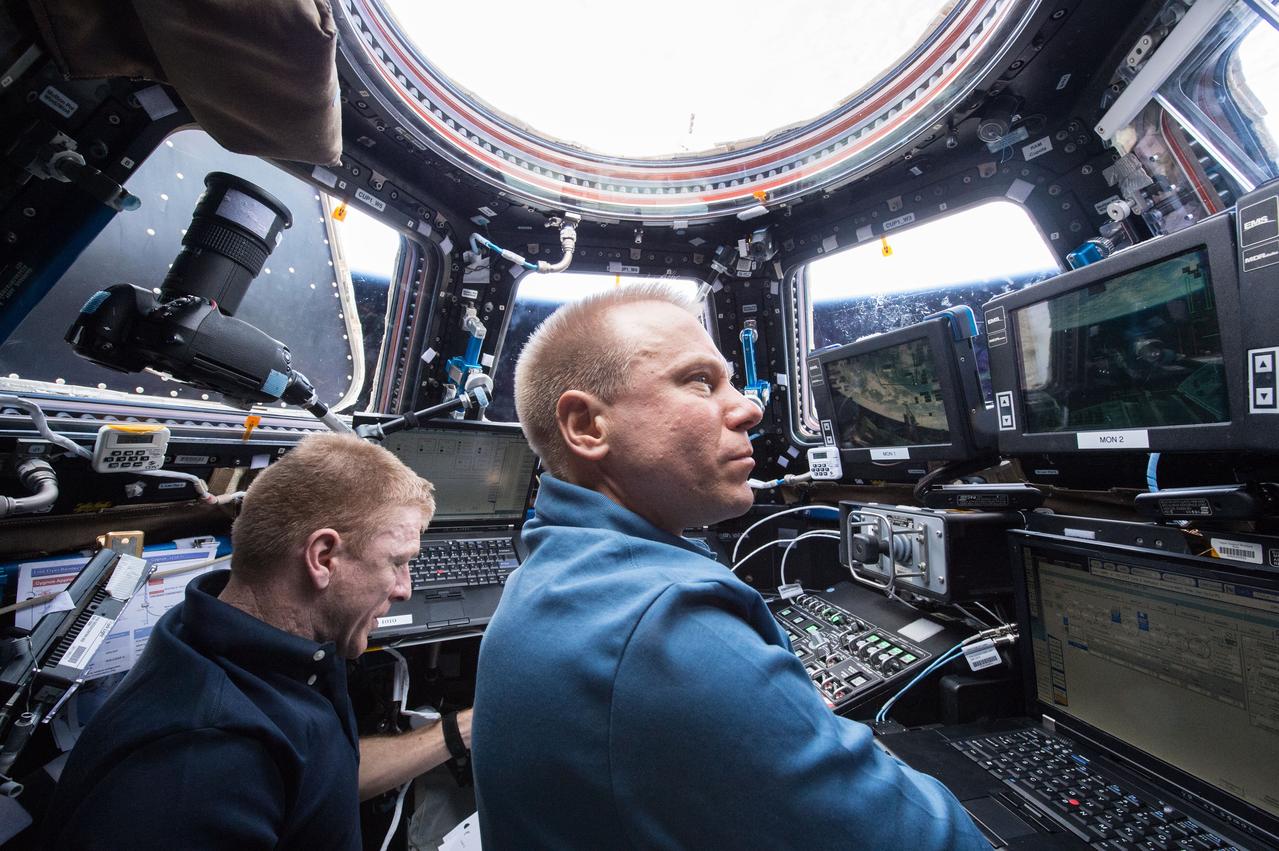
ISS047e021582 (03/26/2016) --- Cygnus capture on 26 March 2016. Expedition 47 robotic arm operator NASA astronaut Tim Kopra of NASA commanded the International Space Station’s Canadarm2 robotic arm to capture and dock the Cygnus spacecraft. He was assisted by ESA (European Space Agency) astronaut Tim Peake.

iss060e022993 (Aug. 6, 2019) --- The Cygnus resupply spacecraft from Northrop Grumman is shown grappled by the Canadarm2 robotic arm following its detachment from the Unity module and just before release. Behind the robotic arm, the SpaceX Dragon is seen still attached to the Unity module of the International Space Station.
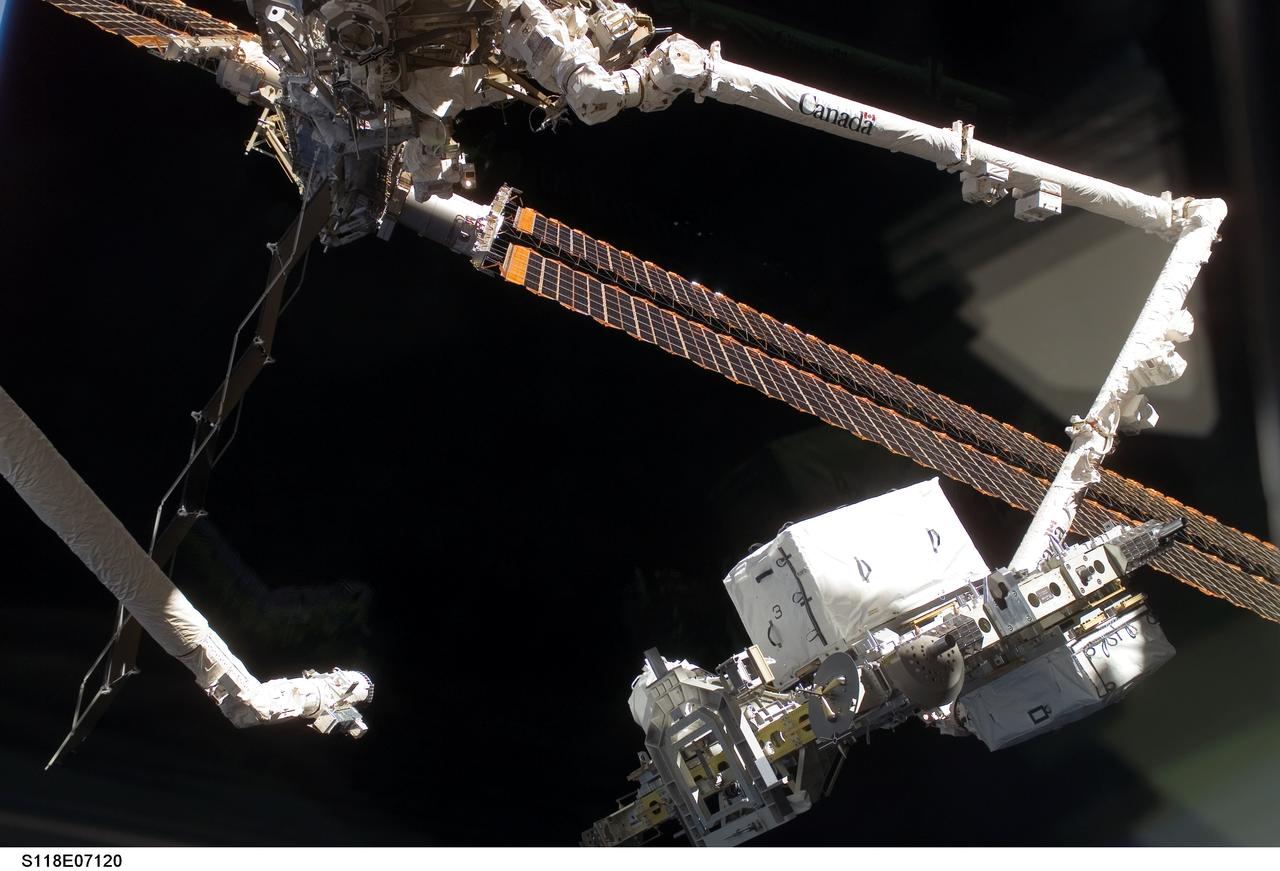
S118-E-07120 (14 Aug. 2007) --- The Space Shuttle Endeavour's Remote Manipulator System (RMS) robotic arm (left) moves away following the hand-off of an external stowage platform (ESP-3) to the station's robotic arm while docked with the International Space Station. Astronauts Tracy Caldwell and Barbara R. Morgan, both STS-118 mission specialists, were at inside at Endeavour's controls as the shuttle's robotic arm lifted the storage platform from the cargo bay to hand it over to the station's robotic arm, also known as Canadarm2. Astronauts Charlie Hobaugh, pilot, and Clay Anderson, Expedition 15 flight engineer, then used the Canadarm2 to attach the 13-by-7-foot platform to the station's Port 3 truss.
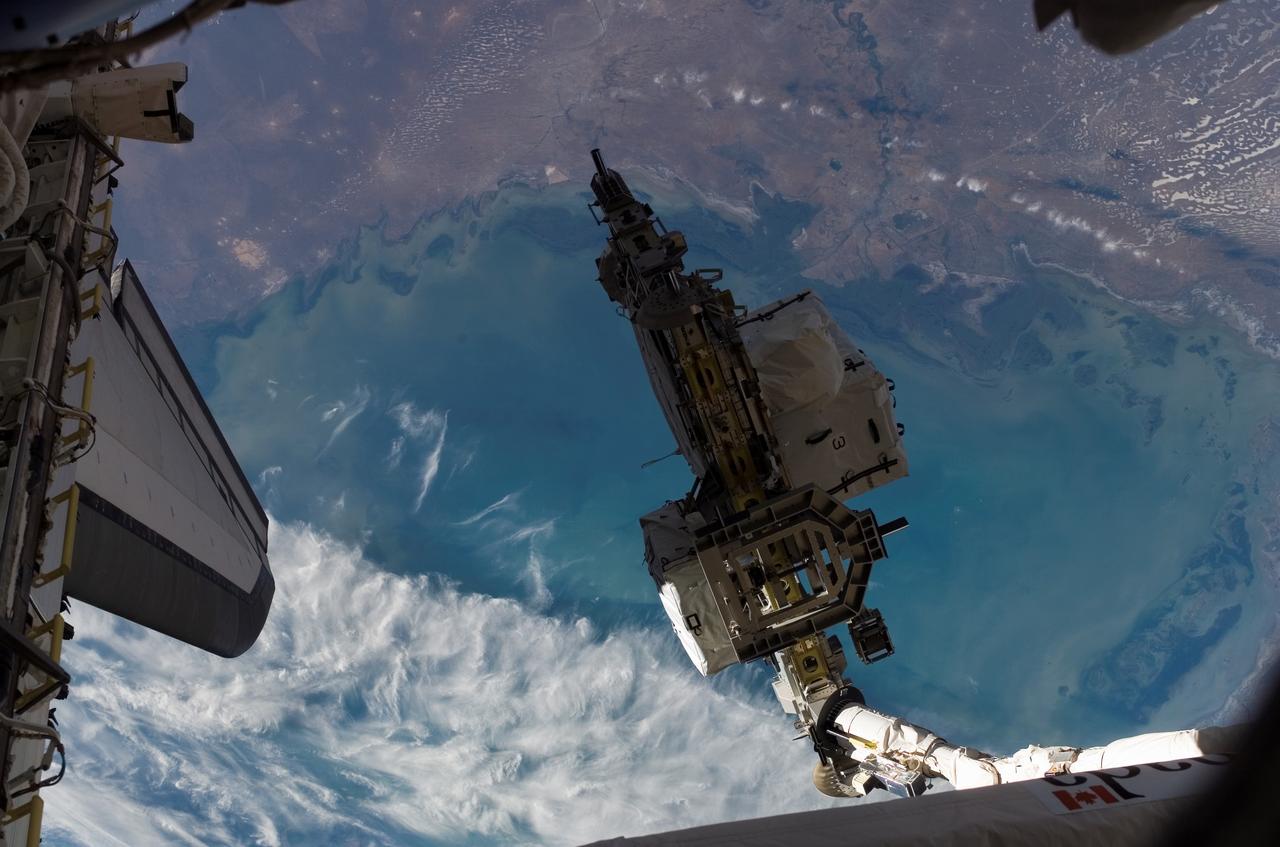
S118-E-07111 (14 Aug. 2007) --- Backdropped by a colorful Earth, the Space Shuttle Endeavour's Remote Manipulator System (RMS) robotic arm moves an external stowage platform (ESP-3) for a hand-off to the station's robotic arm (out of frame) while docked with the International Space Station. Astronauts Tracy Caldwell and Barbara R. Morgan, both STS-118 mission specialists, were inside at Endeavour's controls as the shuttle's robotic arm lifted the storage platform from the cargo bay to hand it over to the station's robotic arm, also known as Canadarm2. Astronauts Charlie Hobaugh, pilot, and Clay Anderson, Expedition 15 flight engineer, then used Canadarm2 to attach the 13-by-7-foot platform to the station's Port 3 truss.
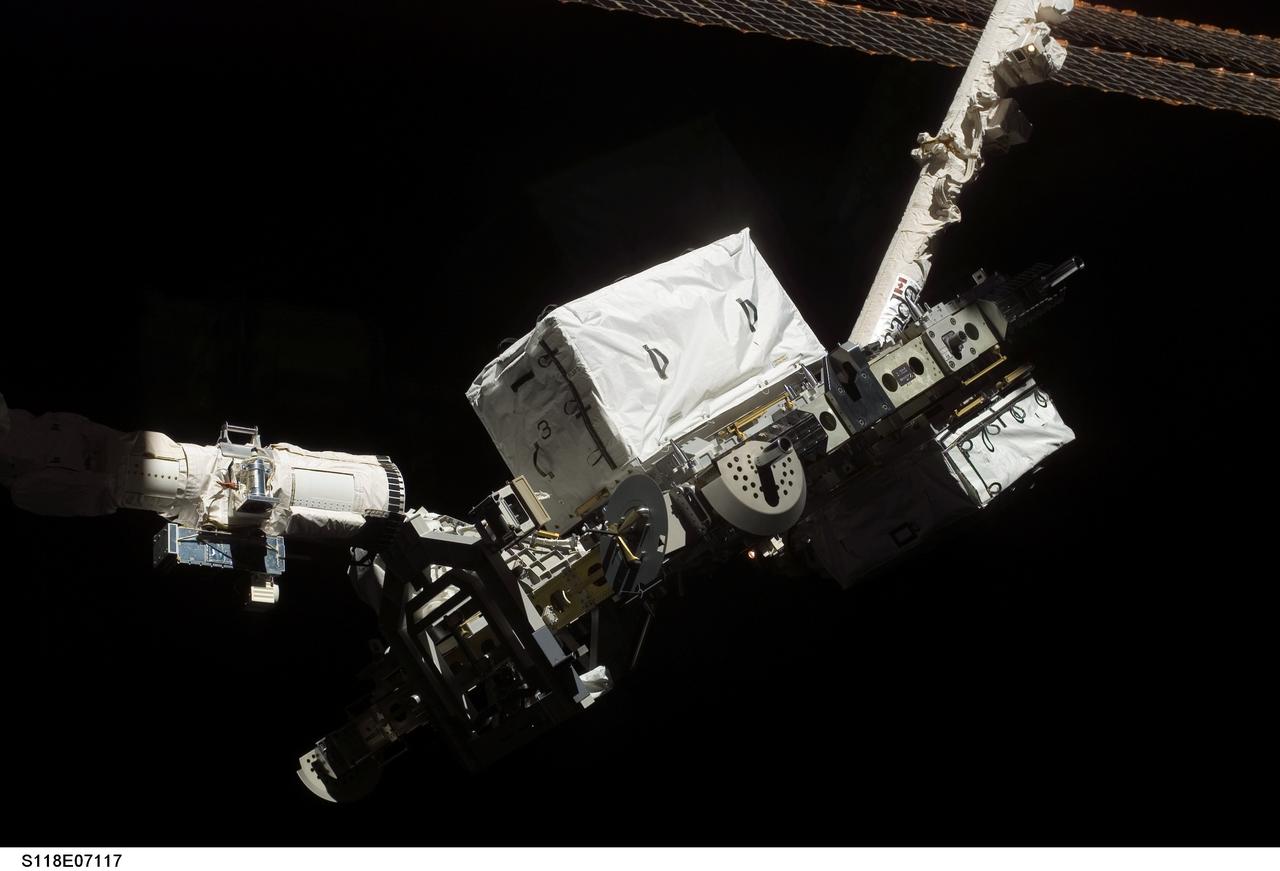
S118-E-07117 (14 Aug. 2007) --- The Space Shuttle Endeavour's Remote Manipulator System (RMS) robotic arm (left) moves away following the hand-off of an external stowage platform (ESP-3) to the station's robotic arm while docked with the International Space Station. Astronauts Tracy Caldwell and Barbara R. Morgan, both STS-118 mission specialists, were inside at Endeavour's controls as the shuttle's robotic arm lifted the storage platform from the cargo bay to hand it over to the station's robotic arm, also known as Canadarm2. Astronauts Charlie Hobaugh, pilot, and Clay Anderson, Expedition 15 flight engineer, then used the Canadarm2 to attach the 13-by-7-foot platform to the station's Port 3 truss.
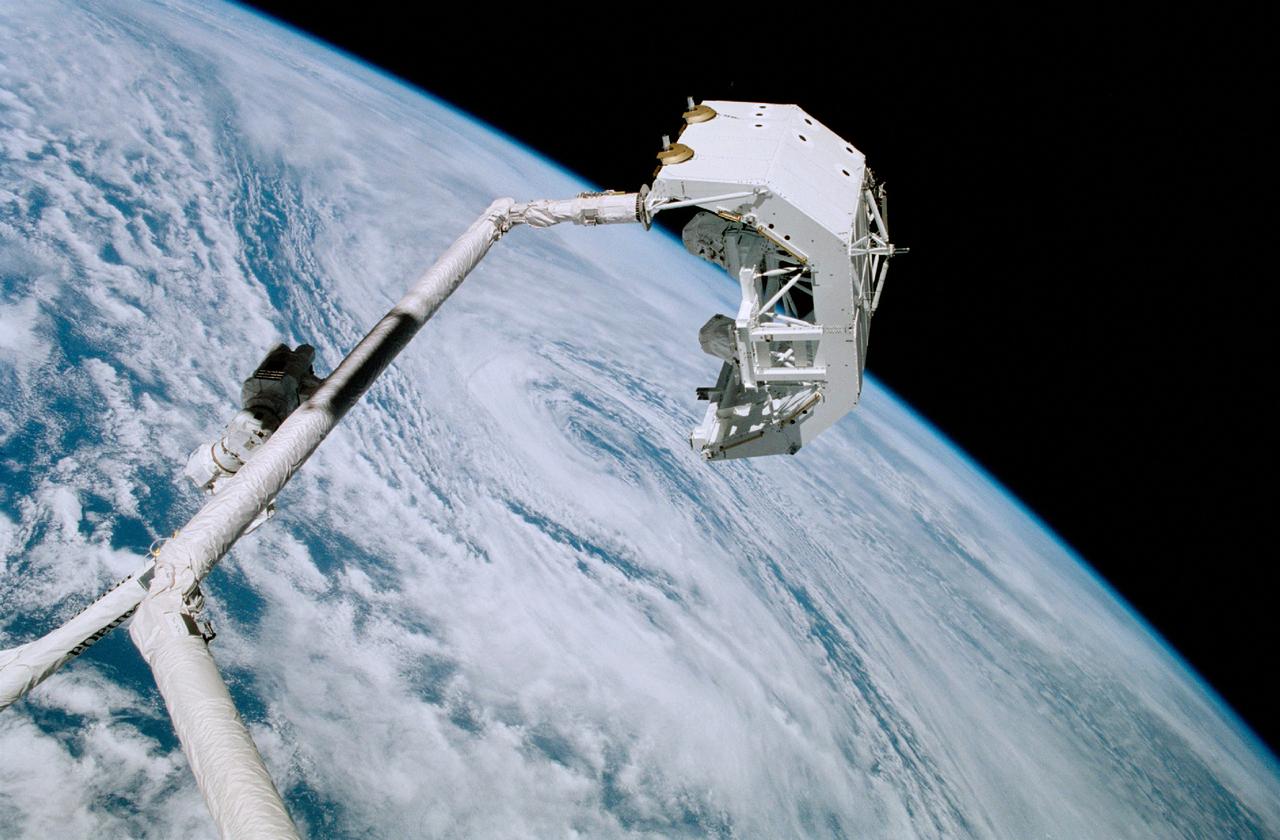
A Canadian "handshake" in space occurred on April 28, 2001, as the Canadian-built space station robotic arm (Canadarm-2) transferred its launch cradle over to Endeavor's robotic arm. Marning the controls from the shuttle's aft flight deck, Canadian Mission Specialist Chris A. Hadfield of the Canadian Space Agency (CSA) was instrumental in the activity. The Spacelab pallet that carried the Canadarm2 robotic arm to the station was developed at the Marshall Space Flight Center (MSFC) in Huntsville, Alabama.